Every physics of a robot, in one workbench.
Its board's fields and its mechanics, computed from plain files.
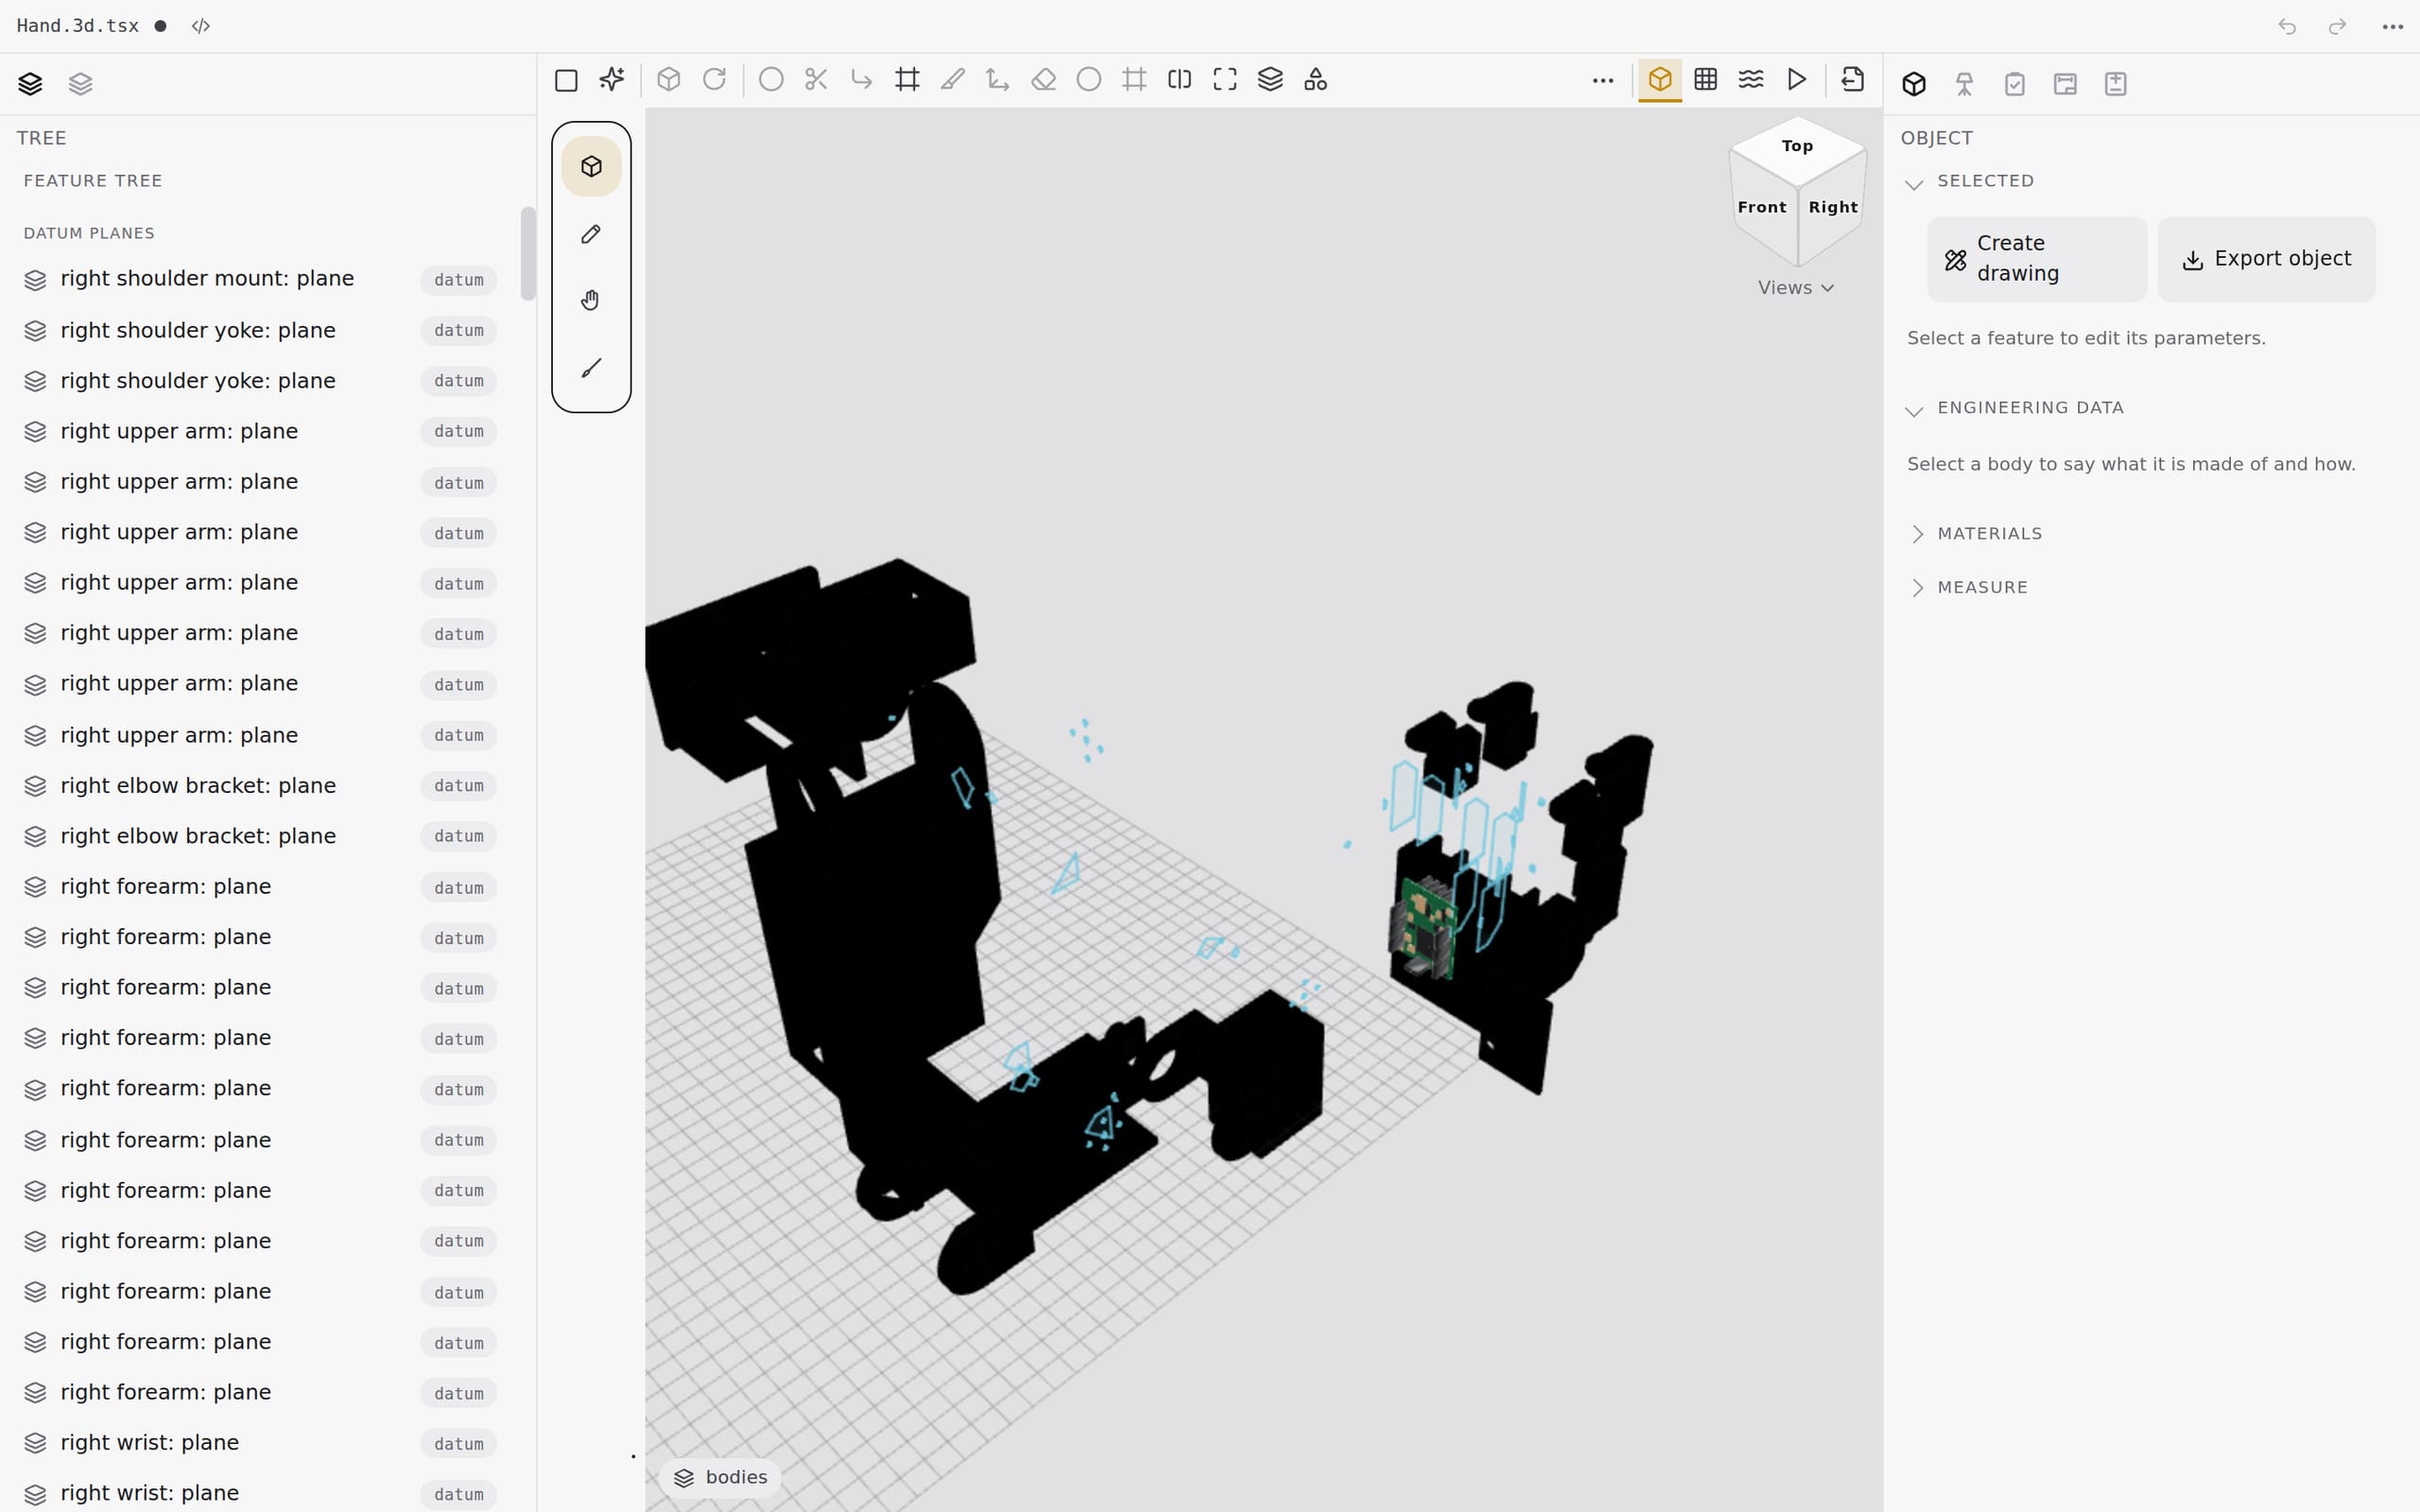

Describe the part. Get the design.
An agent writes the assembly and the board as code, checks the fields and the fit, and opens them for you to turn.
From a part to a factory.
One turn of the loop, from a sentence to a tested part, in days. Each rung up is a product we make, recorded the same way.
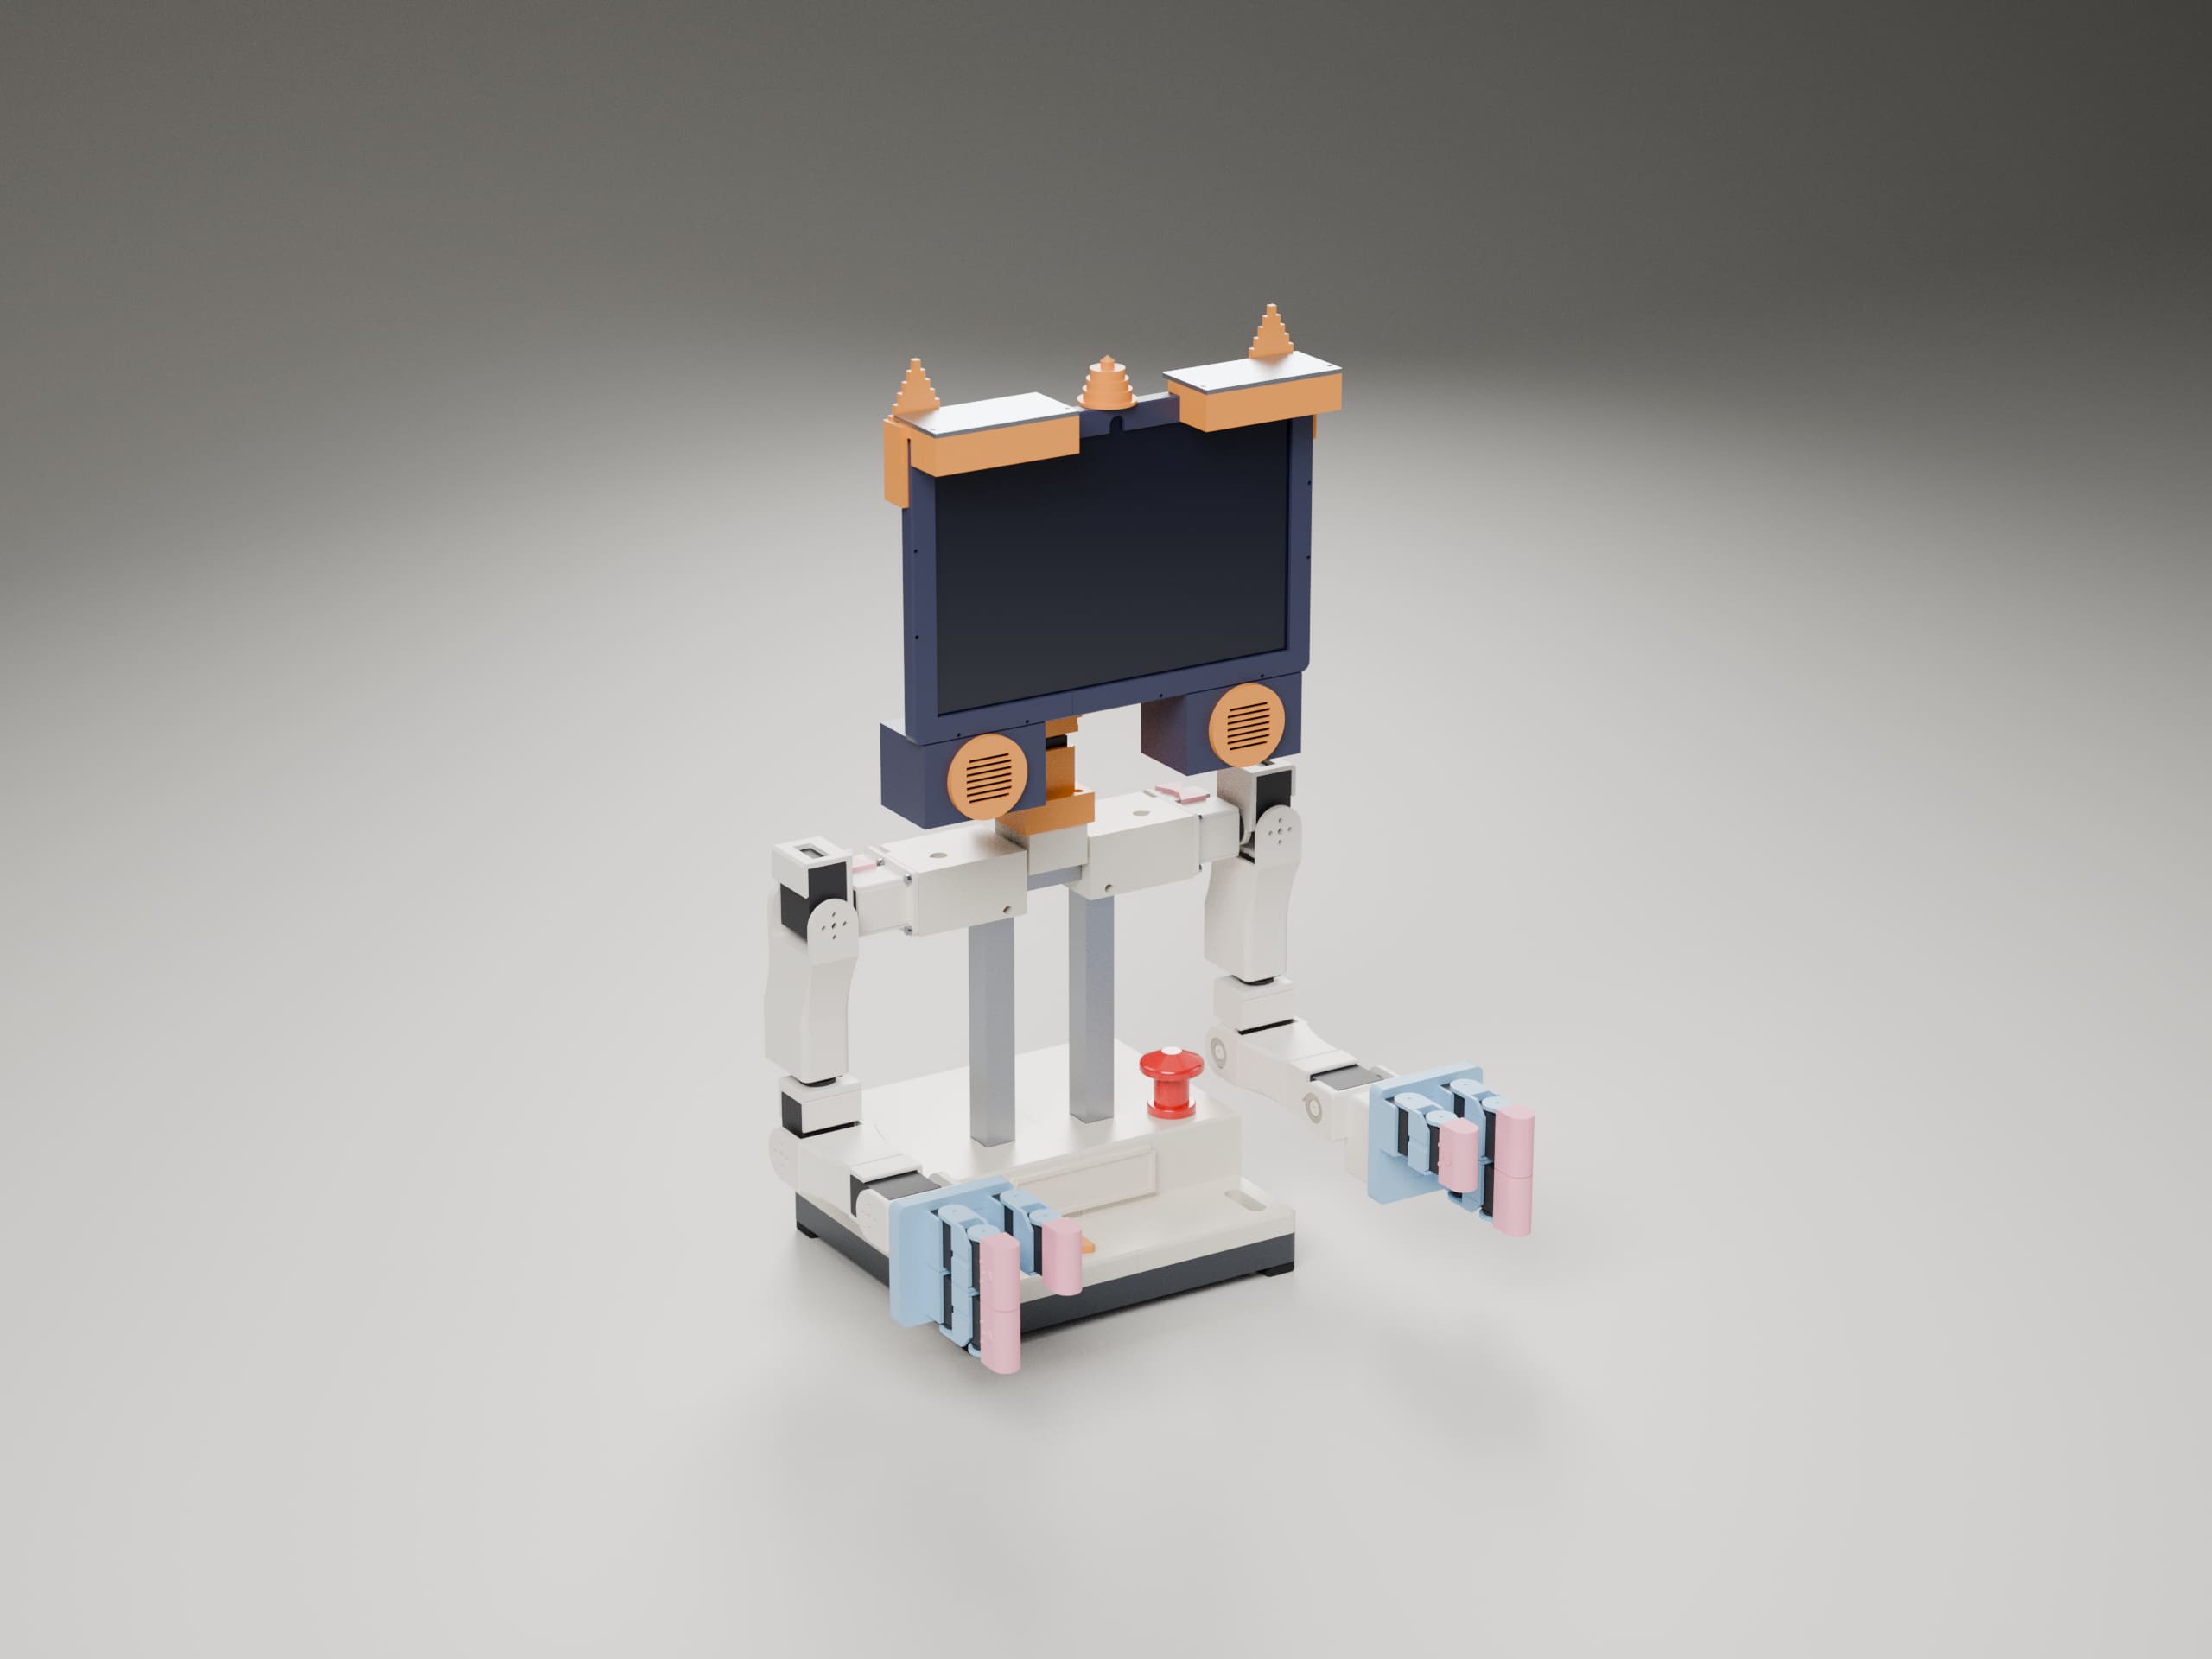
Assembly
The SO-101 arm, and DeskAssistant-001: two arms with hands, a neck and a tablet head on a desk base.
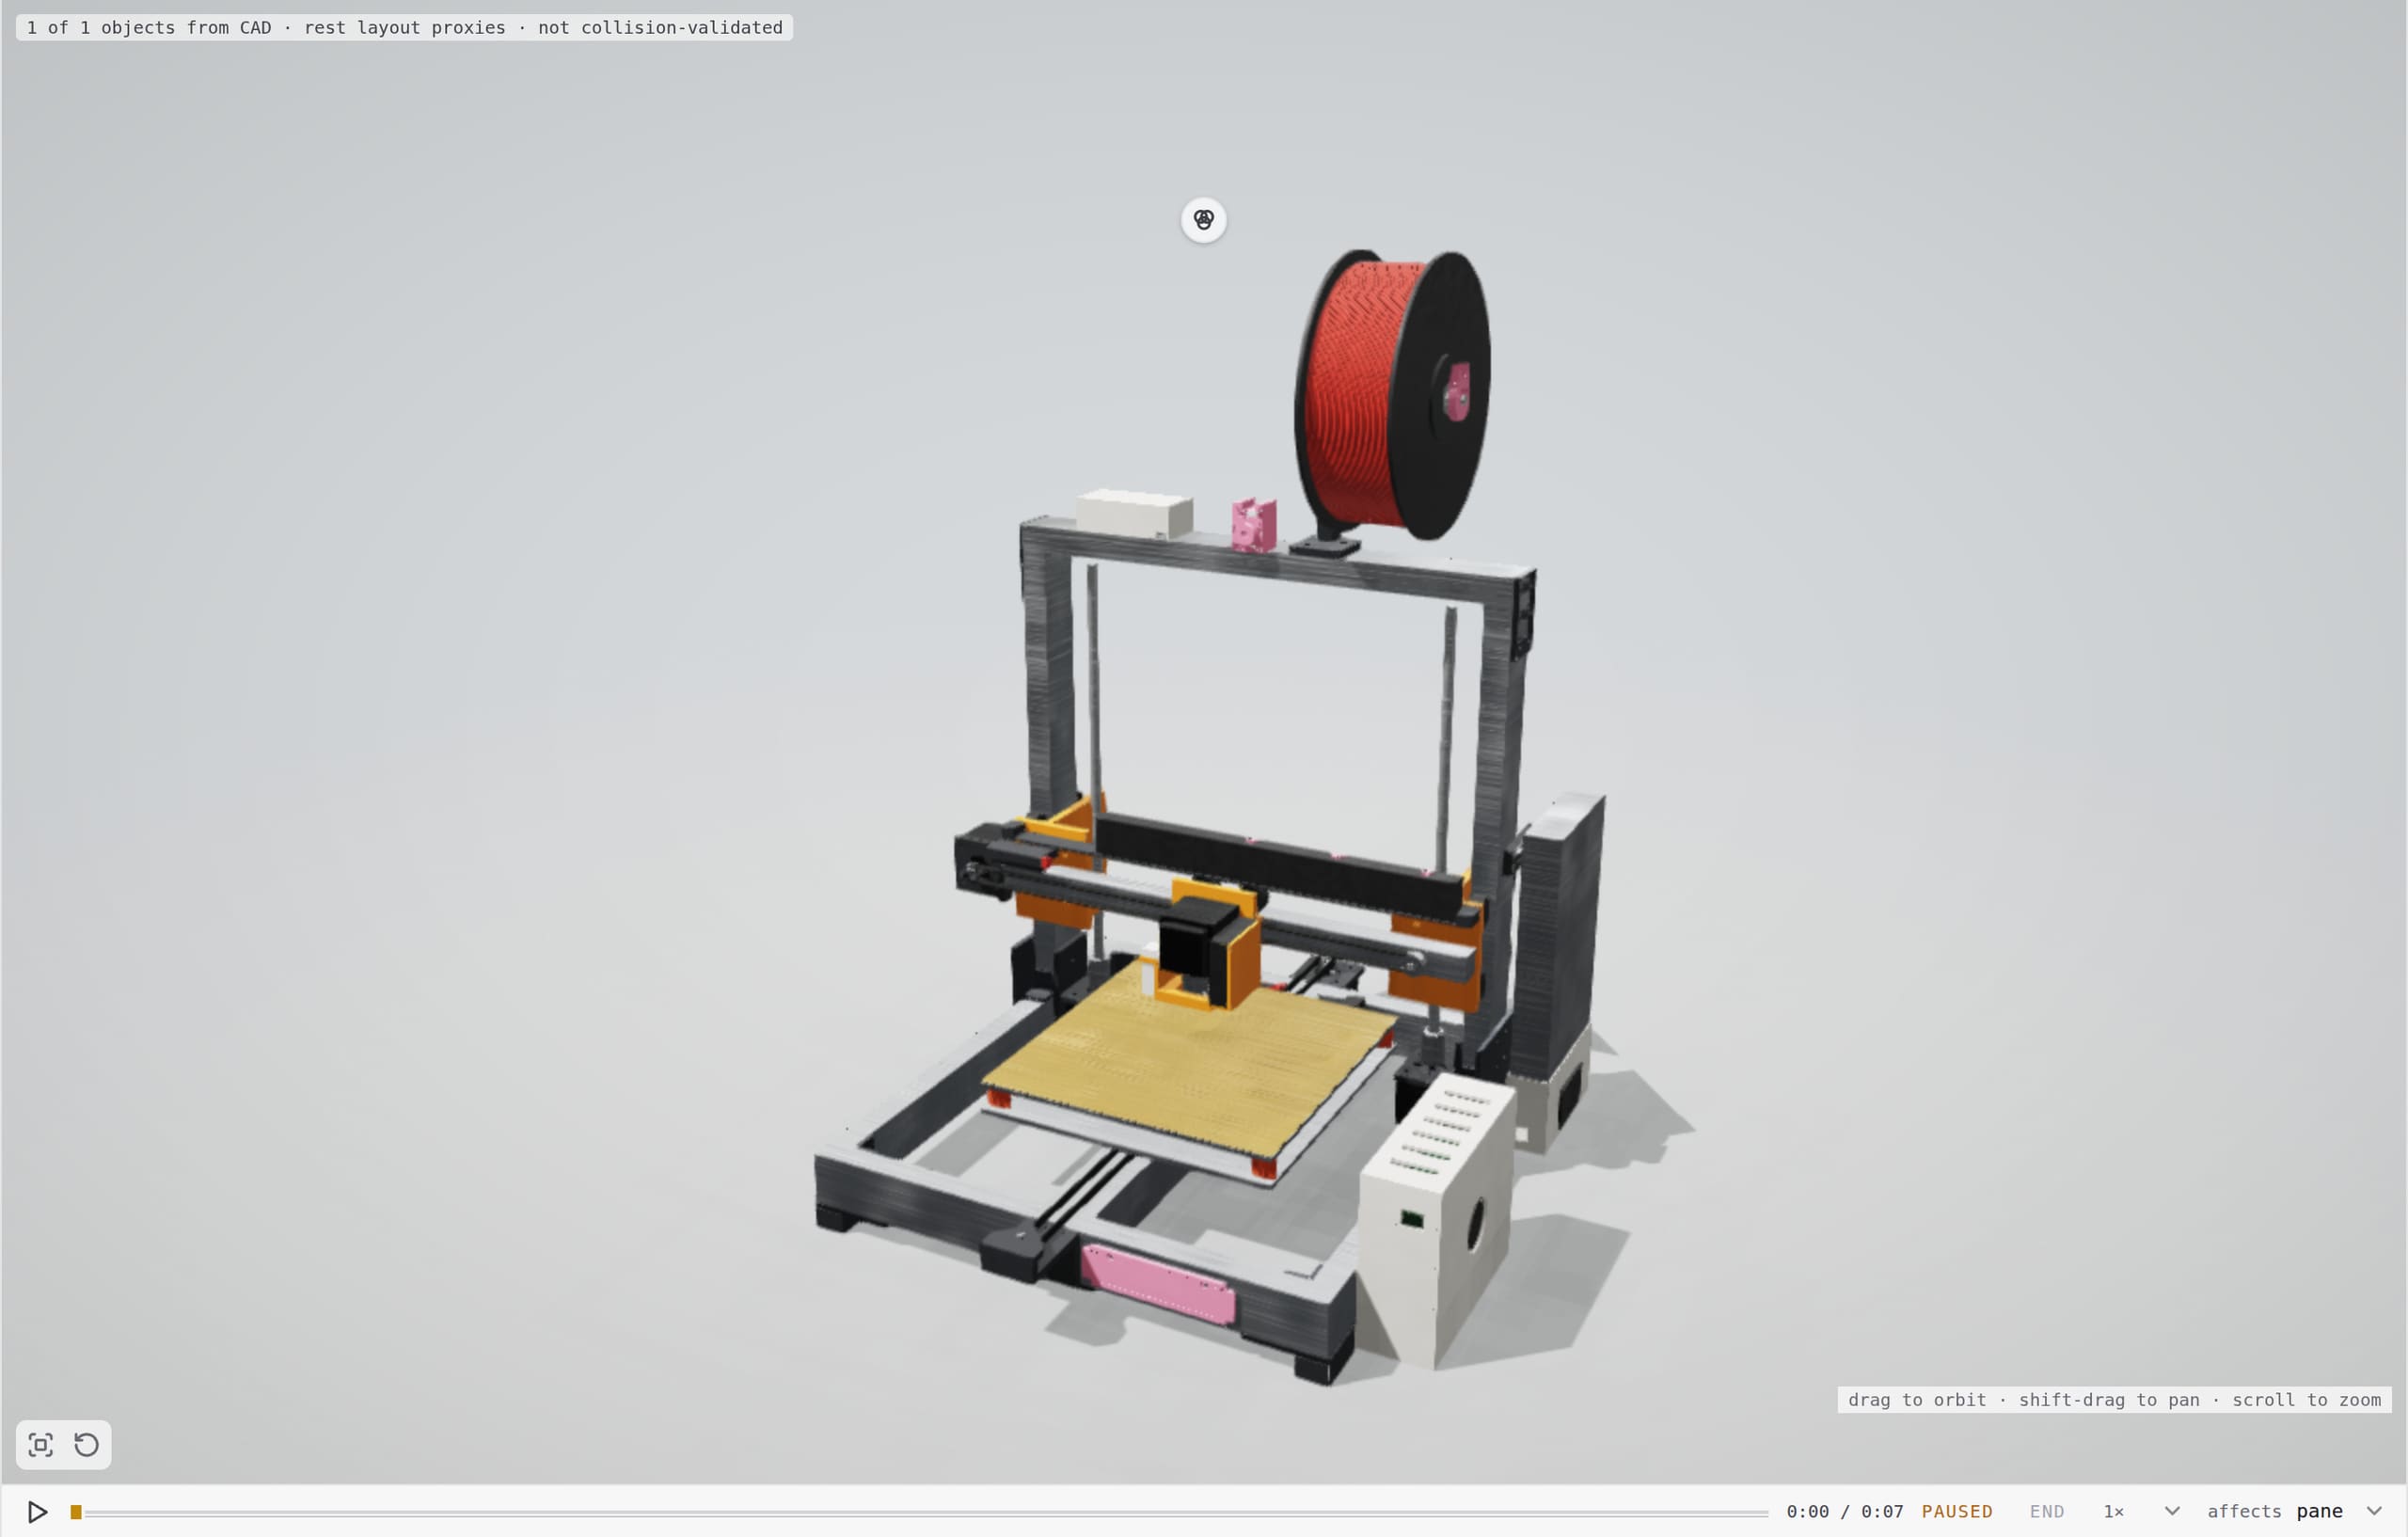

Machine
Printer-001: a 220 mm printer on Klipper, with LTE. Its prints are runs on the record.

Factory
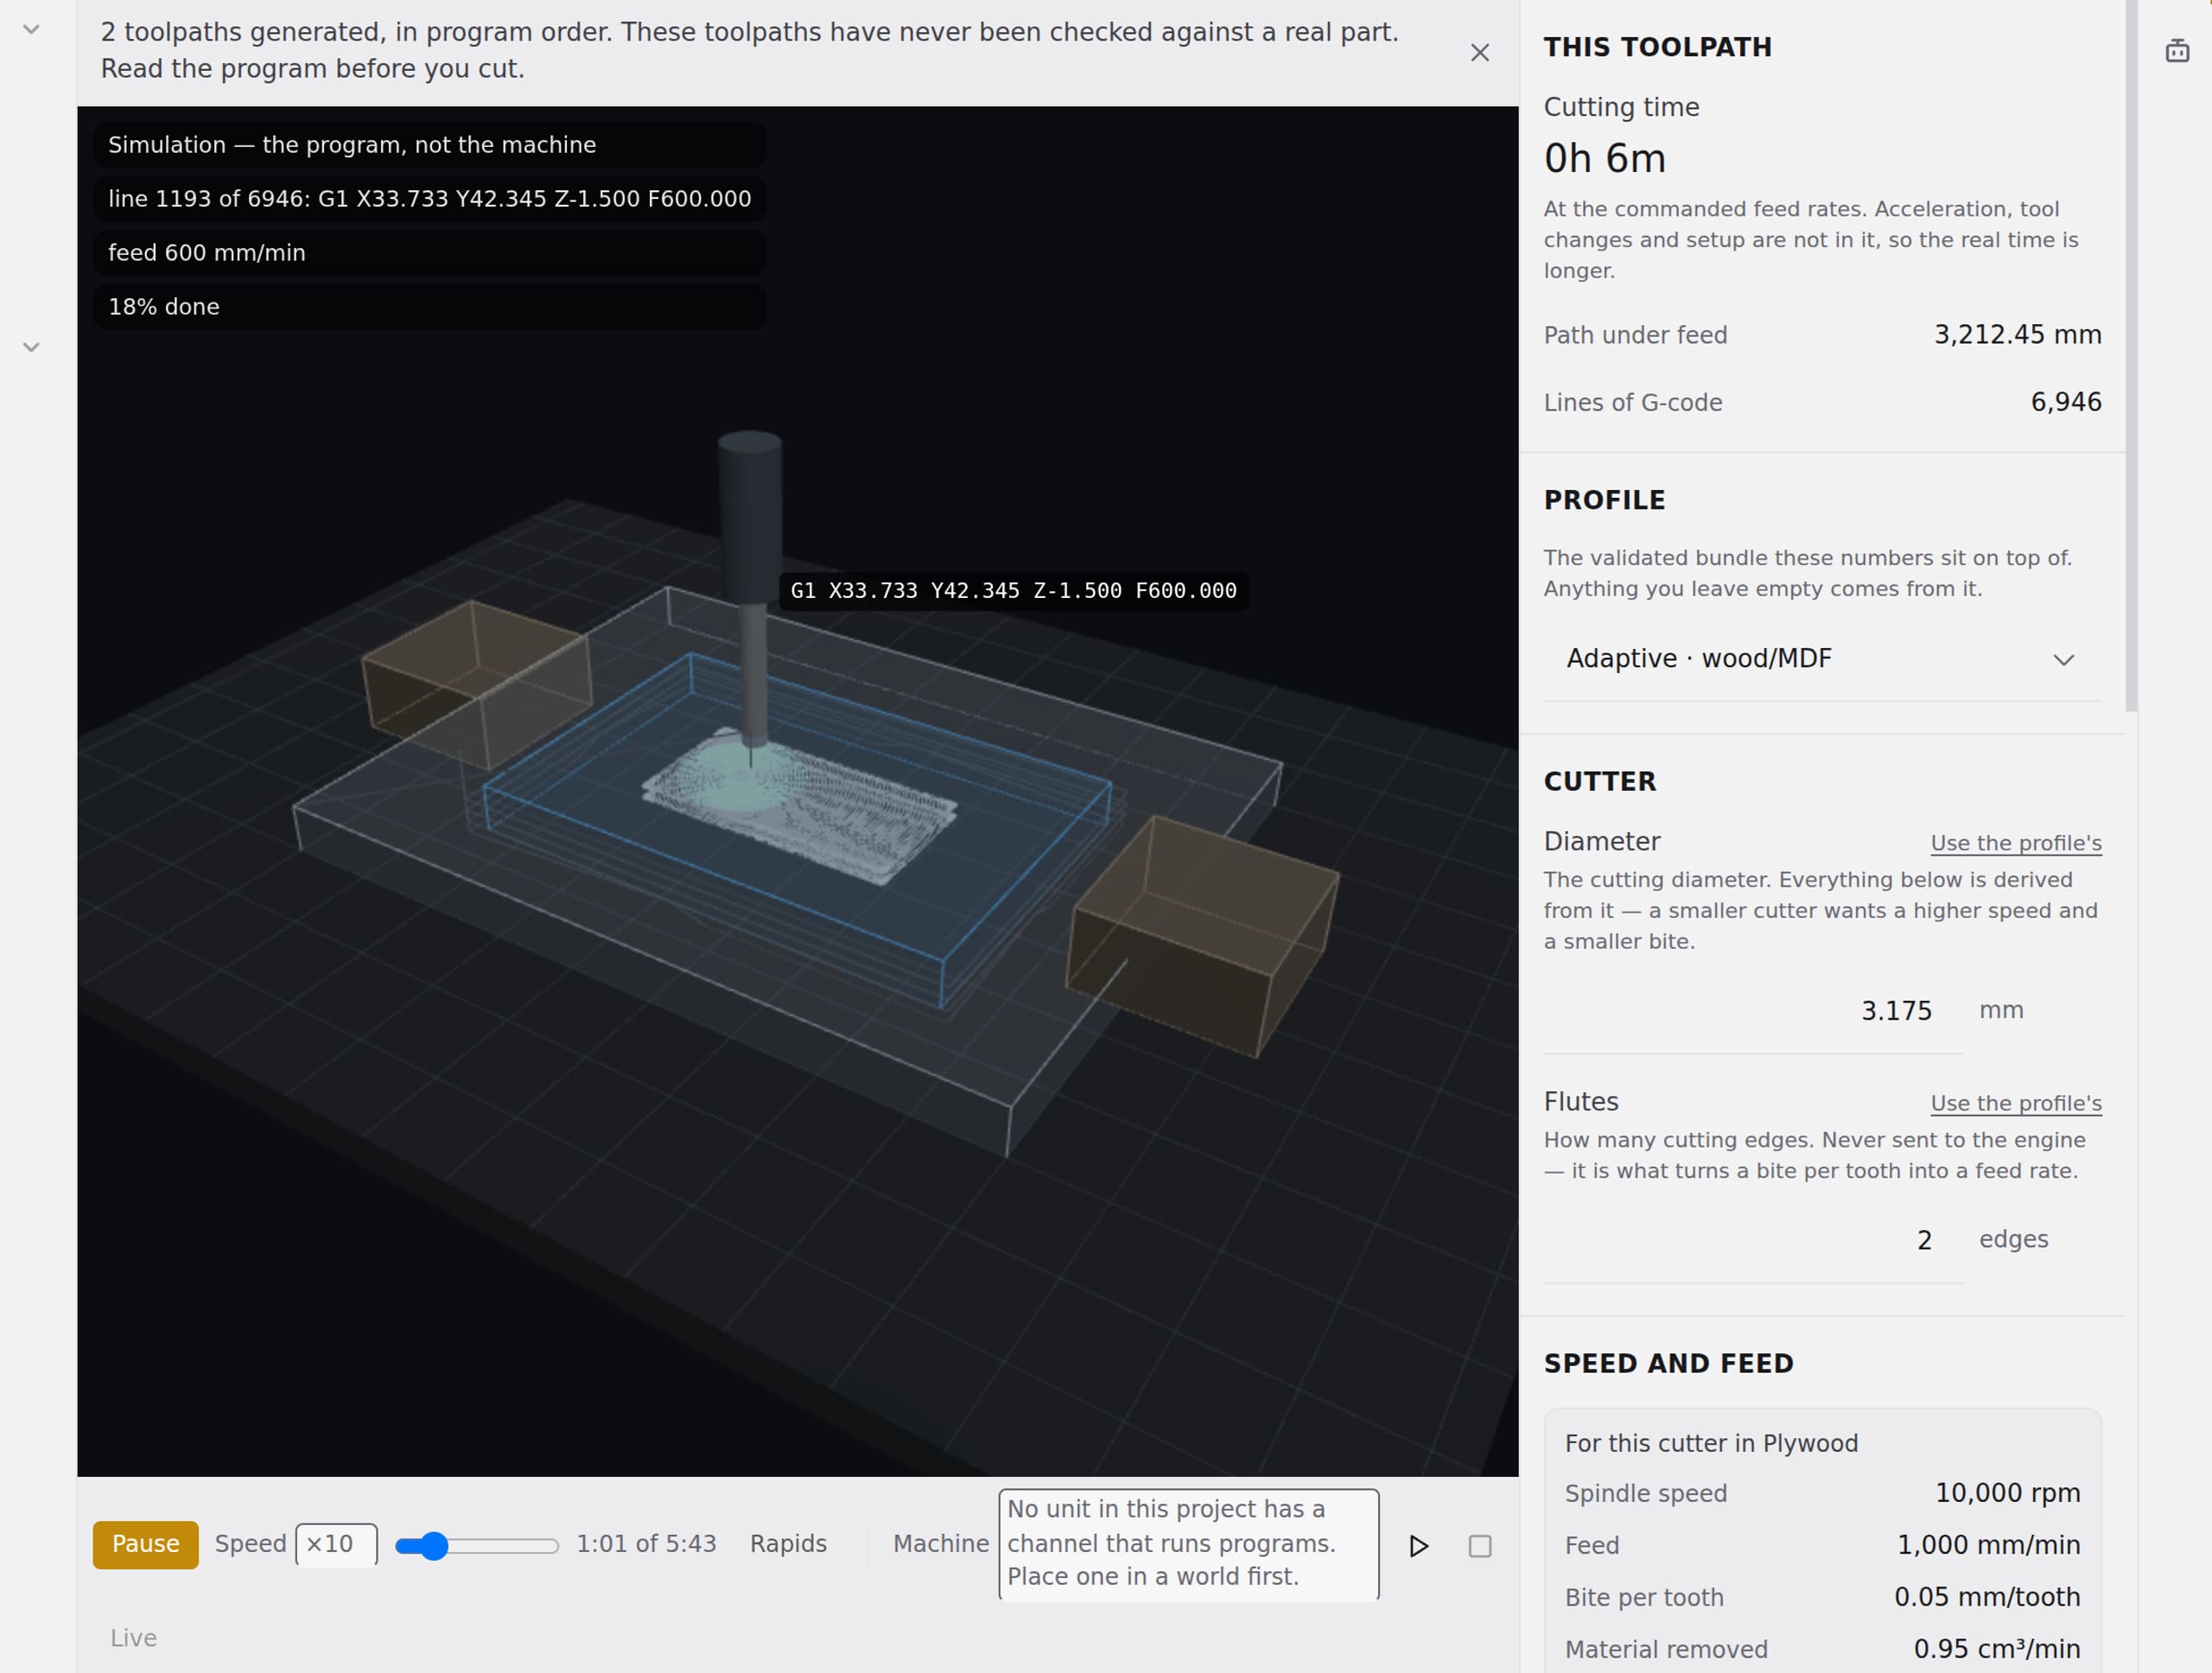
Router-001, a 4 × 8 ft CNC router, and 5-Axis-001, a bench 5-axis mill: the machines that make the next machines.
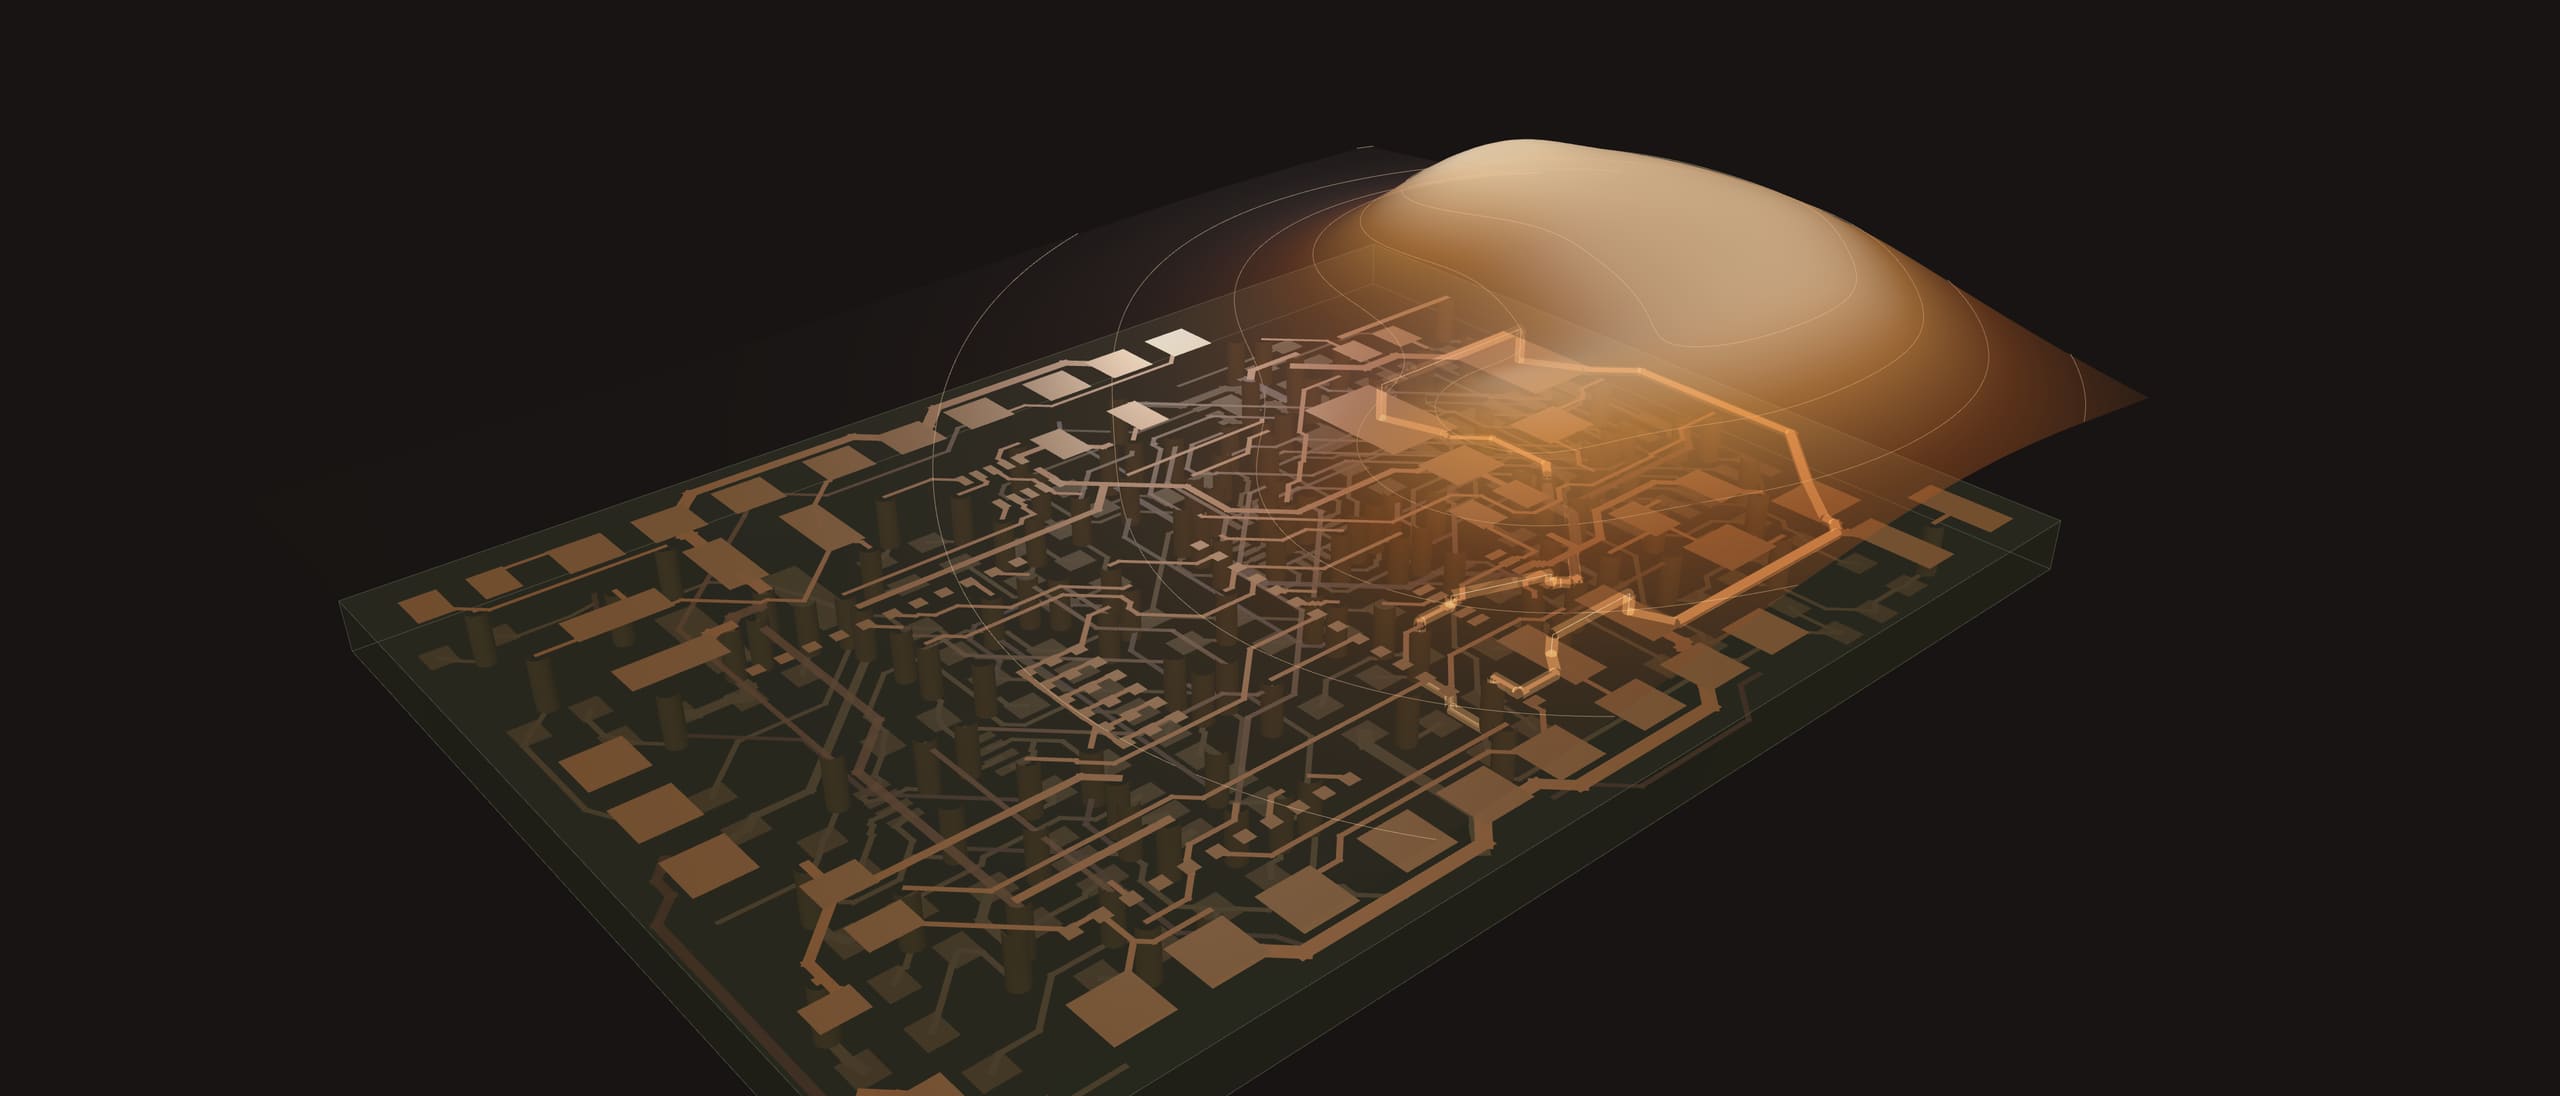
The board's traces, in their own field.
The hand board's real copper, solved for the field just above it and the coupling between two neighbouring traces.
Start with the example.
The board and the assembly are plain files in one folder, and they ship with the workbench. Check a whole robot the same way.