Every physics of a robot, in one workbench.

Its board's fields and its mechanics, computed from plain files.
Turn it yourselfScroll moves the page. Click in to use the wheel and keys.Esc gives the page back.

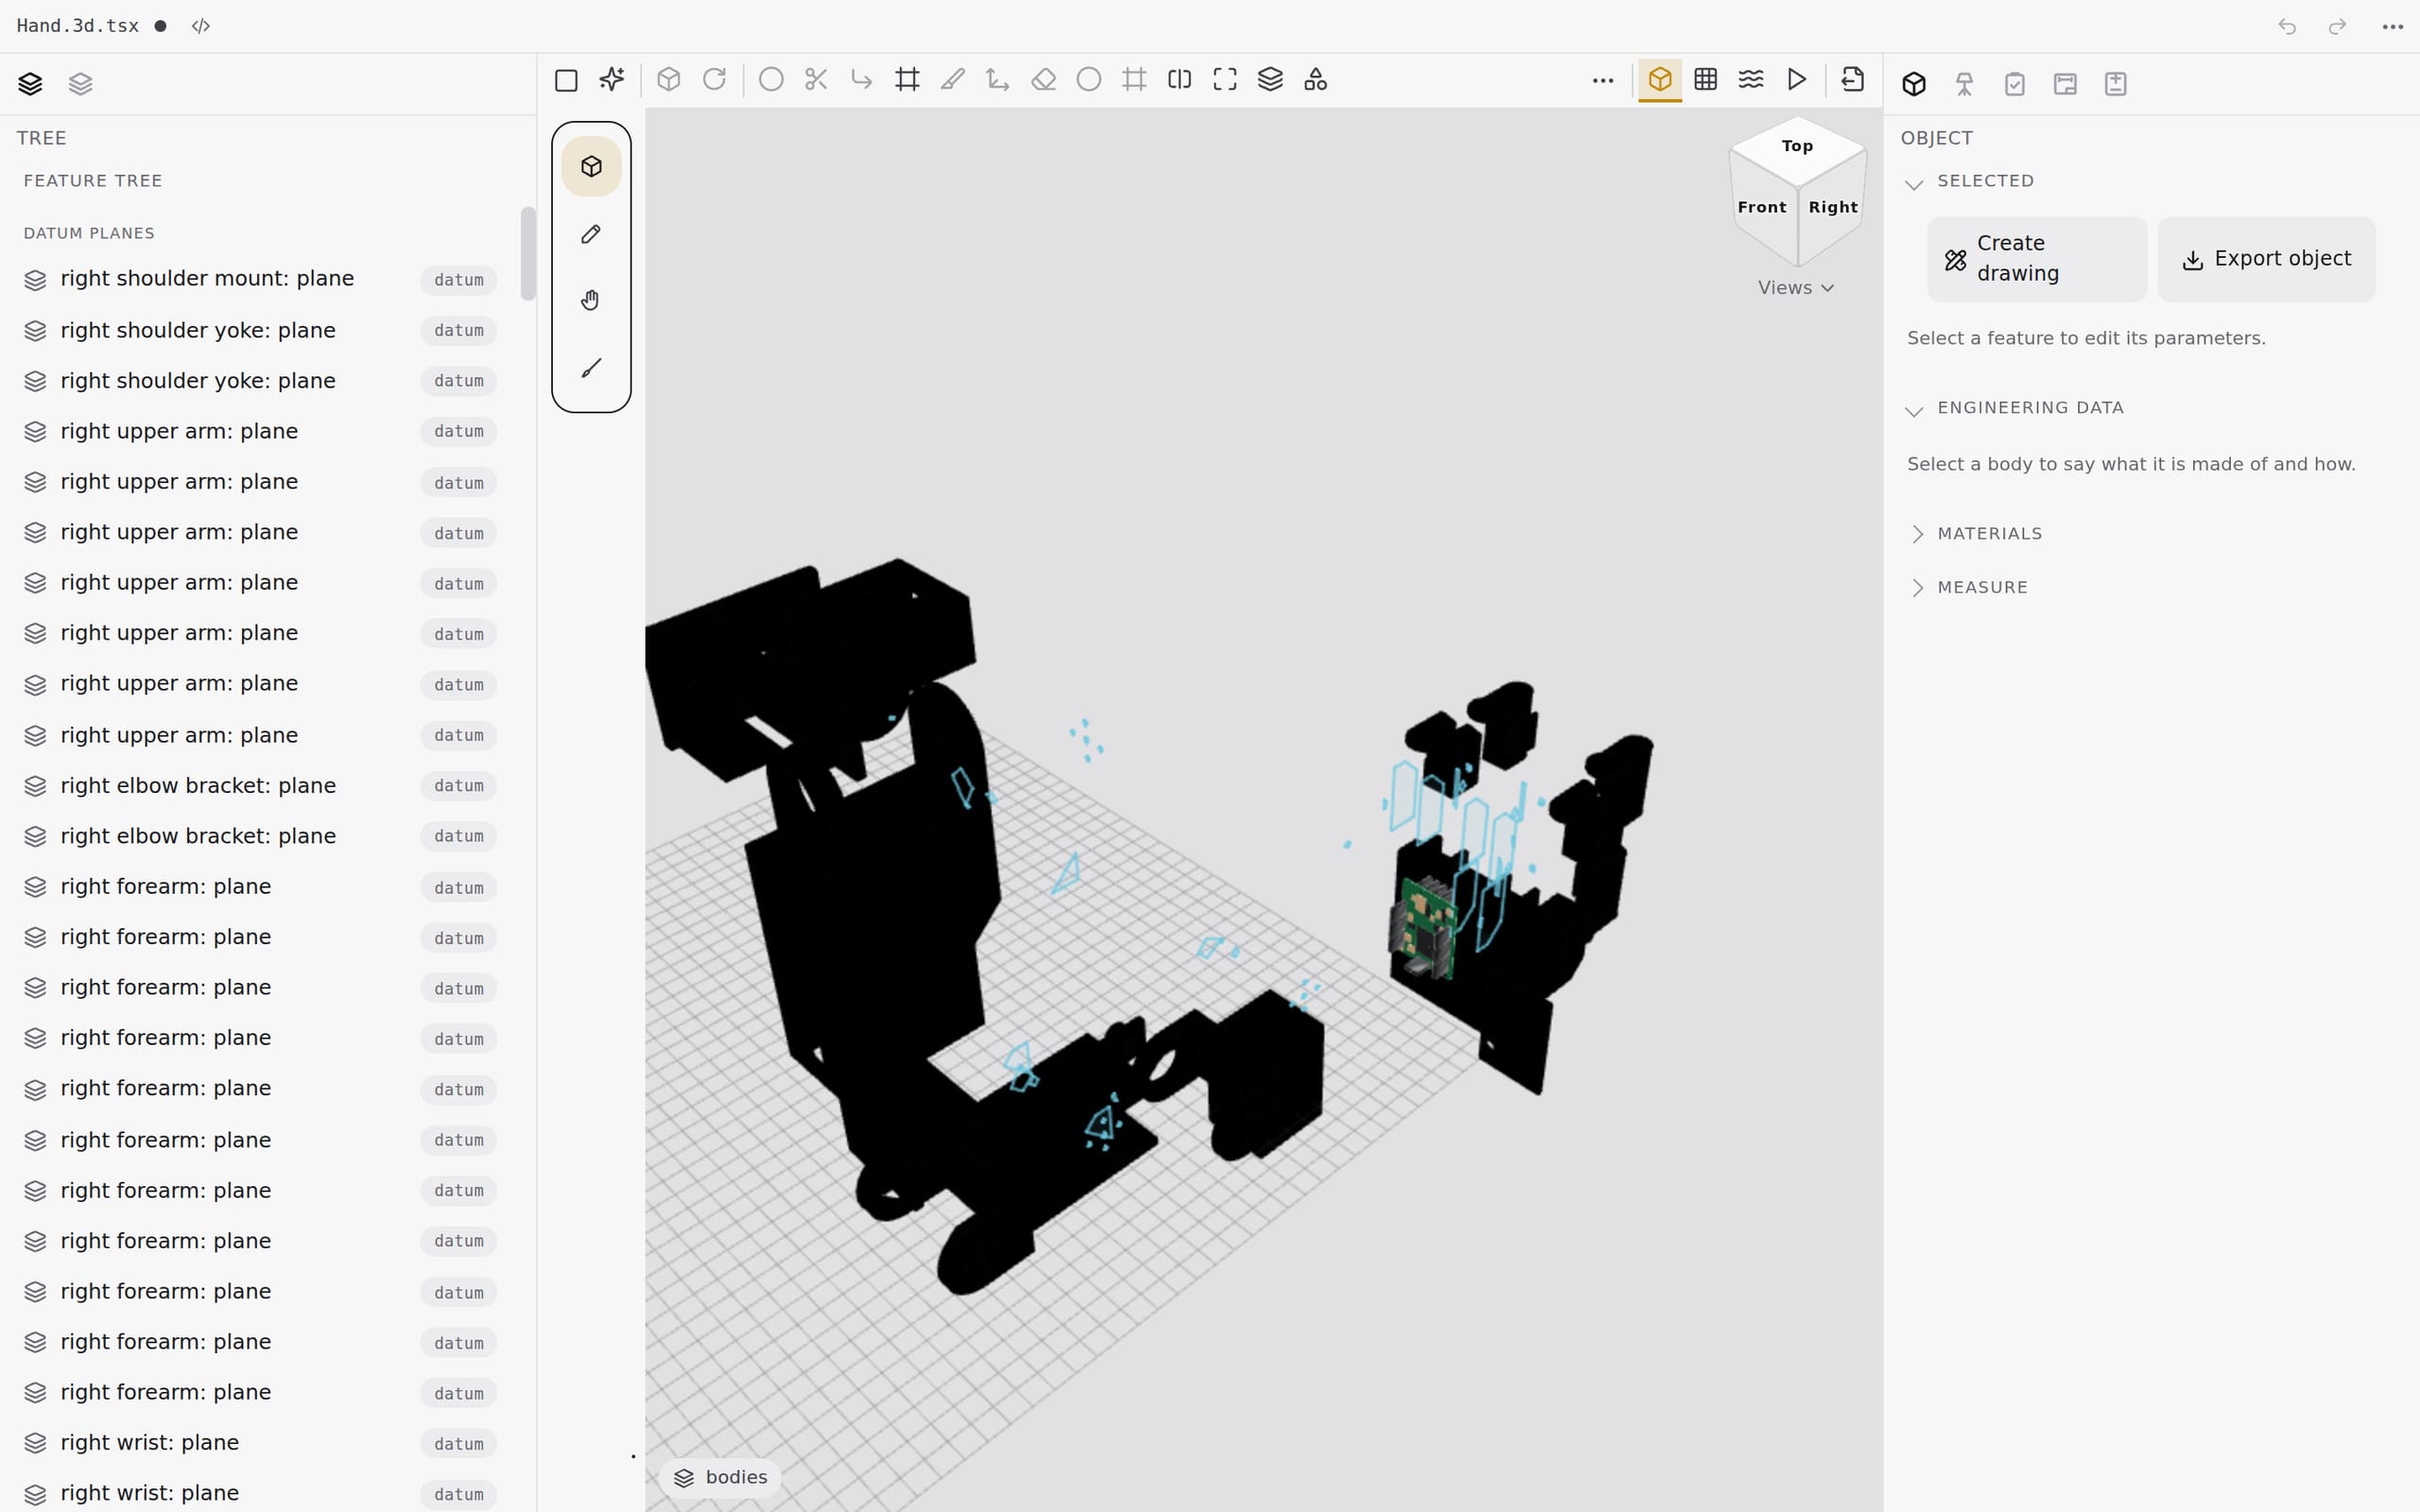
Hand.3d.tsx
UpperBody-001's arm in the 3D app with its hand board in the palm, pulled apart in the exploded view: the green board with its parts sits between the palm and its cover.UpperBody-001's arm in the 3D app with its hand board in the palm, pulled apart in the exploded view: the green board with its parts sits between the palm and its cover.
Loading the live view

Try it live

Live. The robot hand as an assembly: it names the board's file, so the board is in it.

Describe the part. Get the design.

An agent writes the assembly and the board as code, checks the fields and the fit, and opens them for you to turn.

From a part to a factory.

One turn of the loop, from a sentence to a tested part, in days. Each rung up is a product we make, recorded the same way.
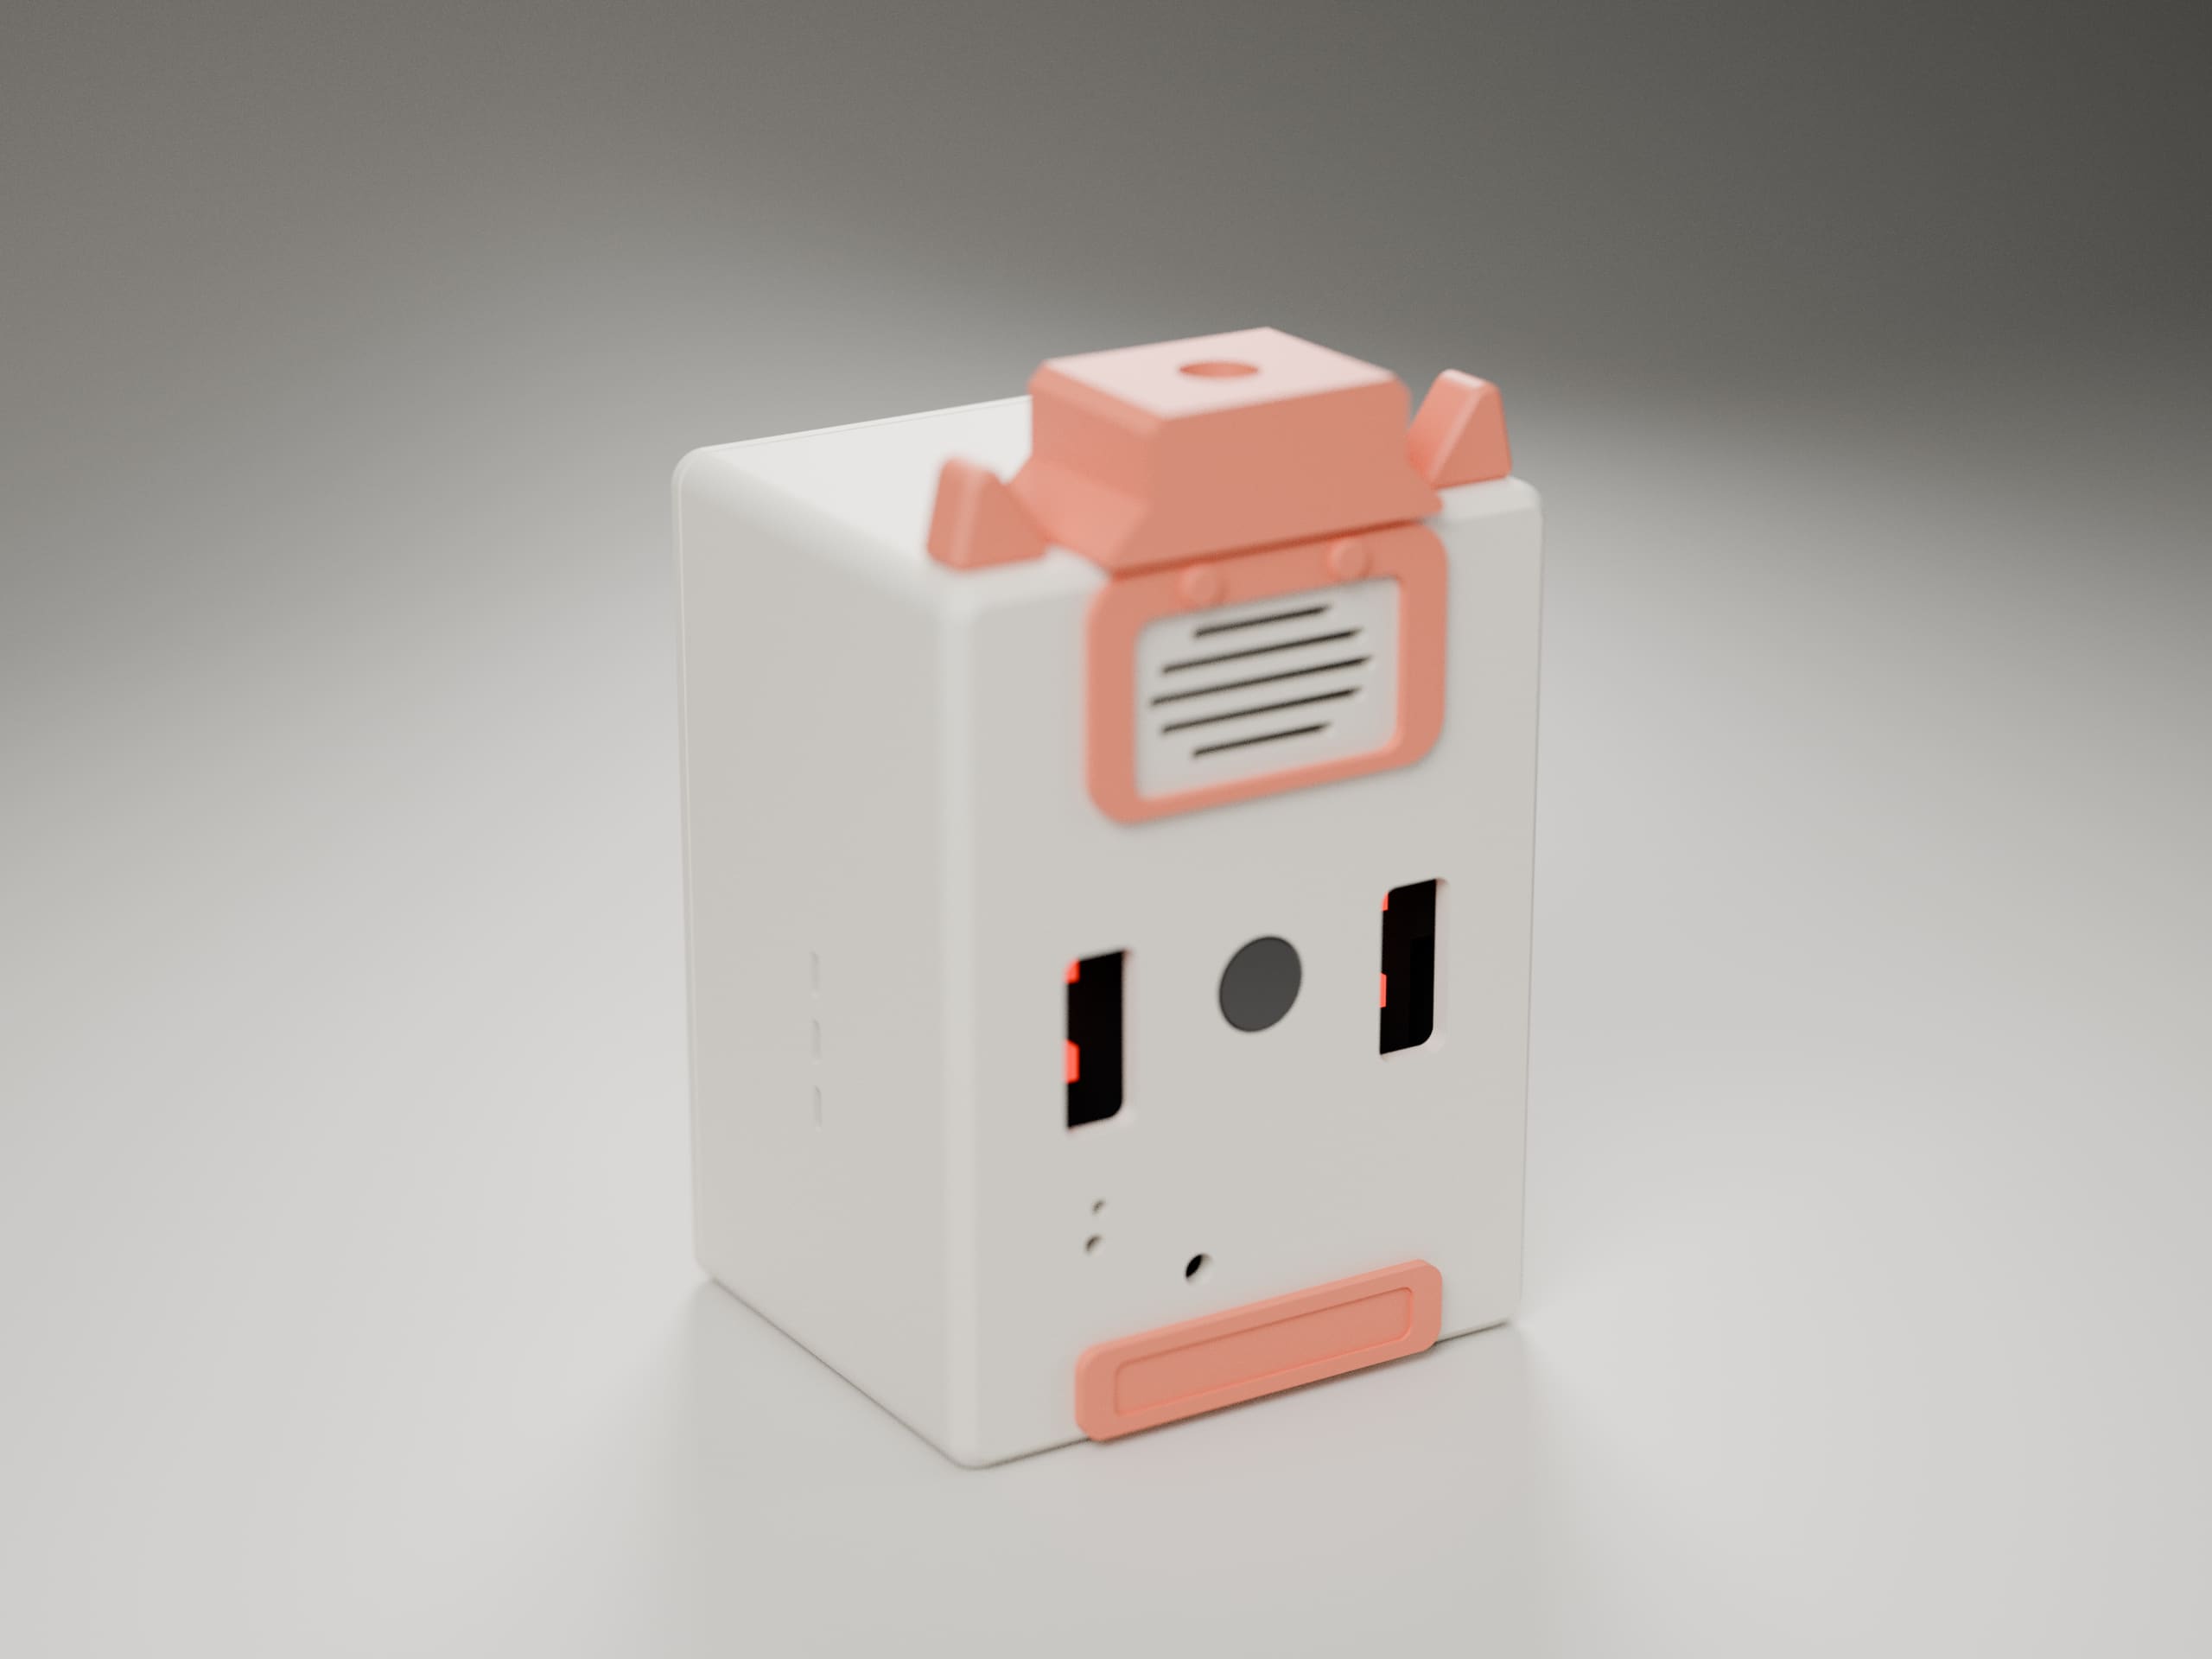
A render of CommandAGI Cam-002 in a studio, the view swinging one way and back: the printed enclosure with its lens, speaker grille, ears and hat.

Part

Cam-002: an ESP32-S3 camera with a mic, a speaker and LTE, in a printed case.

Buy one

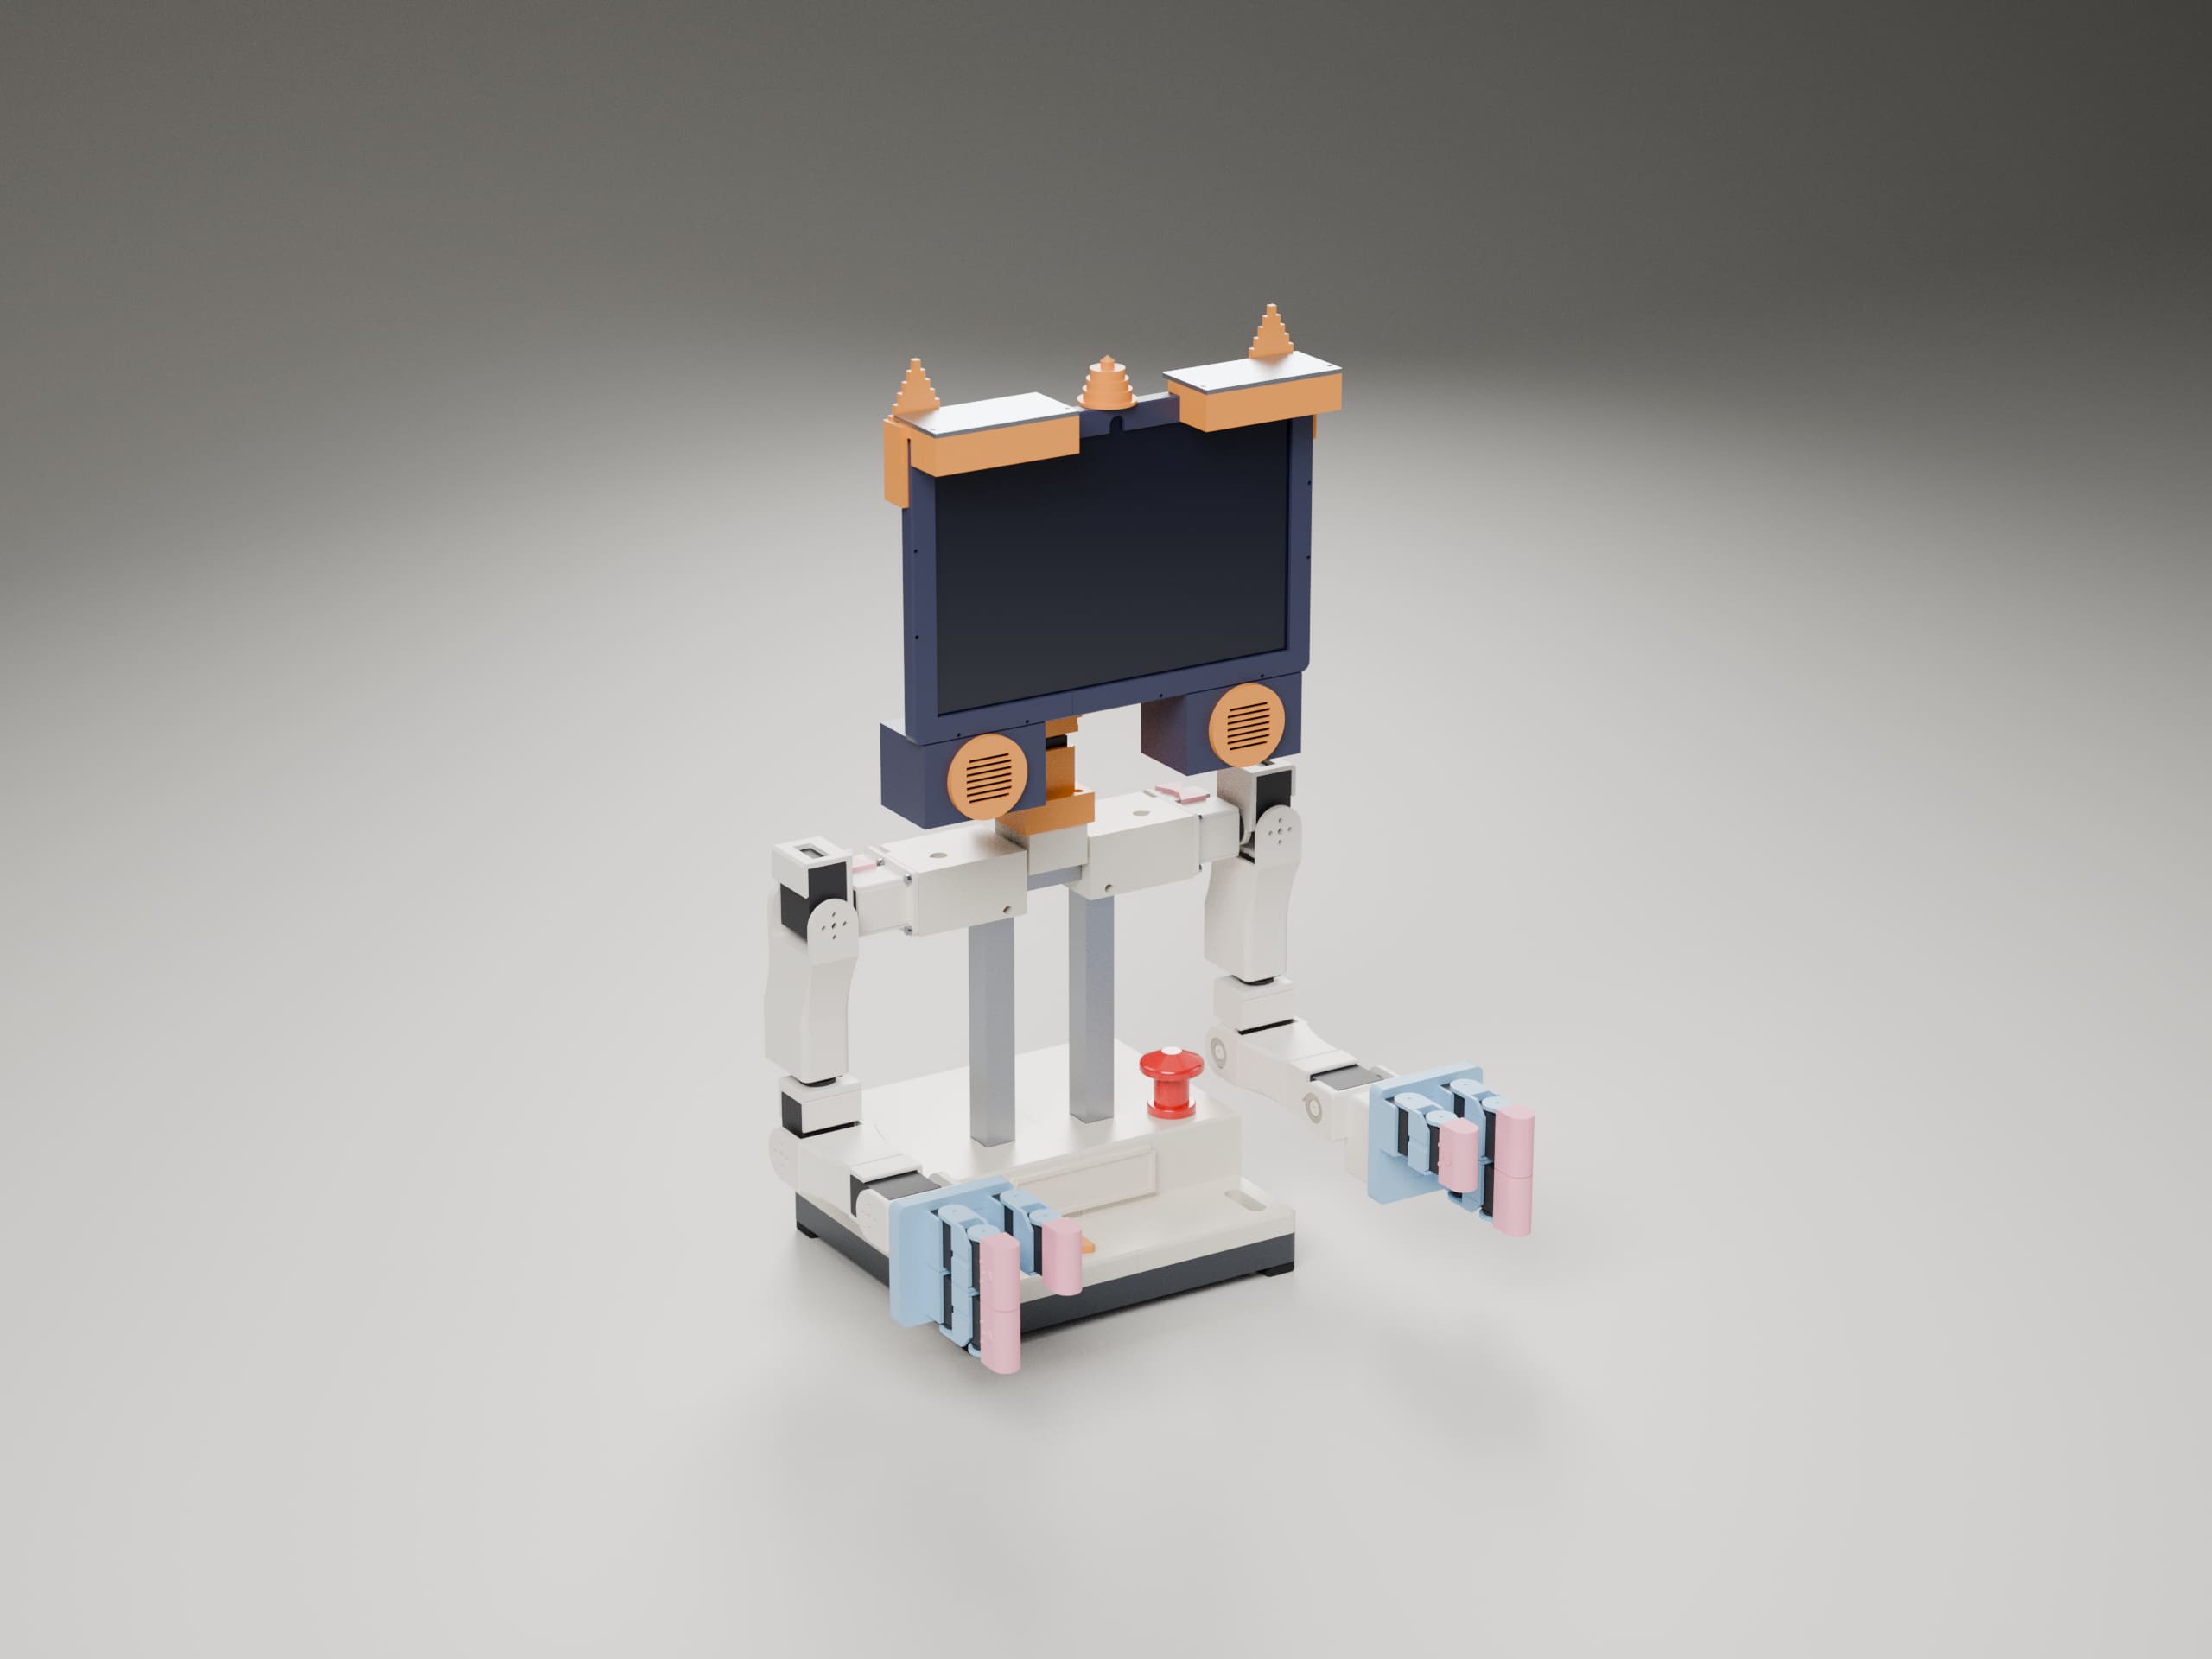
A render of CommandAGI DeskAssistant-001 in a studio, the view swinging one way and back: two arms with hands, a neck holding a tablet head and a lamp, on a weighted desk base.

Assembly

The SO-101 arm, and DeskAssistant-001: two arms with hands, a neck and a tablet head on a desk base.
Buy one

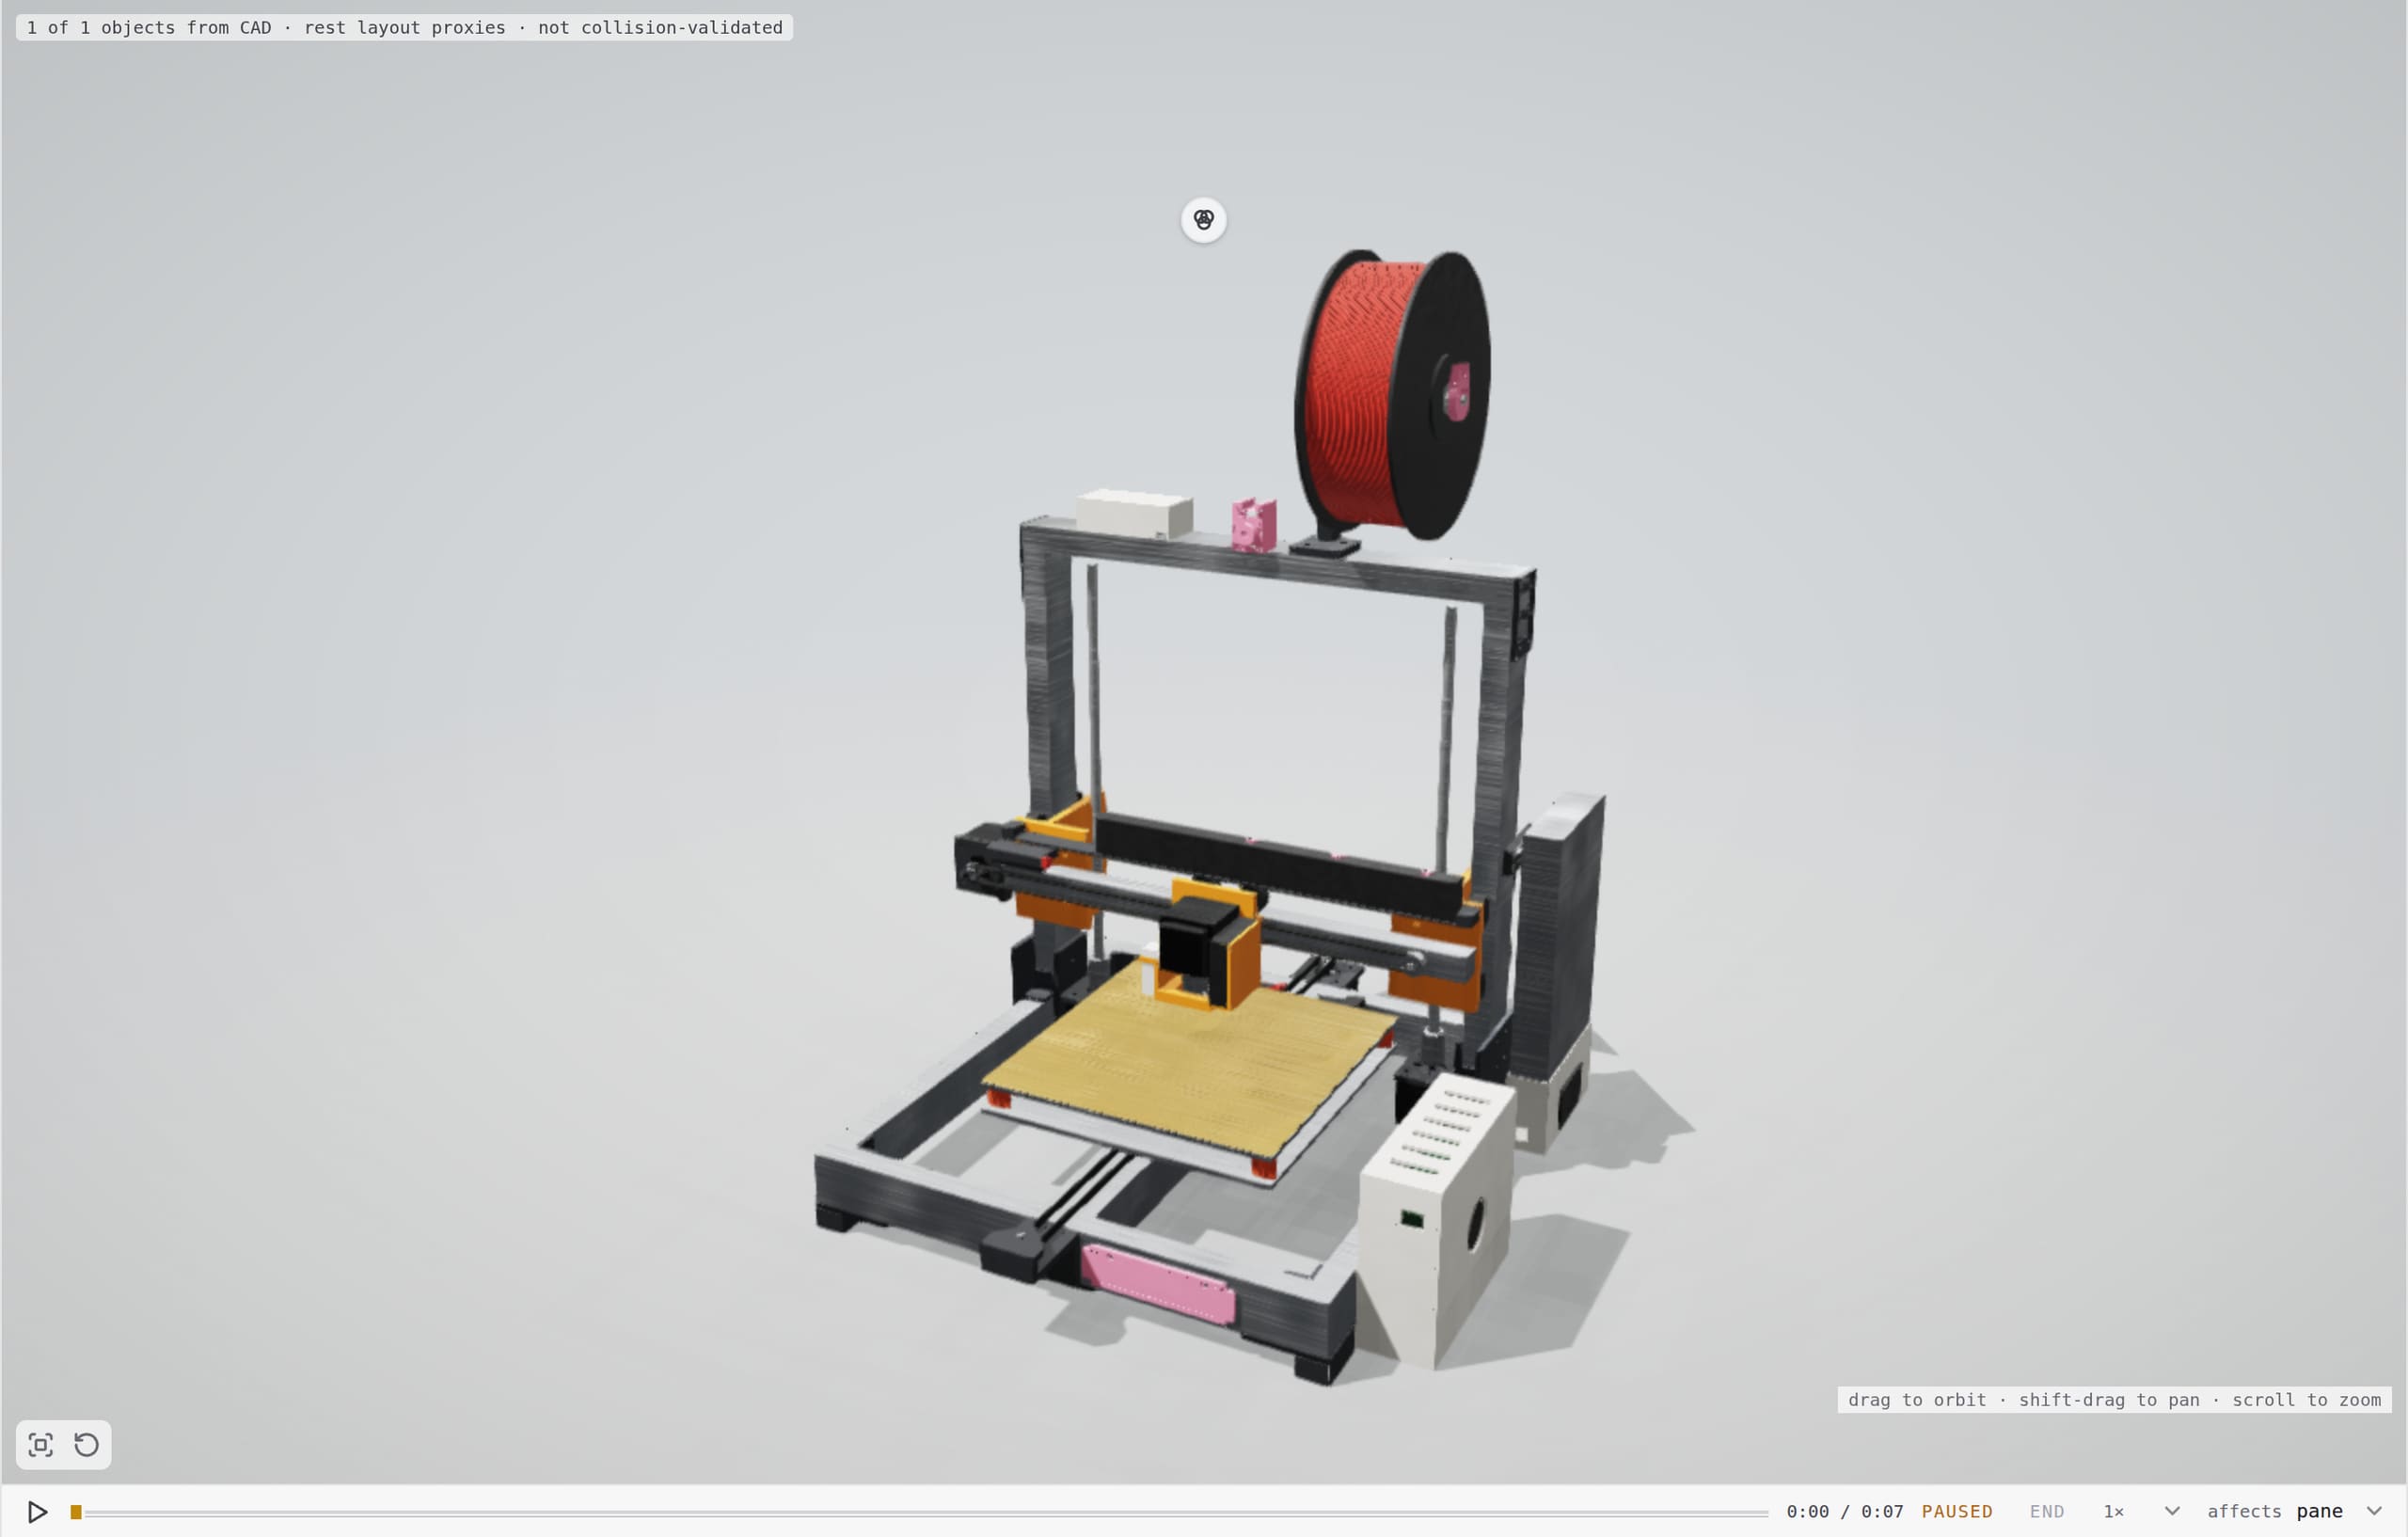
The CommandAGI-Printer-001 world replaying its print run (an illustrative record): the print head moves over the bed.The CommandAGI-Printer-001 world replaying its print run (an illustrative record): the print head moves over the bed.

Machine

Printer-001: a 220 mm printer on Klipper, with LTE. Its prints are runs on the record.
Buy one

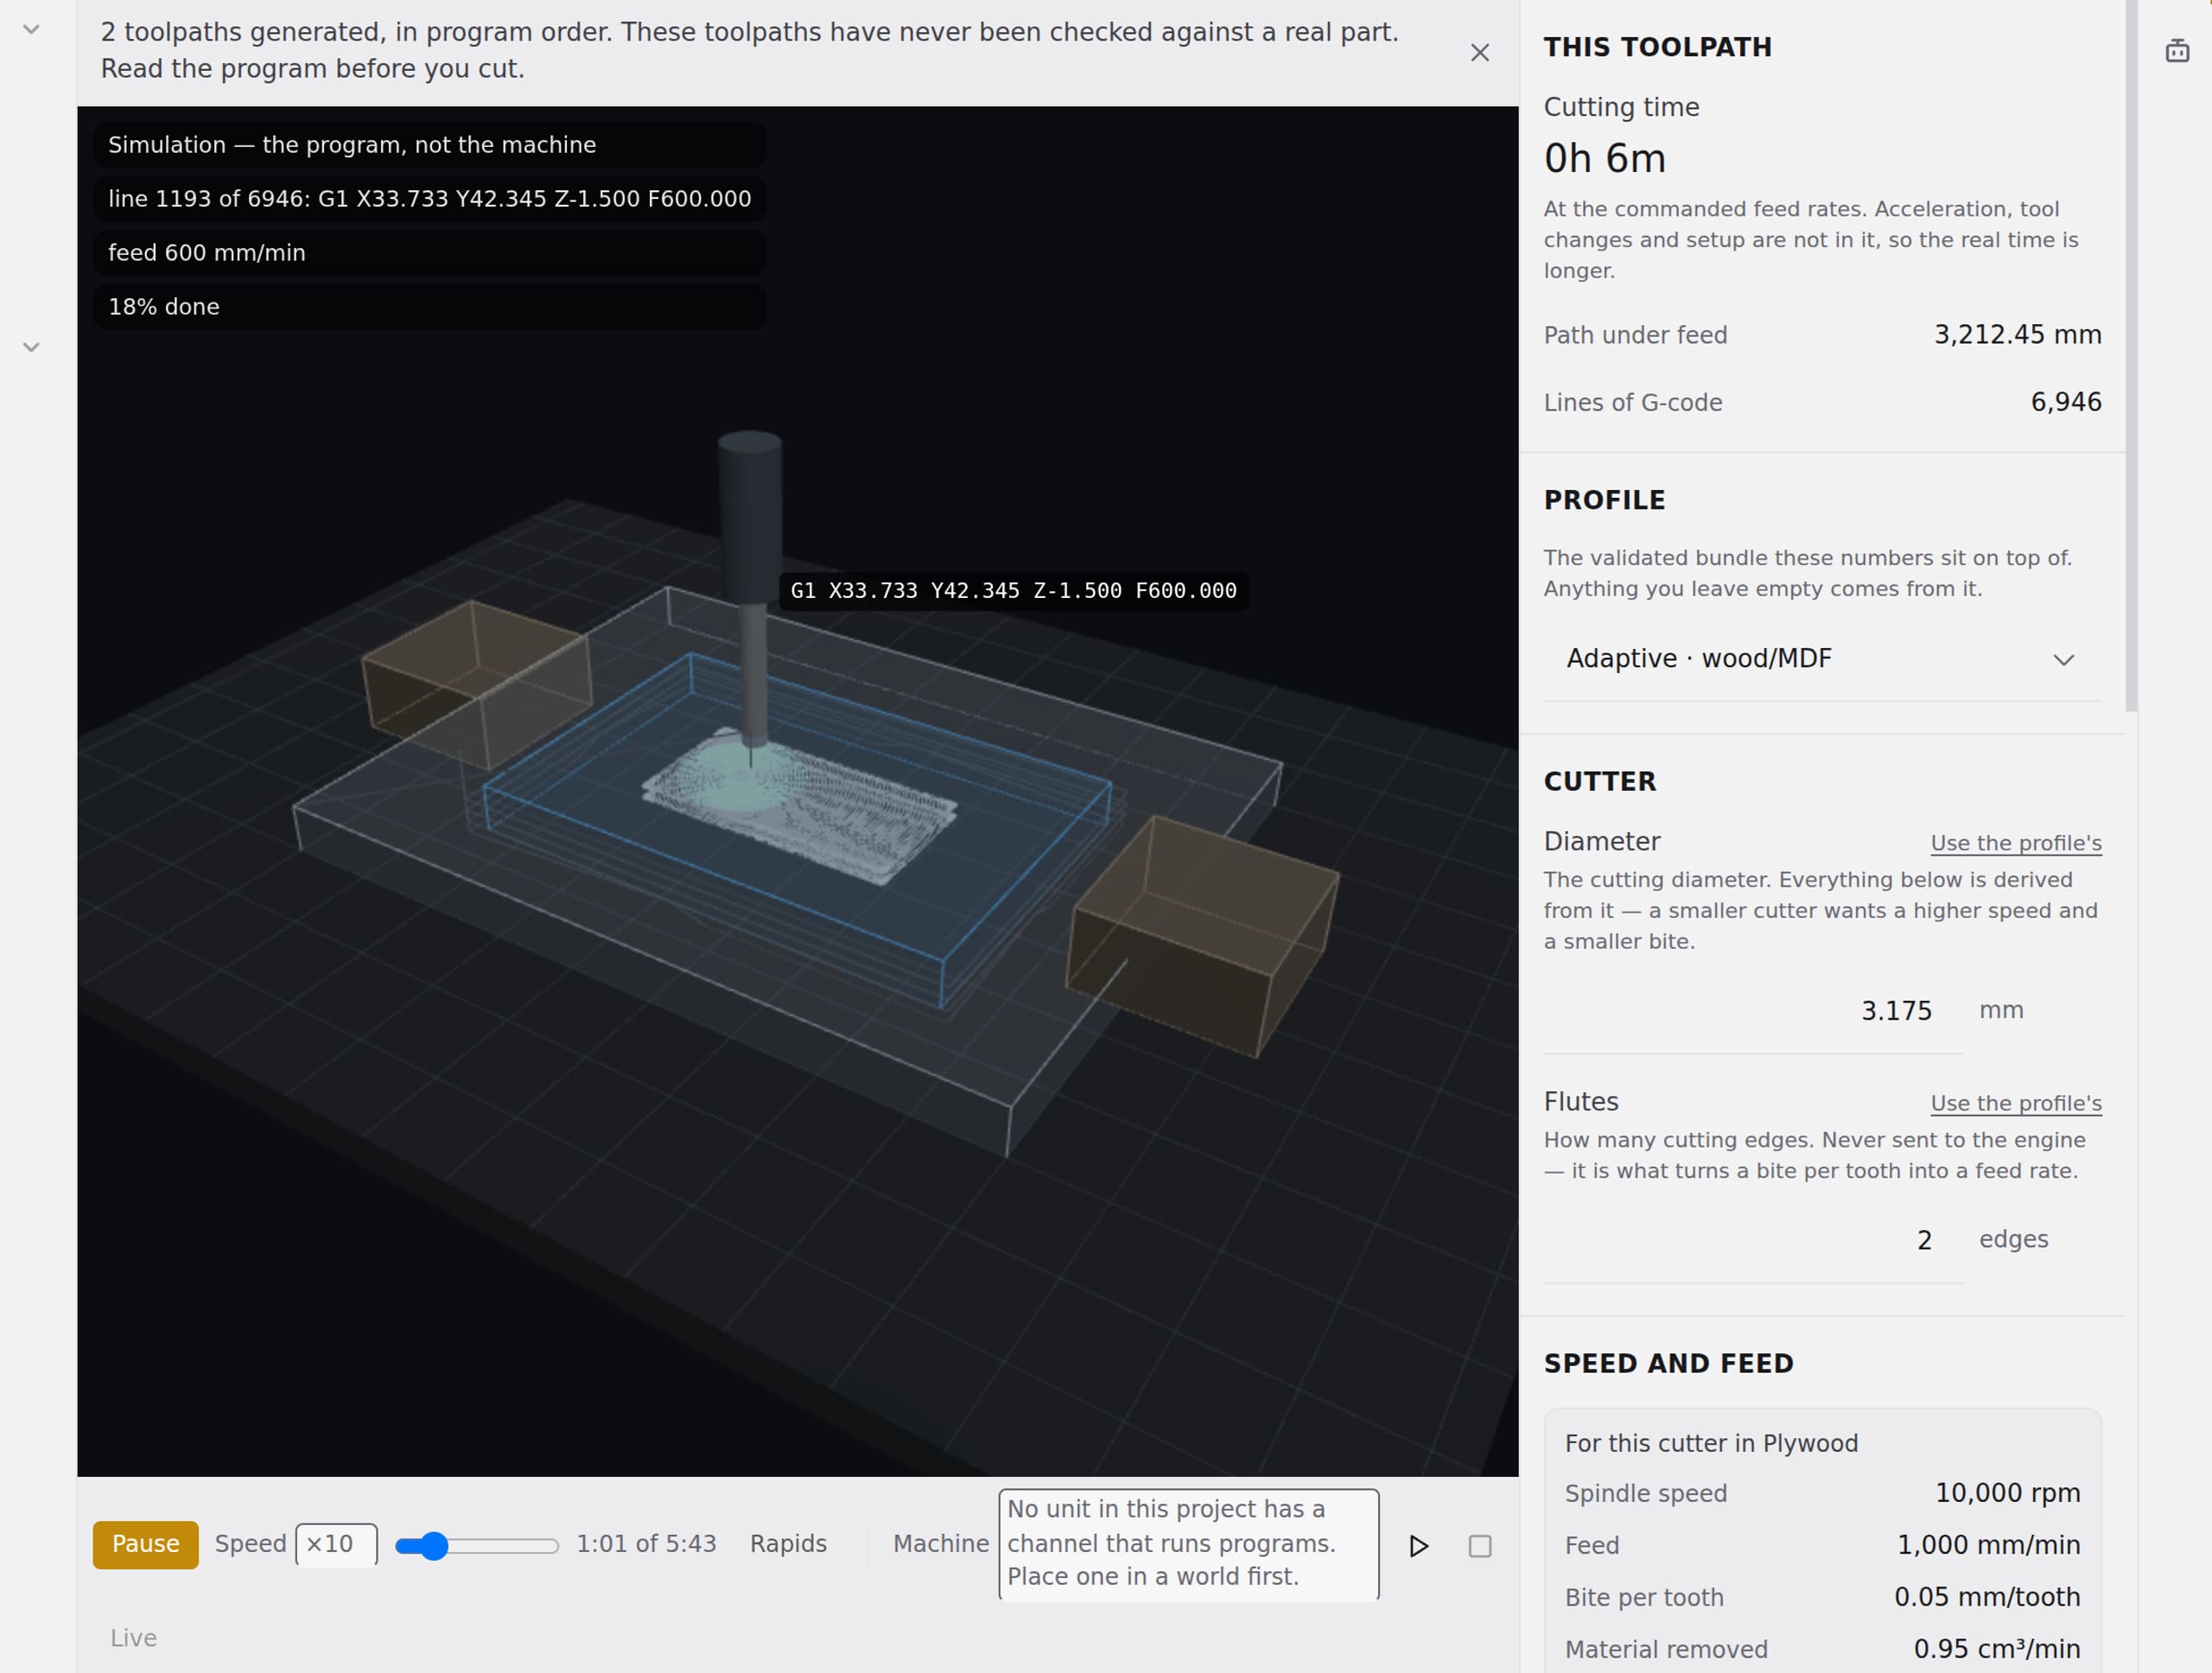
A bracket plate in the 3D app's CAM mode: Generate writes the G-code, and the simulation cuts it line by line between the clamps.A bracket plate in the 3D app's CAM mode: Generate writes the G-code, and the simulation cuts it line by line between the clamps.

Factory

Router-001, a 4 × 8 ft CNC router, and 5-Axis-001, a bench 5-axis mill: the machines that make the next machines.

See fabrication

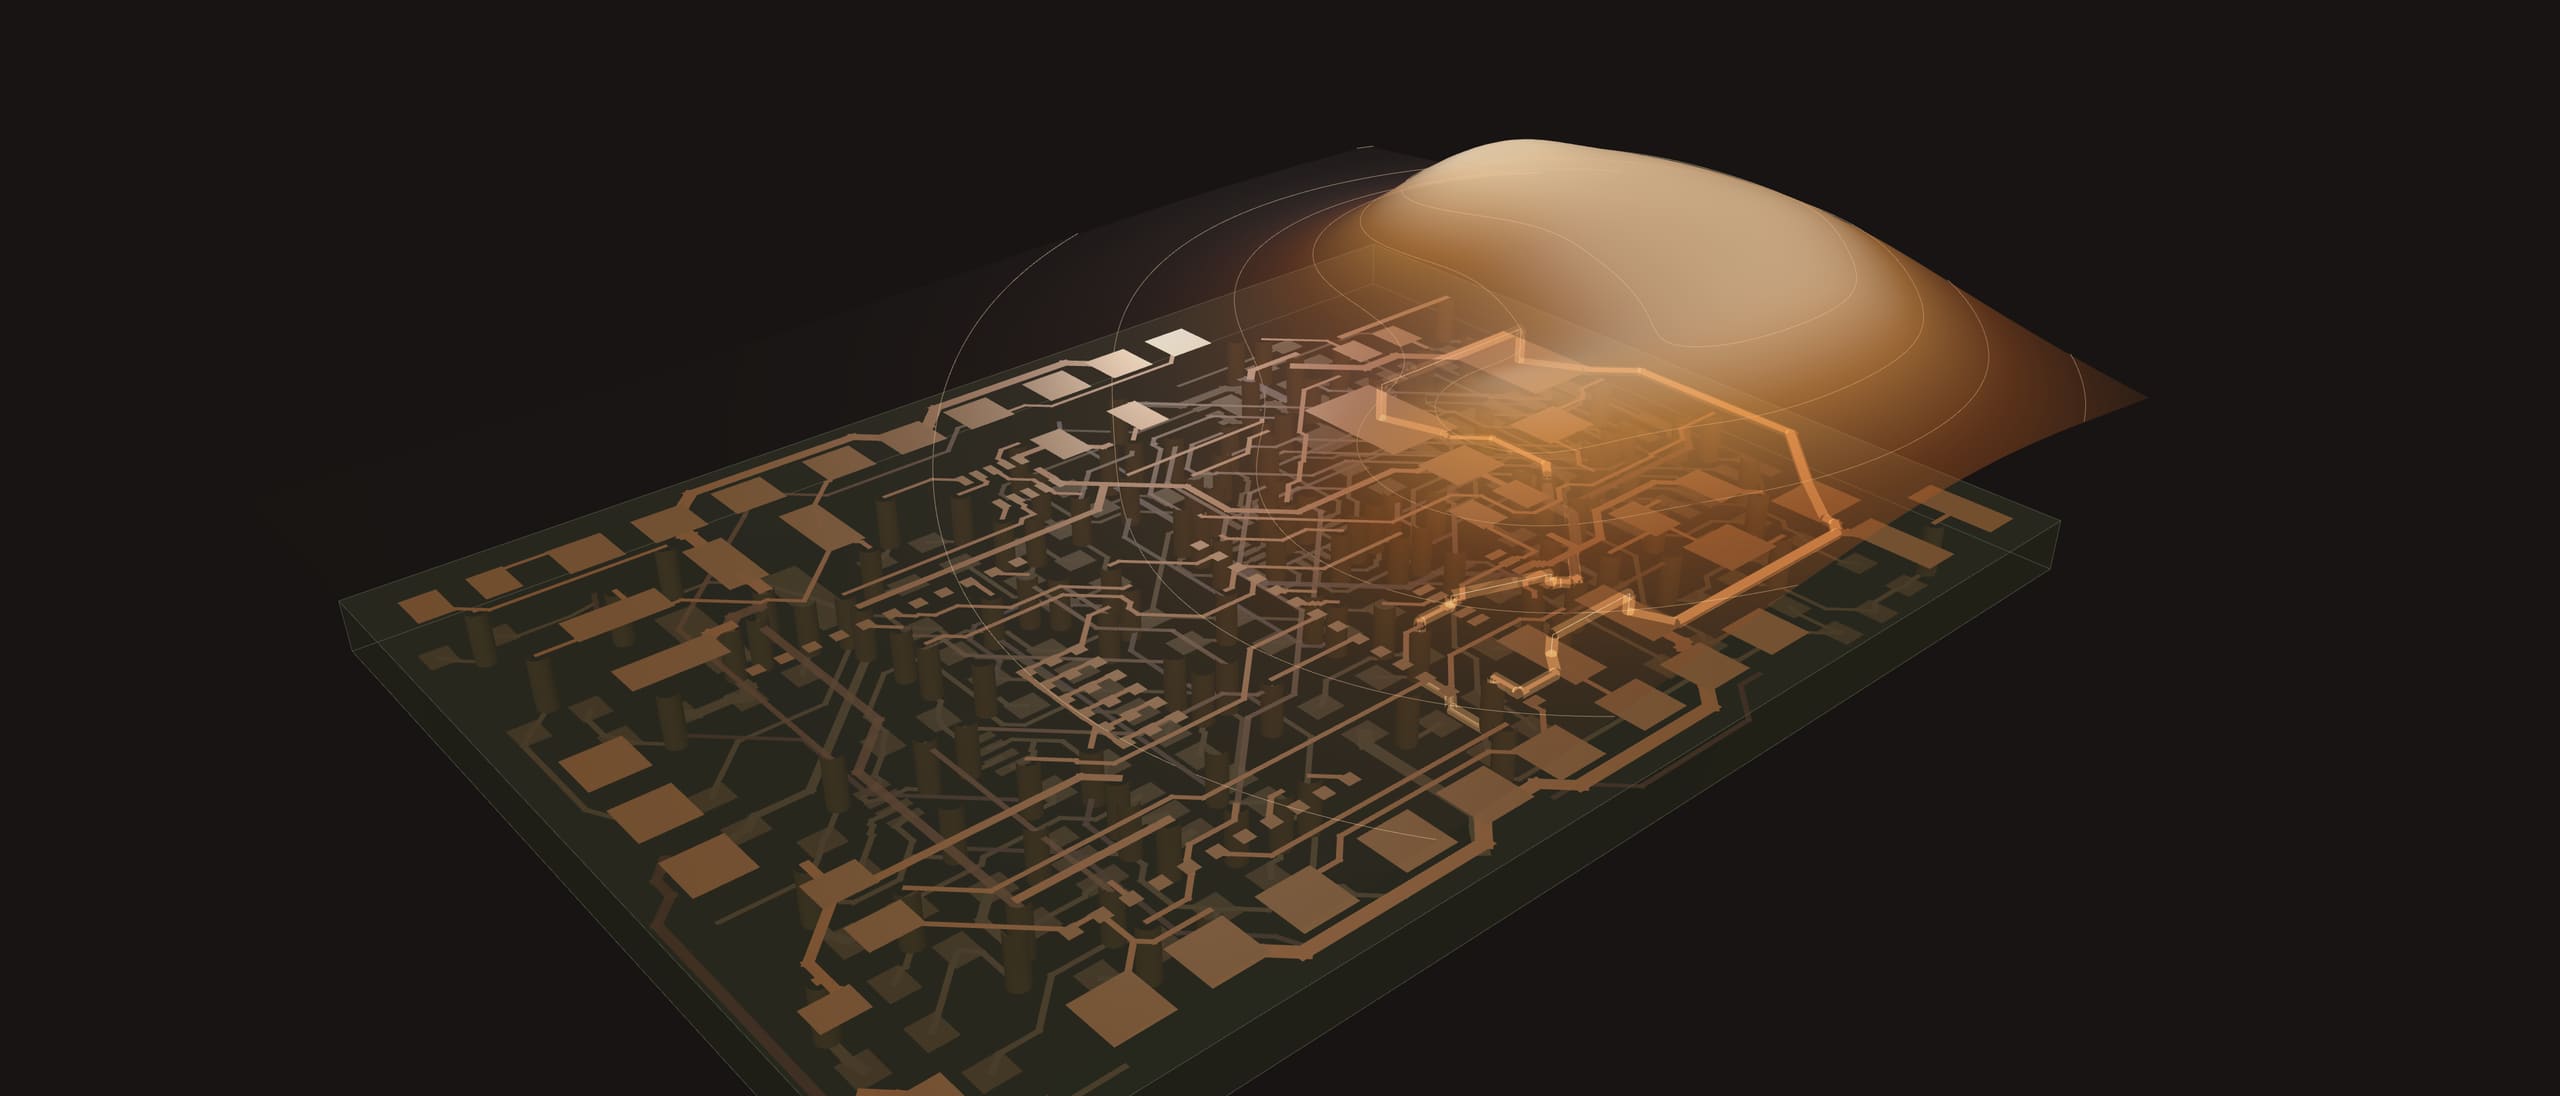
The board's traces, in their own field.

The hand board's real copper, solved for the field just above it and the coupling between two neighbouring traces.
See the file formats

Simulated: the magnetic near field of the robot hand board's 6 V servo regulator, drawn as a glowing surface over the copper, then a cut through the board where the regulator's switching trace crosses over a touch-sensor line, with its electric field lines.

Start with the example.

The board and the assembly are plain files in one folder, and they ship with the workbench. Check a whole robot the same way.