Many robots, one world.
A cell is a world with several robots in it, each with its own policy. They share the bench, the parts and the record.
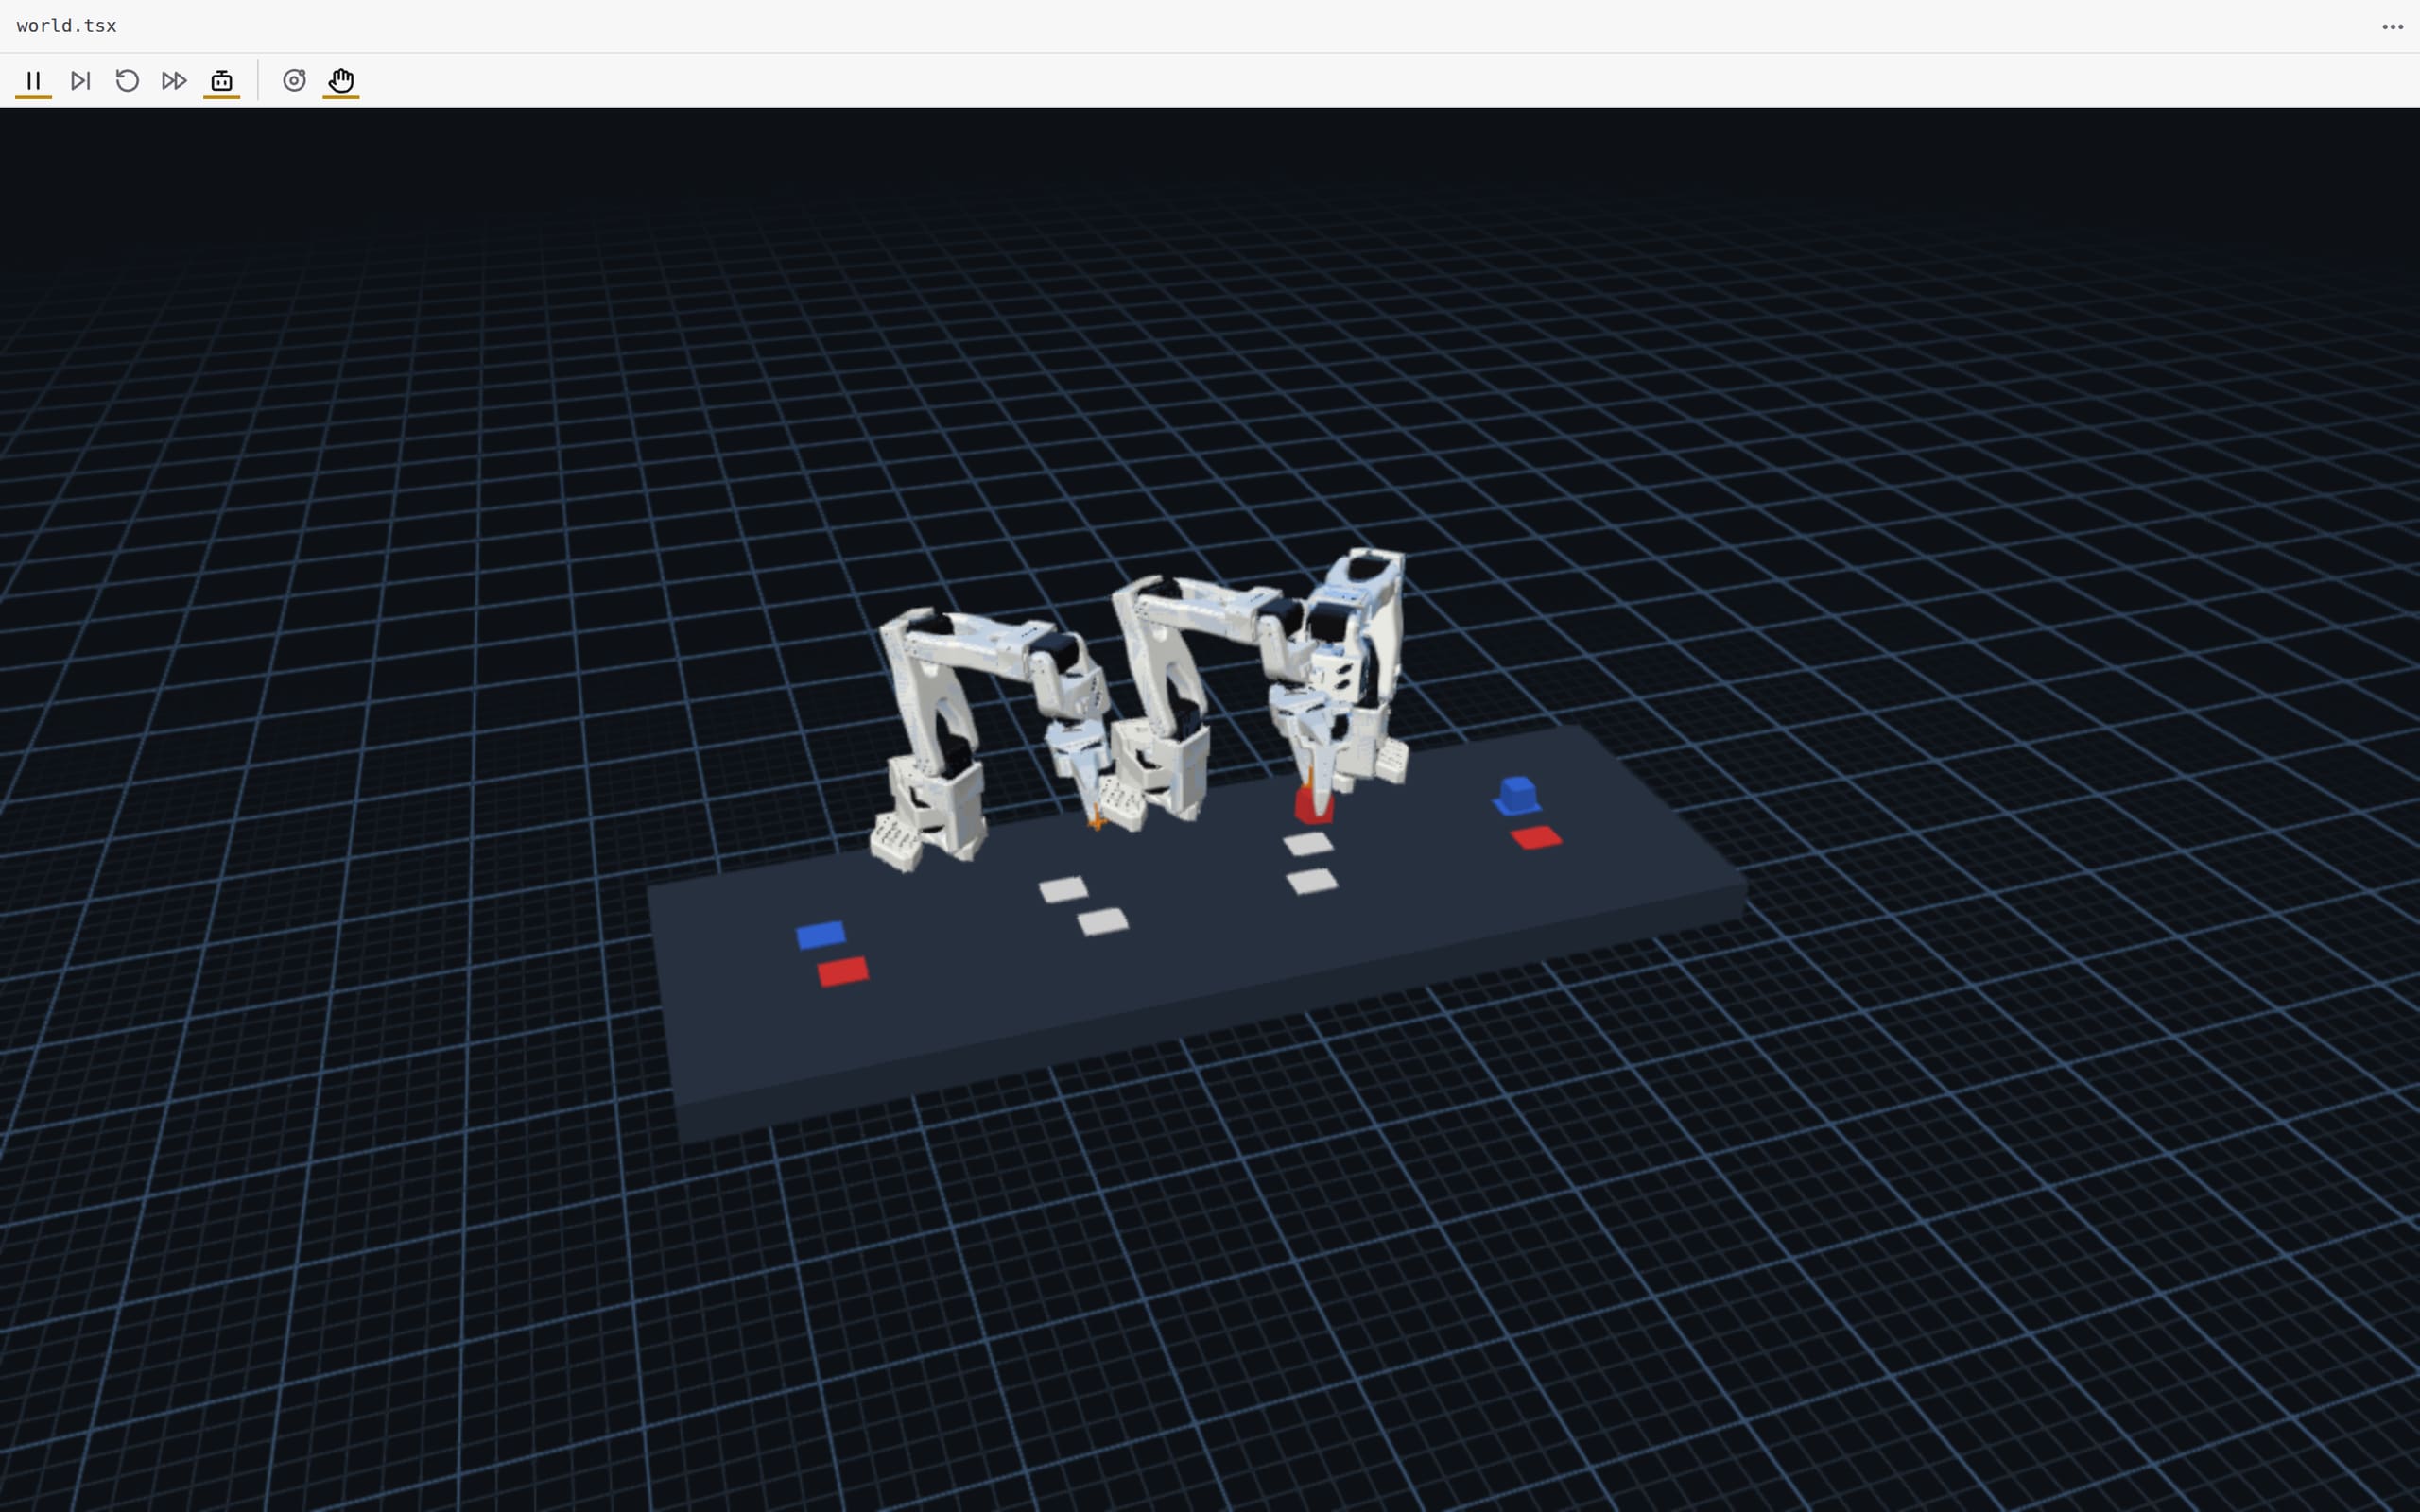
Case study · the relay
Two cubes cross the bench in 47 seconds.
Each arm reaches only its own pads and the pad it shares with its neighbour. So the red cube goes left to right in two handoffs, and the blue cube then goes right to left. The study stepped the world for 90 simulated seconds and timed each cube at each pad.
- SO-101 arms, each with a pick-and-place policy at 20 Hz
- 3
- for the red cube: handoffs at 7.4 and 15.0 s
- 22.6 s
- for the blue cube: handoffs at 32.2 and 39.8 s
- 47.4 s
- policy commands, none refused
- 998
Simulated
cloud://global/worlds/robot-relay/world.tsxResultado case-studies/robot-cells/stats.jsonHerramienta scripts/sites/case-studies.mjs robot-cells (sim-engine.js, Rapier)Se ejecutó en This computer (dell-gb10-1)Cuándo Where they stopped
The blue cube ended on its mark. The red one, 24 mm off.
The red cube came within 20 mm of its end pad at 22.6 s, but after 90 s it rested 24 mm from the pad's centre. The blue cube rested on its pad's centre. A cell's record shows where each part is at each step, so a small error like this is found in the world, not on the floor.
Simulated
- from the blue end pad's centre at 90 s
- 0 mm
- from the red end pad's centre at 90 s
- 24 mm
- real time on this computer: 7.9 s for the 90 s
- 11×
cloud://global/worlds/robot-relay/world.tsxResultado case-studies/robot-cells/stats.jsonHerramienta scripts/sites/case-studies.mjs robot-cellsSe ejecutó en This computer (dell-gb10-1)Cuándo Lay out your cell.
Place the robots, the fixtures and the parts in one world, give each robot a policy, and run the whole cell before you build it.