From the design's mates to a robot's moves.
The pump's design, pump.3d.tsx, names how its parts fit. The world holds the same mates as joints that engage when a part is set in its place.
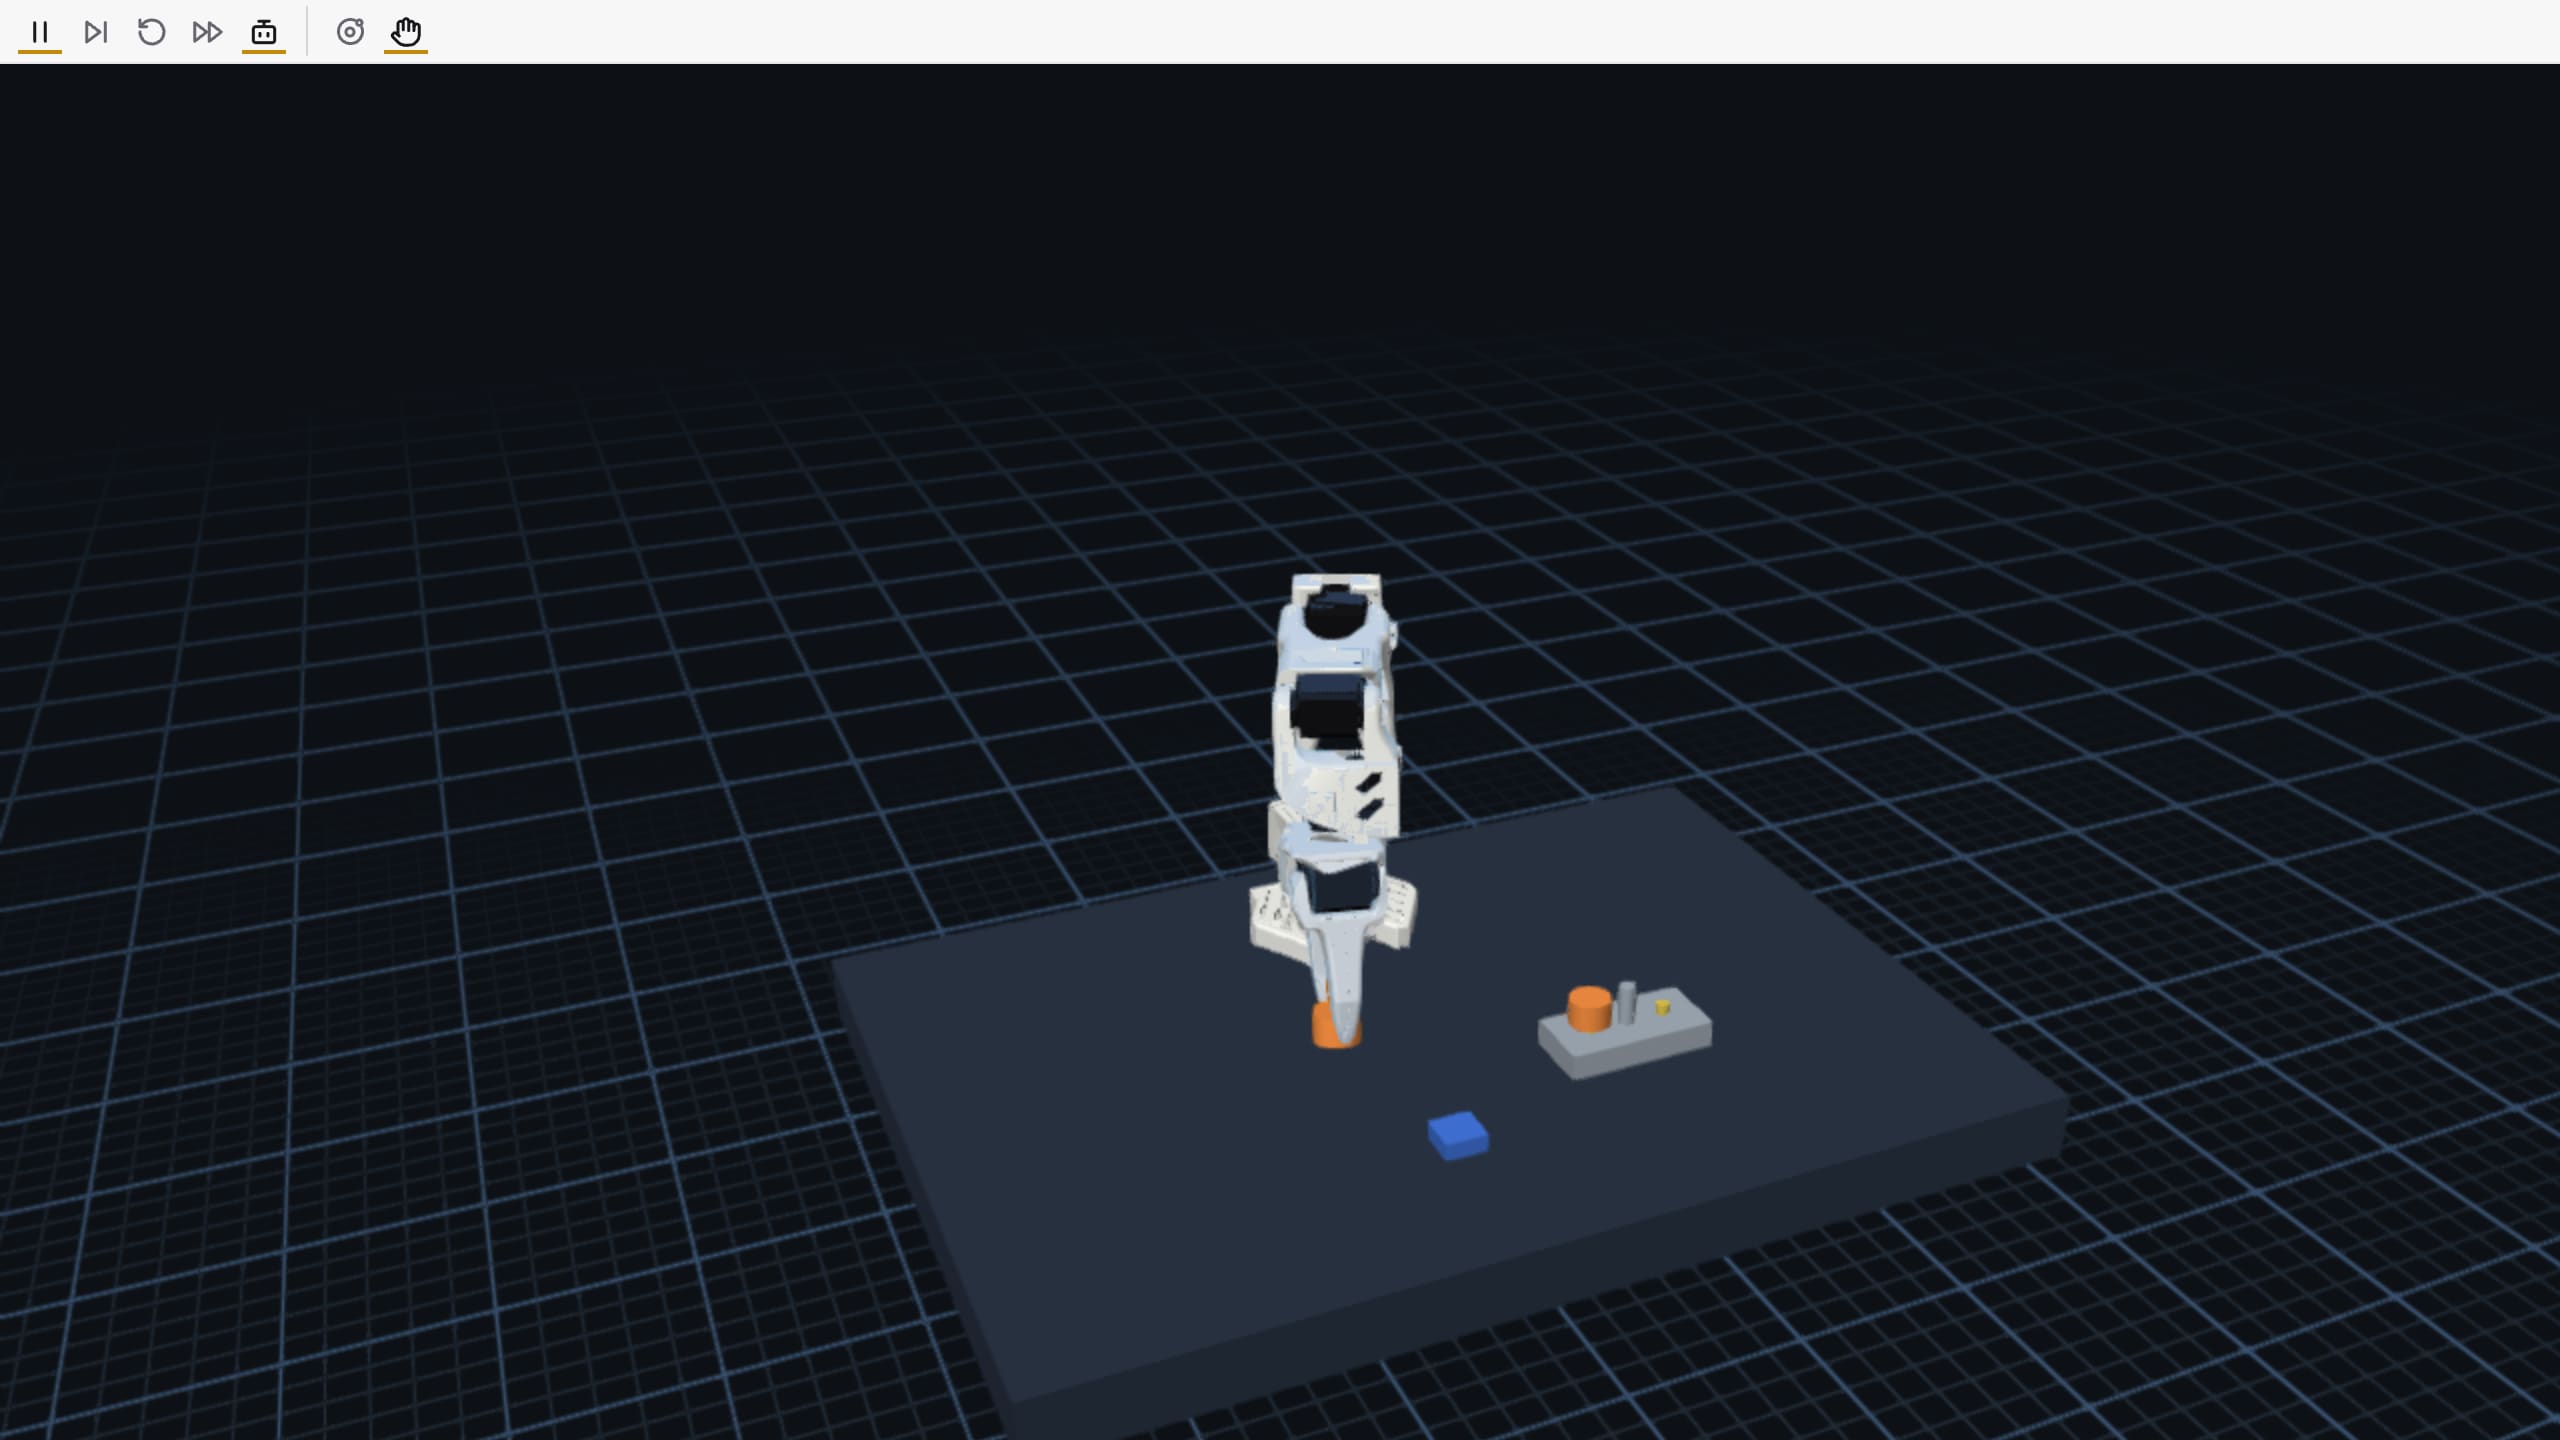
Case study · a two-lobe pump
Three parts seated in 27 seconds.
The arm takes each rotor onto its shaft, then the bearing cap onto its pillar. A part is held by its mate once it is let go within 6 mm of its place. The study stepped the world for 90 simulated seconds and timed each part.
- the drive rotor seated
- 7.6 s
- the idler rotor seated
- 17.1 s
- the cap seated
- 26.6 s
- from its place, each part, at 90 s
- 0 mm
Simulated
cloud://global/worlds/so101-pump/world.tsx输出 case-studies/assembly/stats.json工具 scripts/sites/case-studies.mjs assembly (sim-engine.js, Rapier)运行于 This computer (dell-gb10-1)时间 Then it runs
When all three seat, the shafts turn.
The policy's last step drives the two bearings in opposite directions. From 28.8 s to the end of the run, each shaft turned about 58.5 times, as two meshed lobes do.
Simulated
- mates: 2 bearings, 2 rotor keys and the cap's bolts
- 5
- turns of the drive shaft, and −58.4 of the idler
- 58.5
- policy commands, none refused
- 479
- real time on this computer: 2.2 s for the 90 s
- 41×
cloud://global/worlds/so101-pump/world.tsx输出 case-studies/assembly/stats.json工具 scripts/sites/case-studies.mjs assembly运行于 This computer (dell-gb10-1)时间 Assemble it before you build it.
Write the design with its mates, put it in a world beside a robot, and let the robot's policy try the assembly as often as you like.