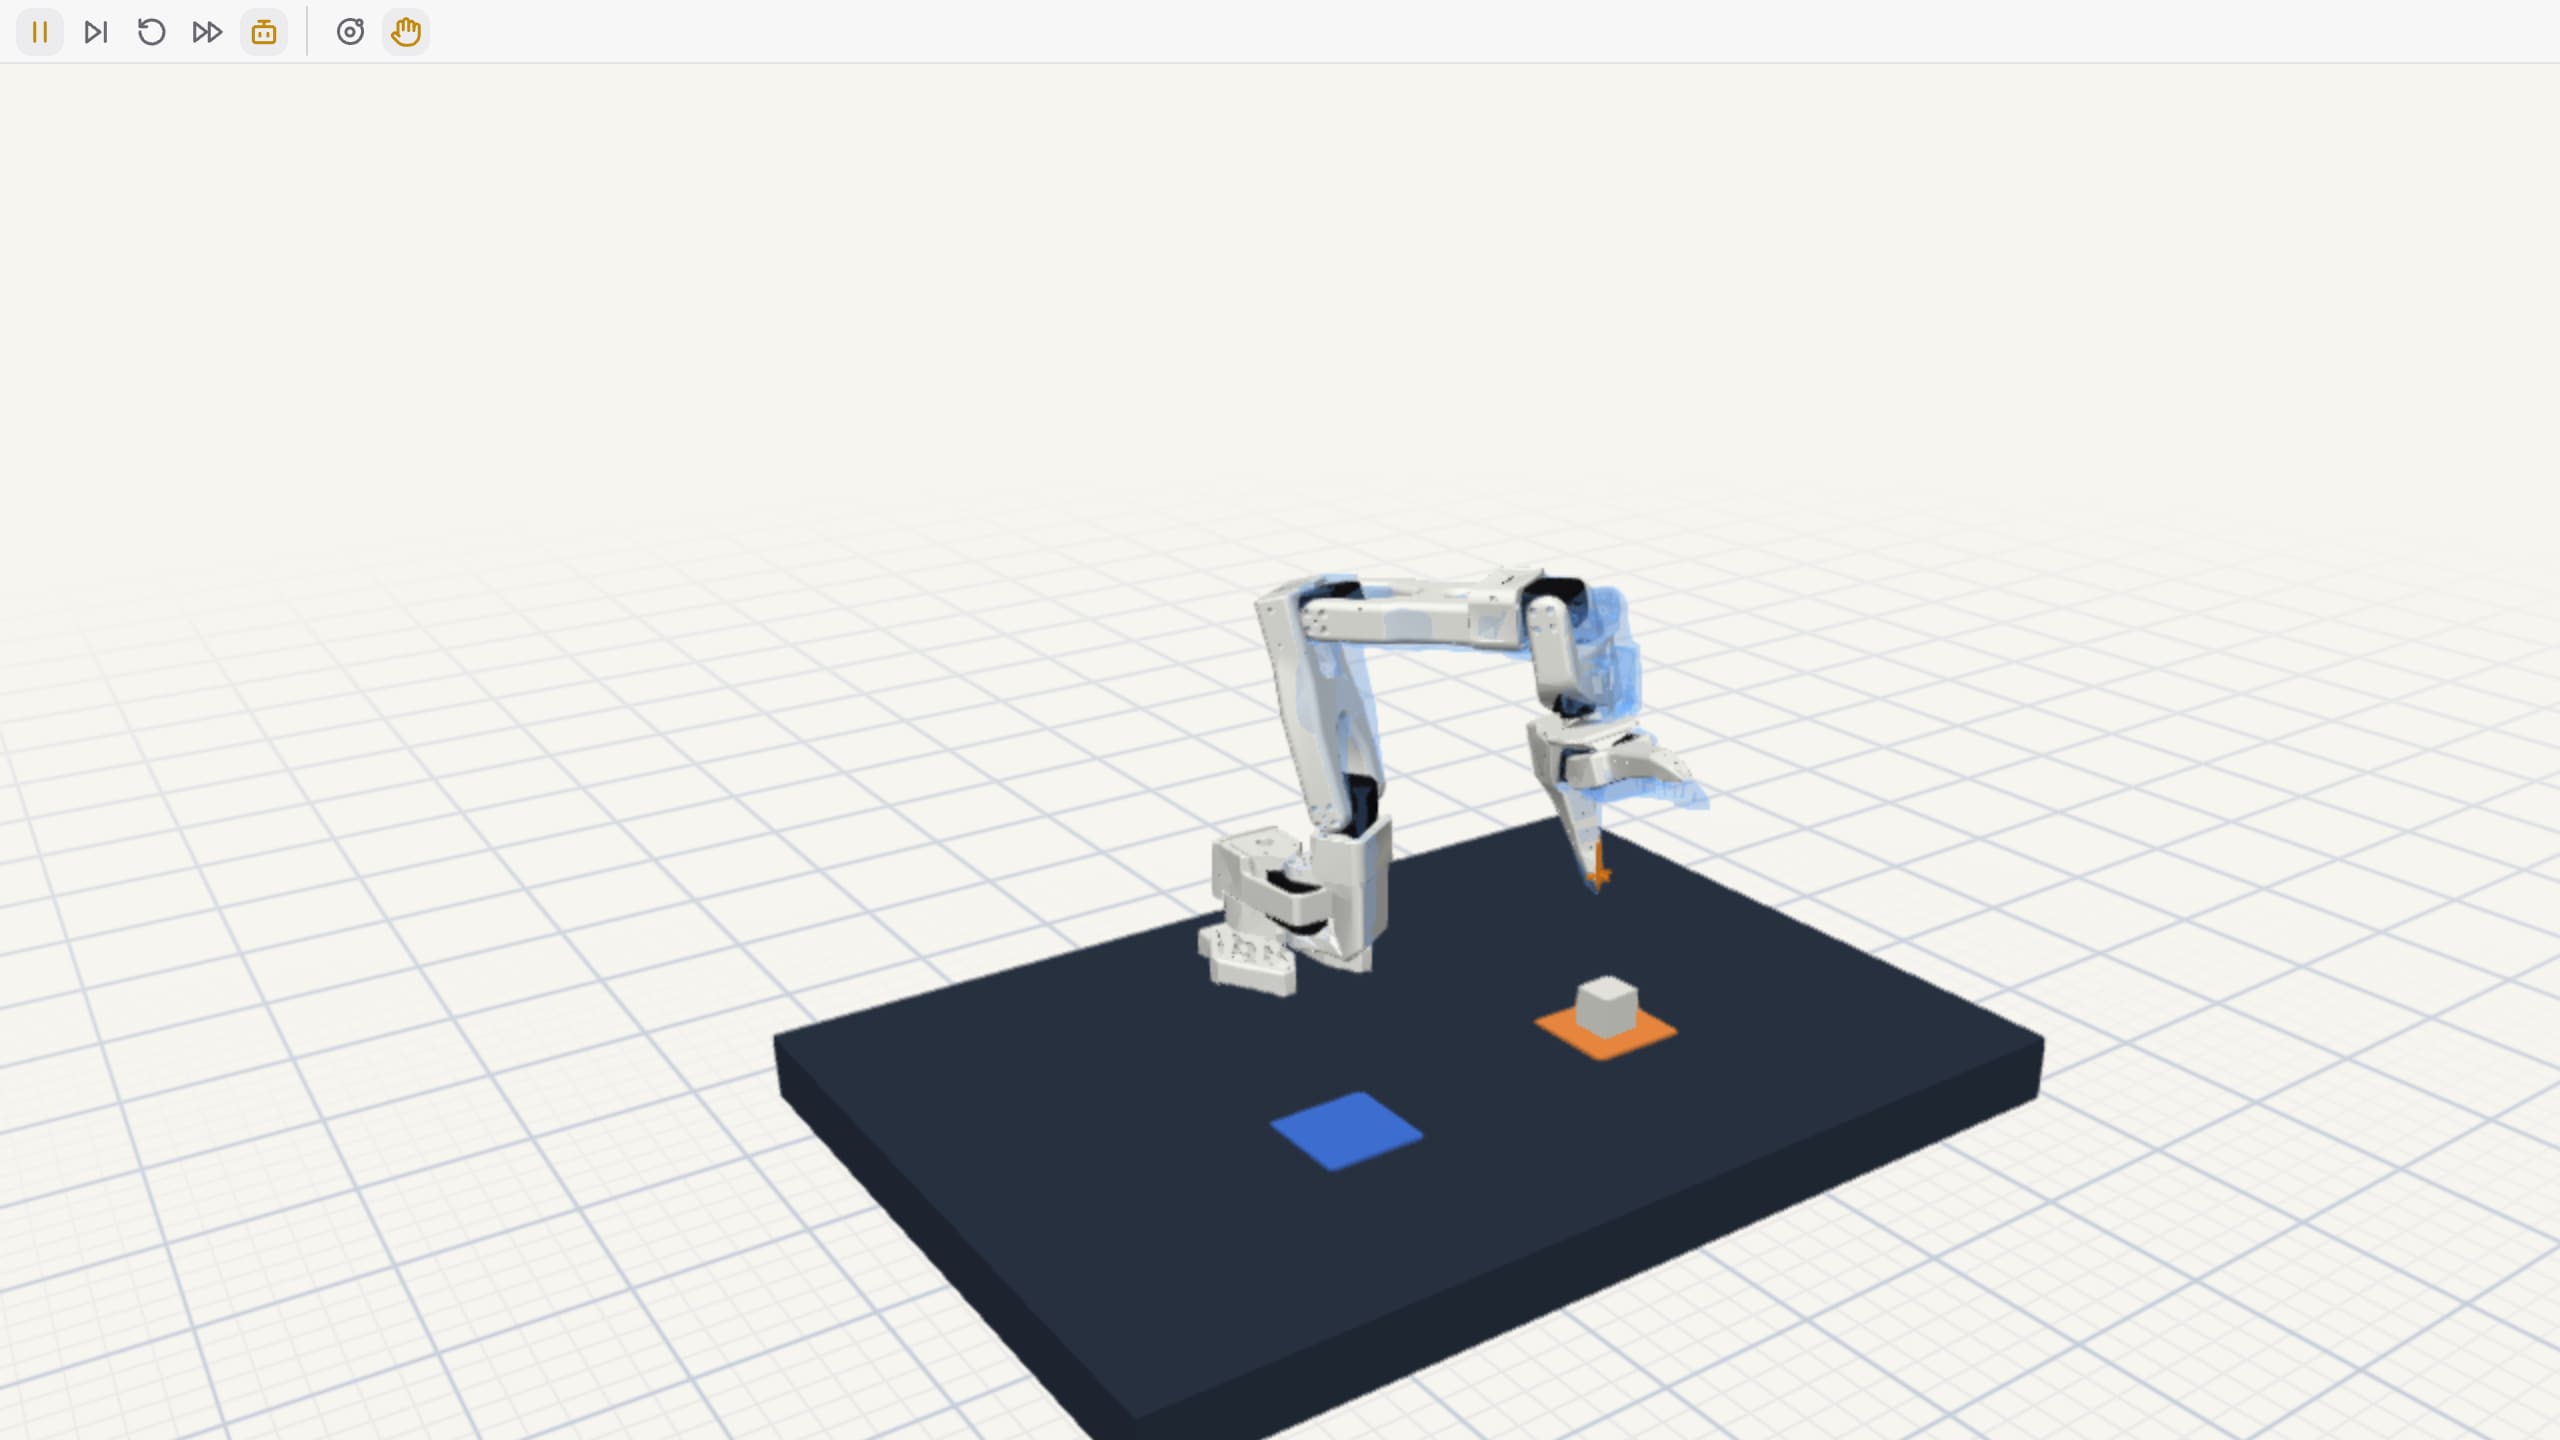
Watch it work before any machine moves.
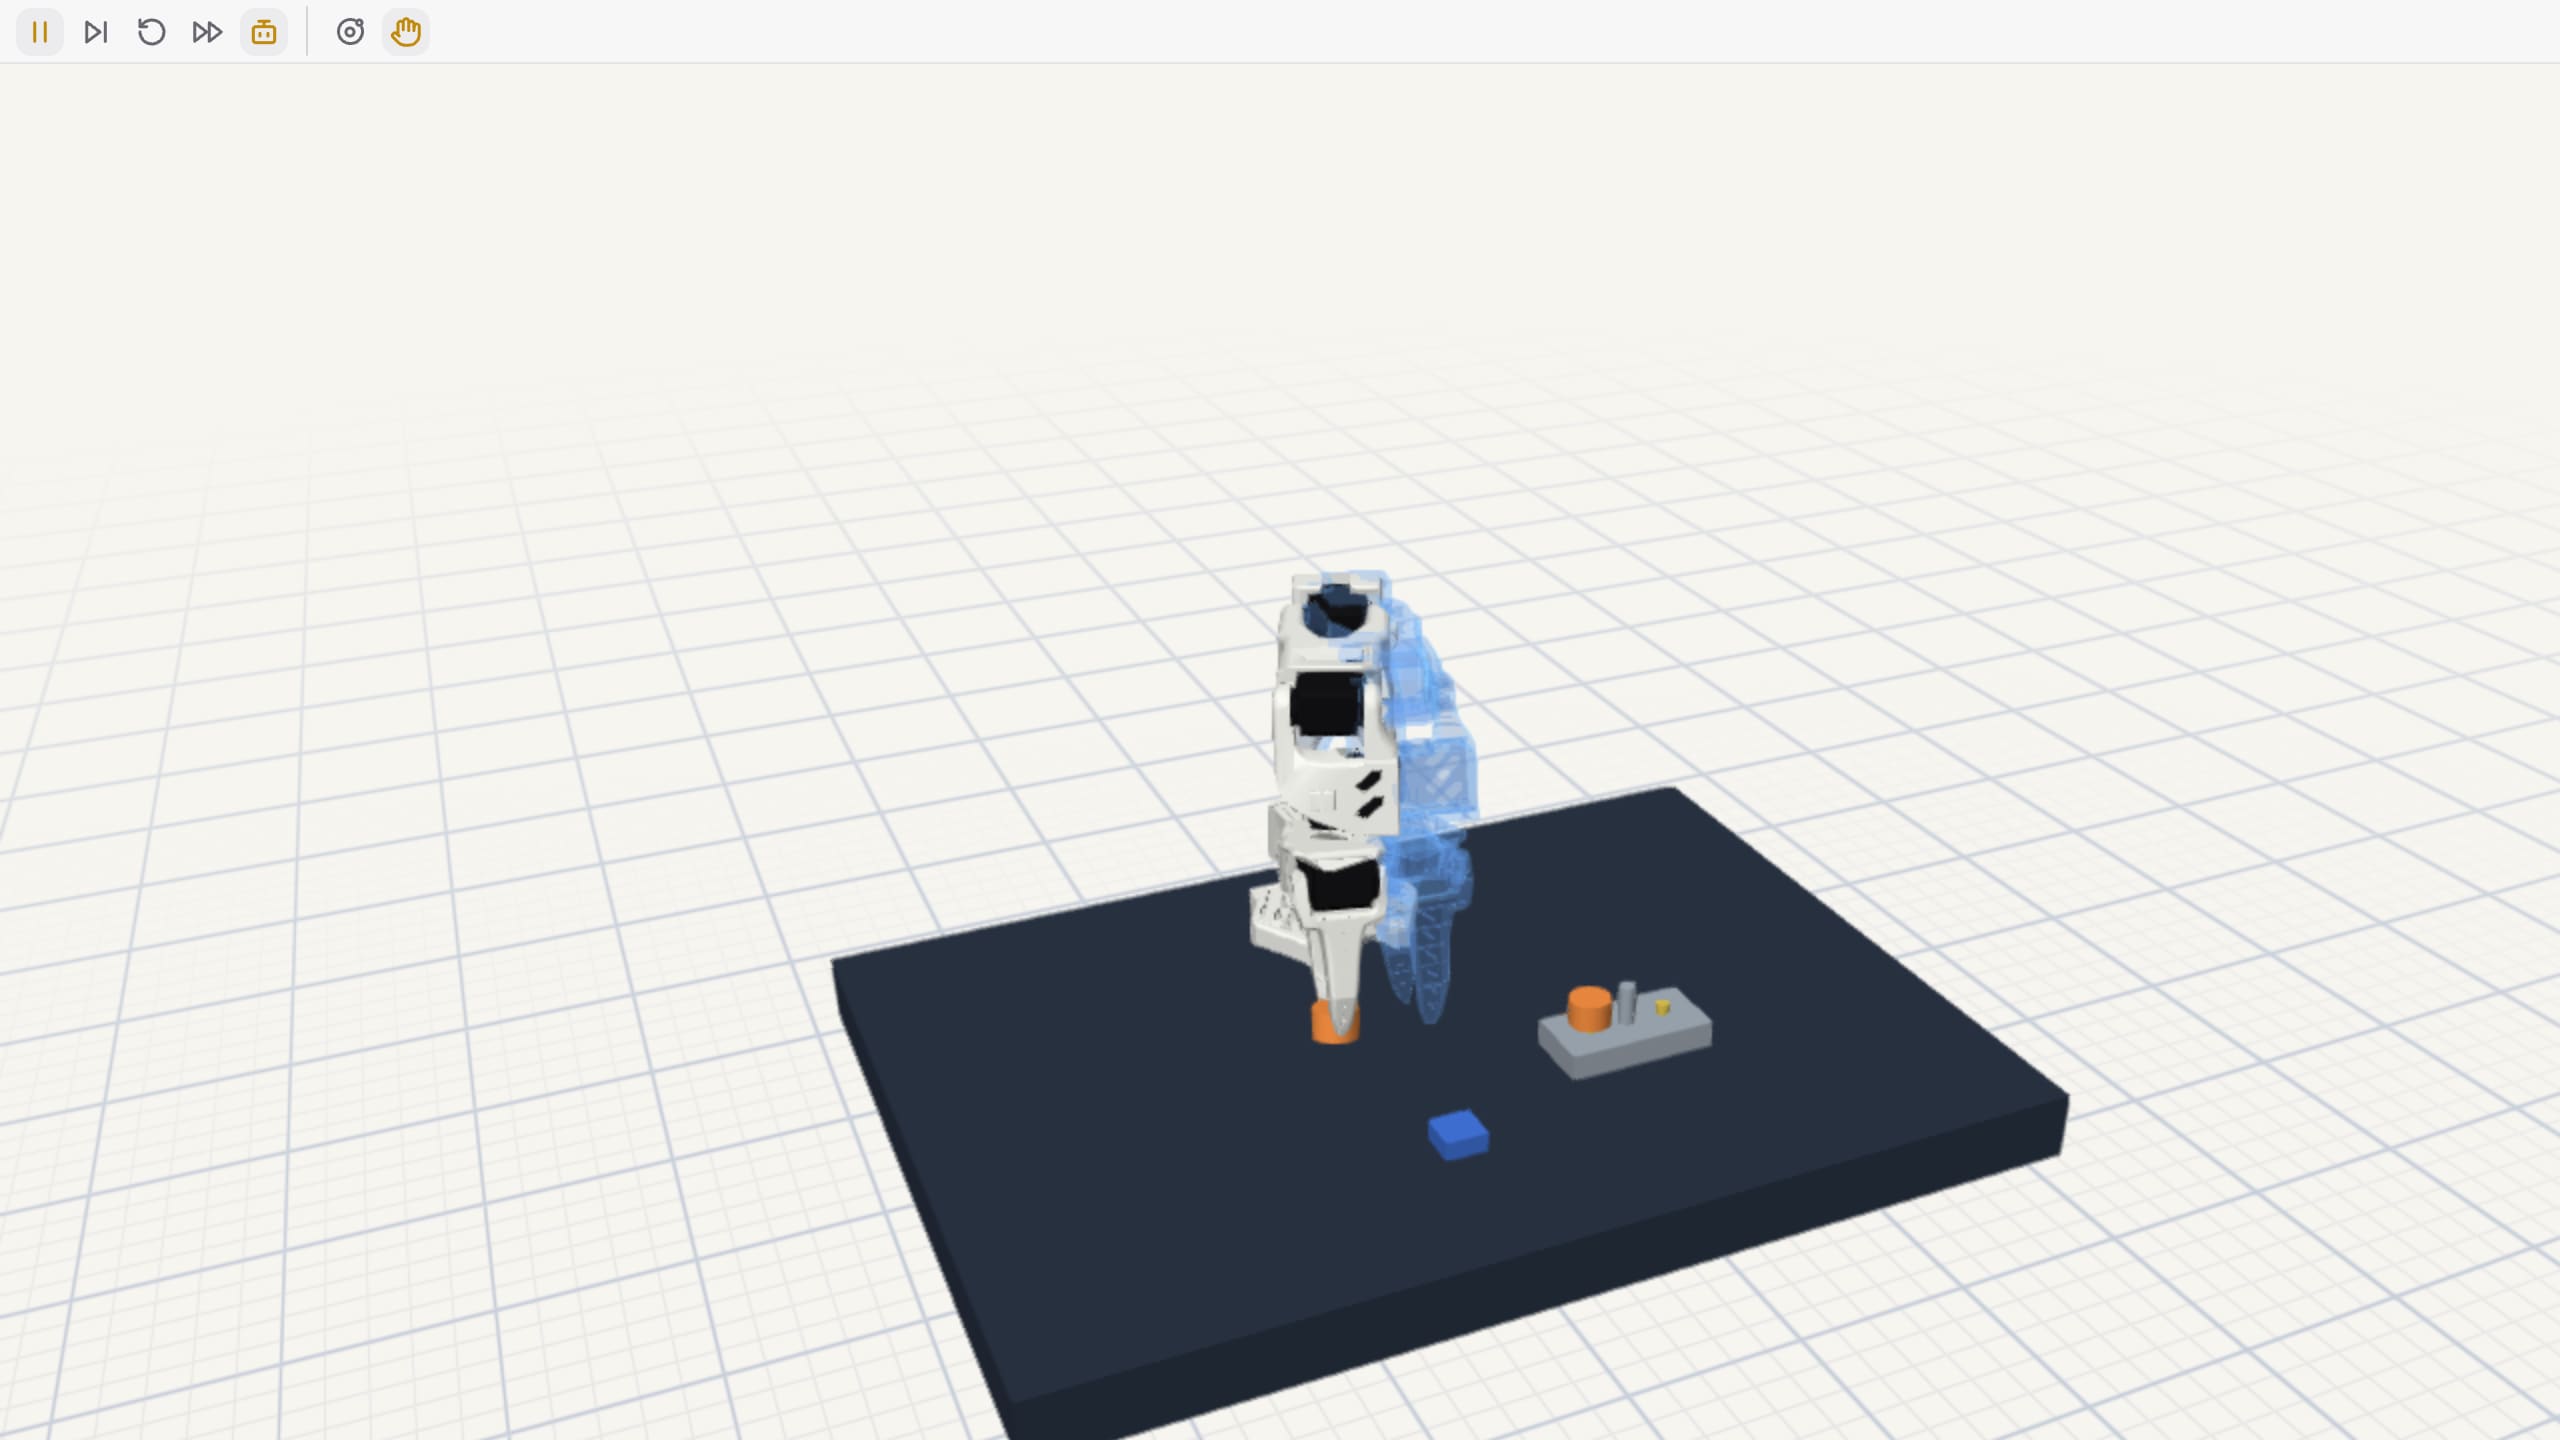
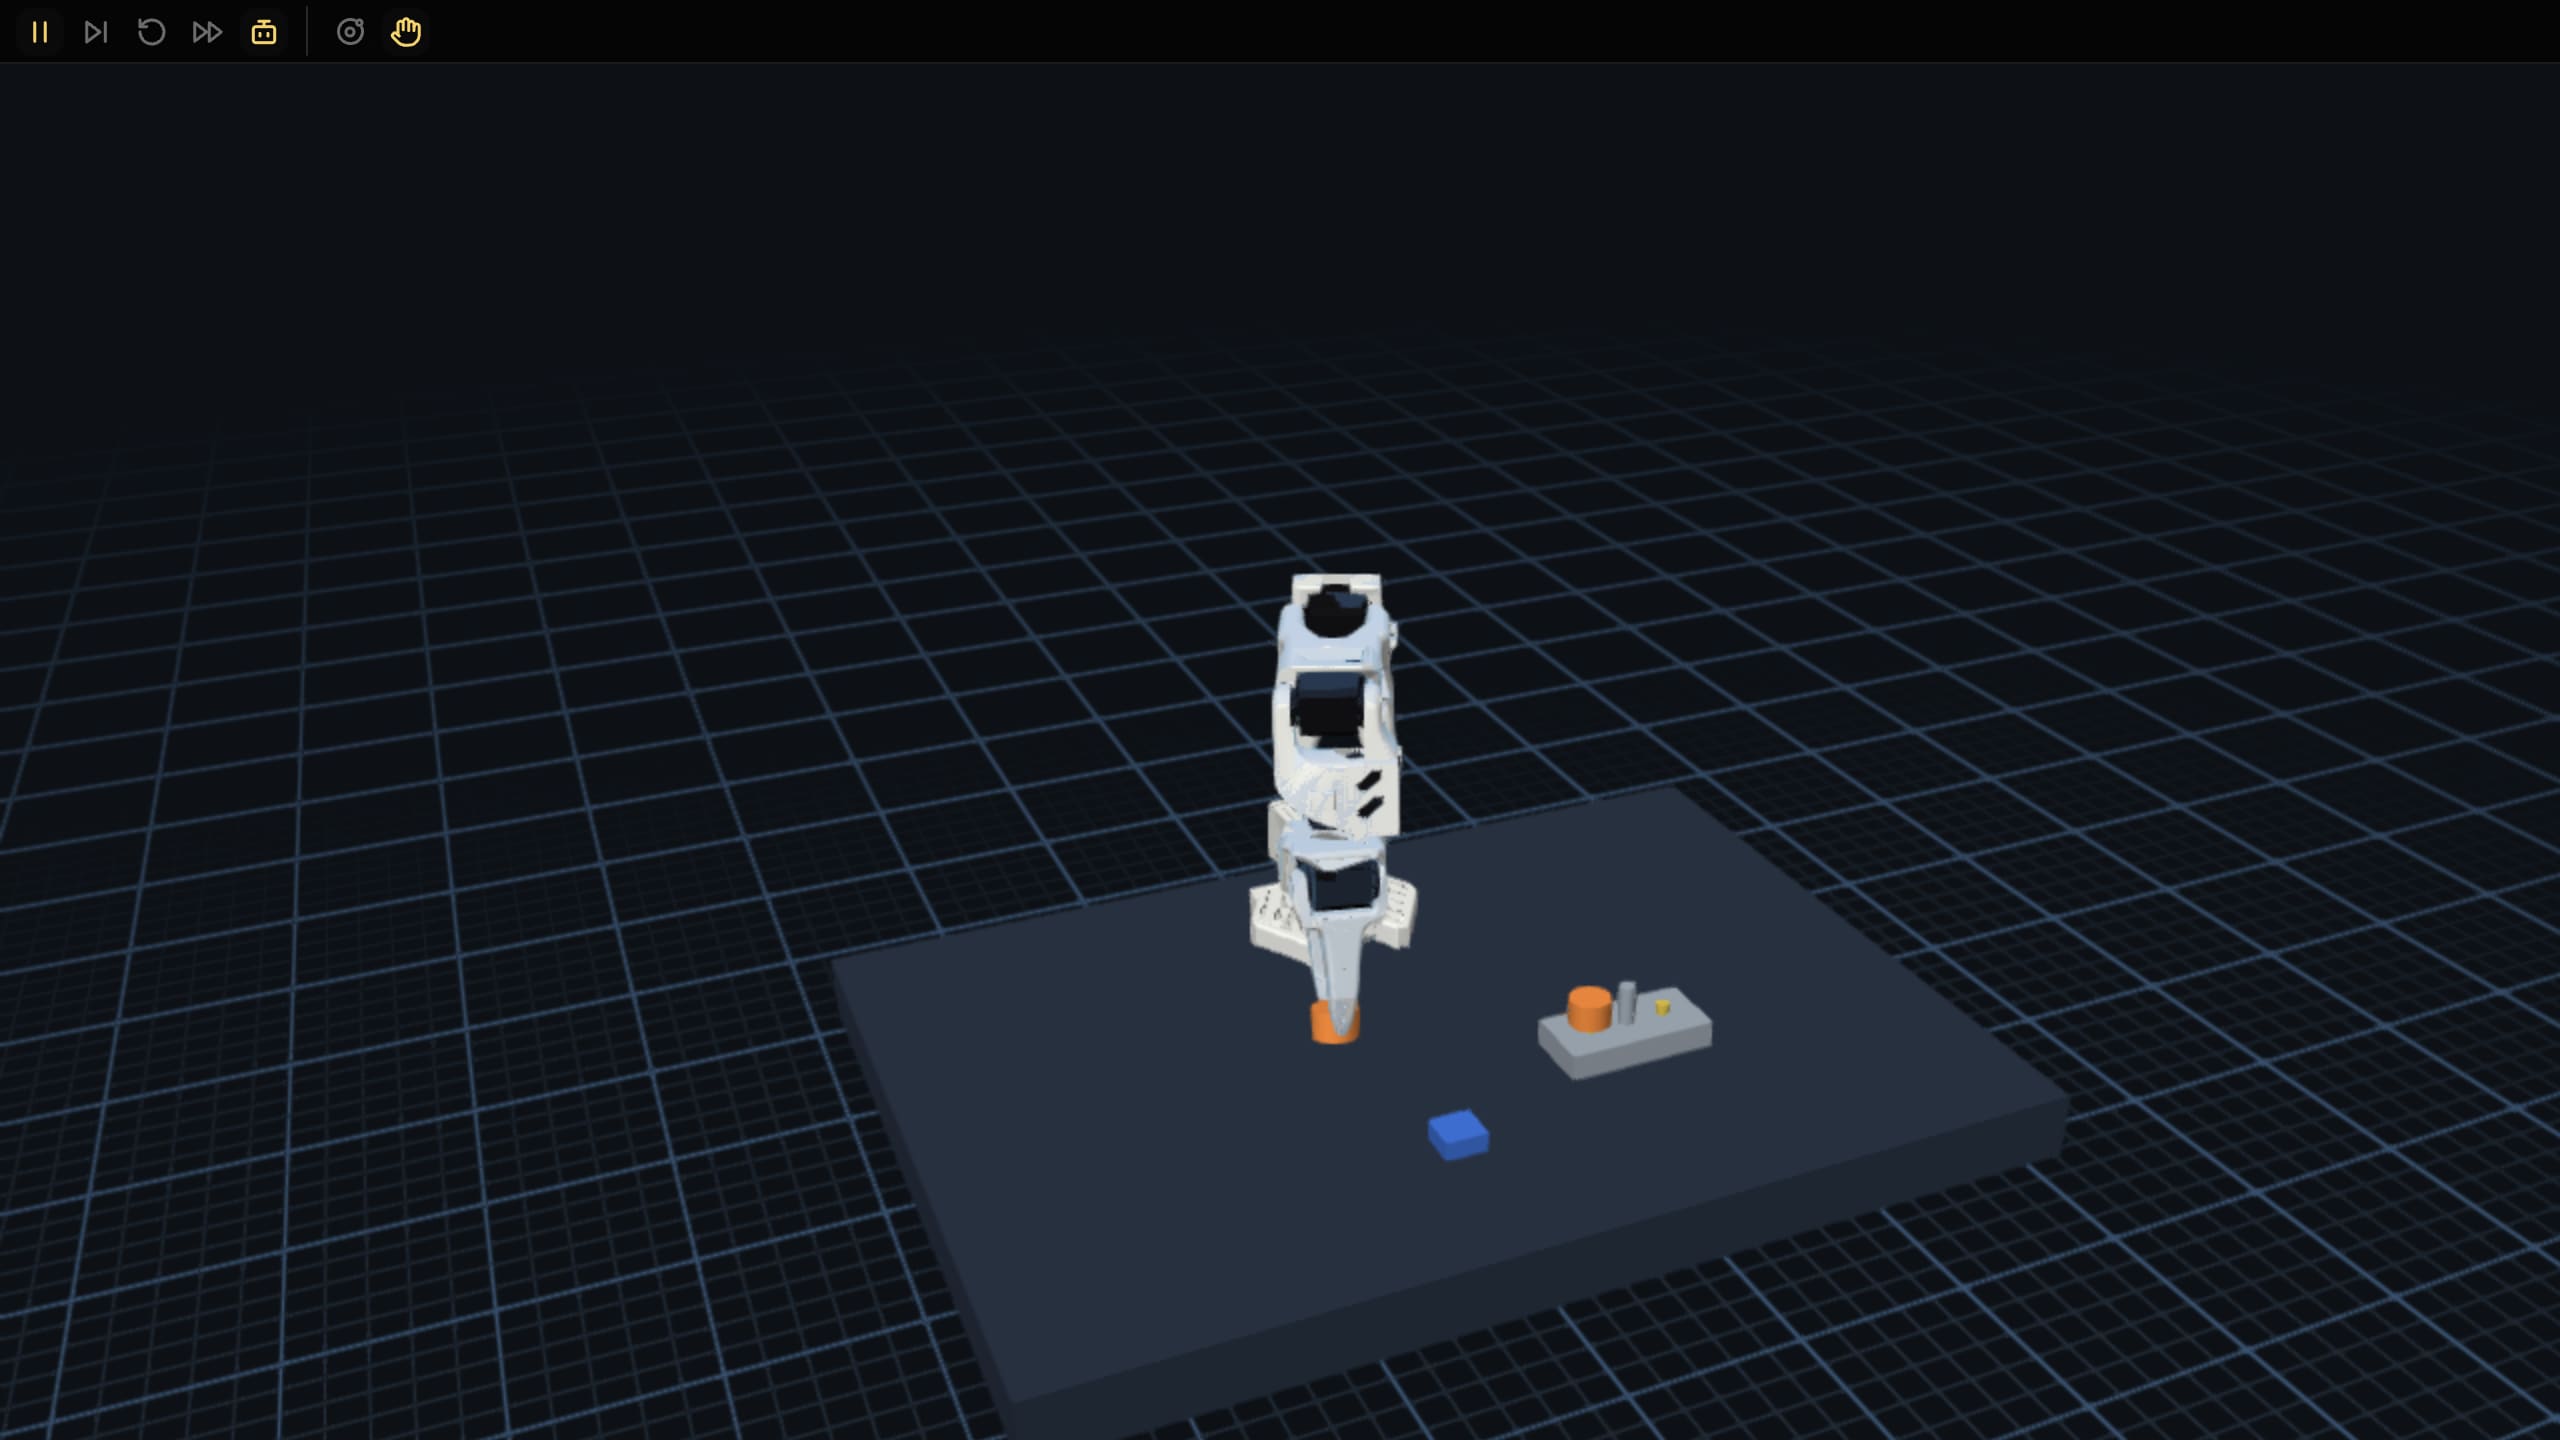
An SO-101 arm in a world with real physics, here in your browser. When it works there, it runs the real machine, and every command is on the record.

Tell it what to make.
Say it in a sentence. An agent opens a thread with your words and starts the work.
From one sentence to a robot on your desk.
You say what you want. It designs the arm, proves it in a world with real physics, then orders the parts, builds it and ships it to you.
Prompt
You say what you want, in one sentence.
Design
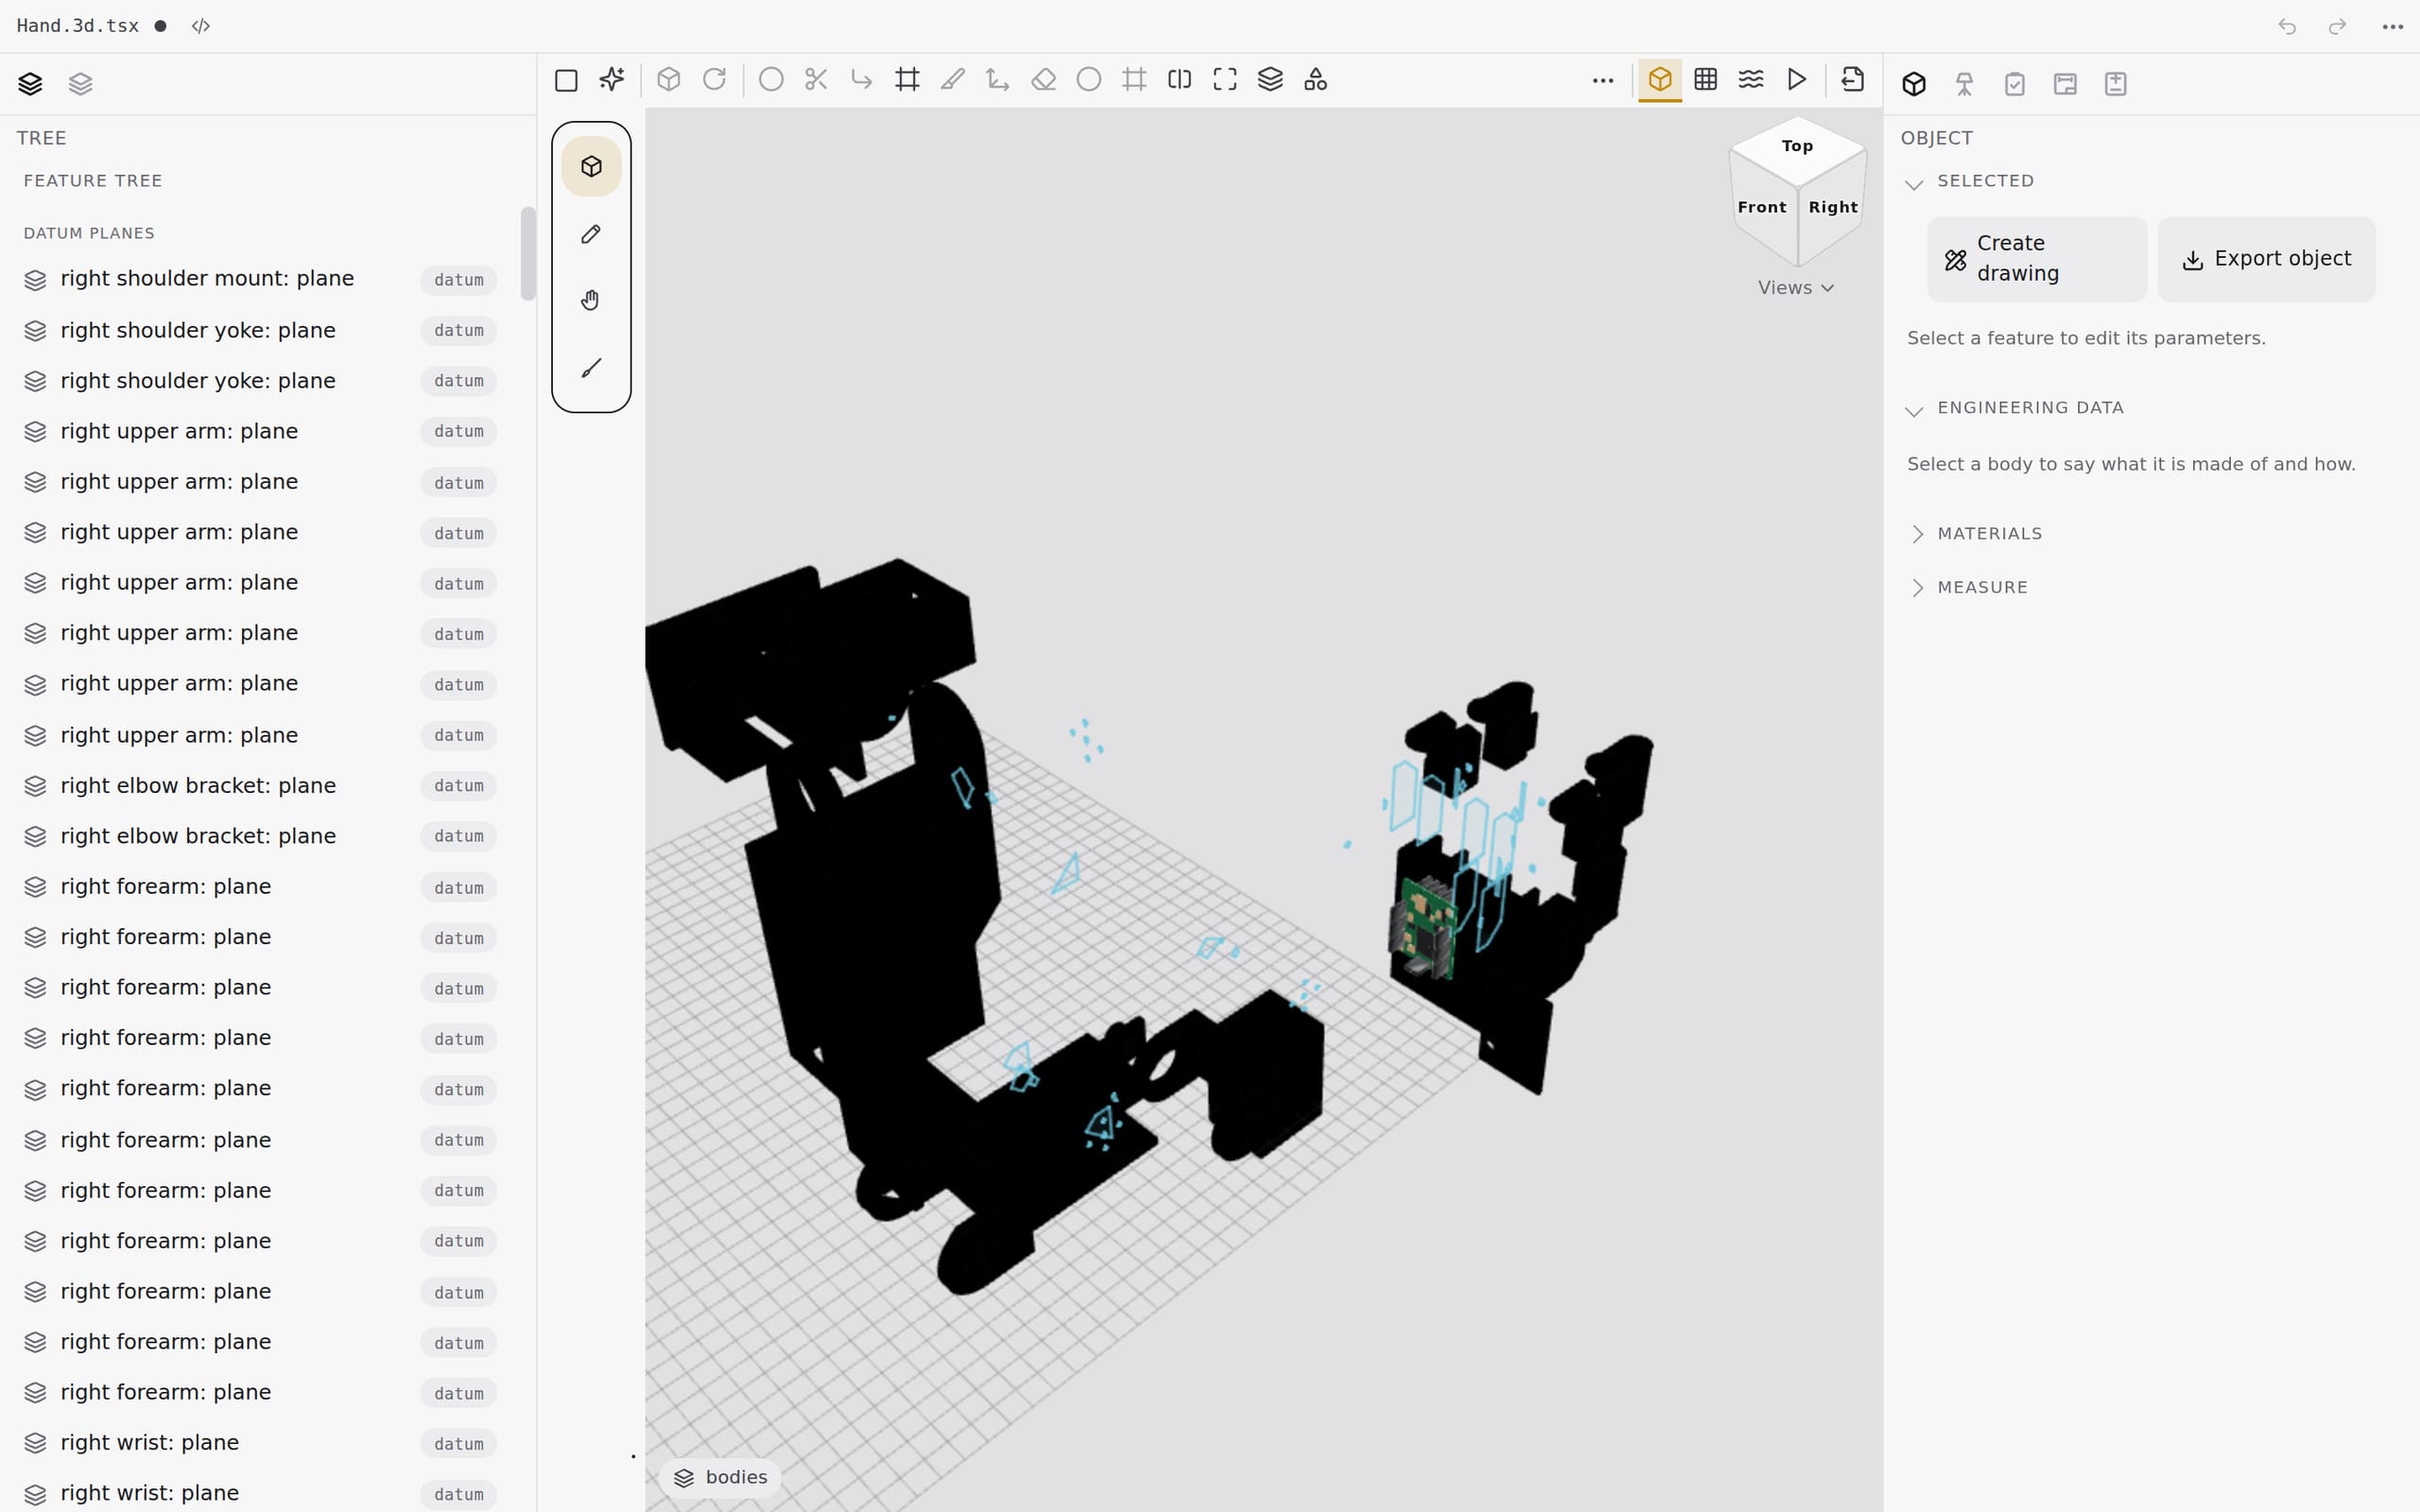
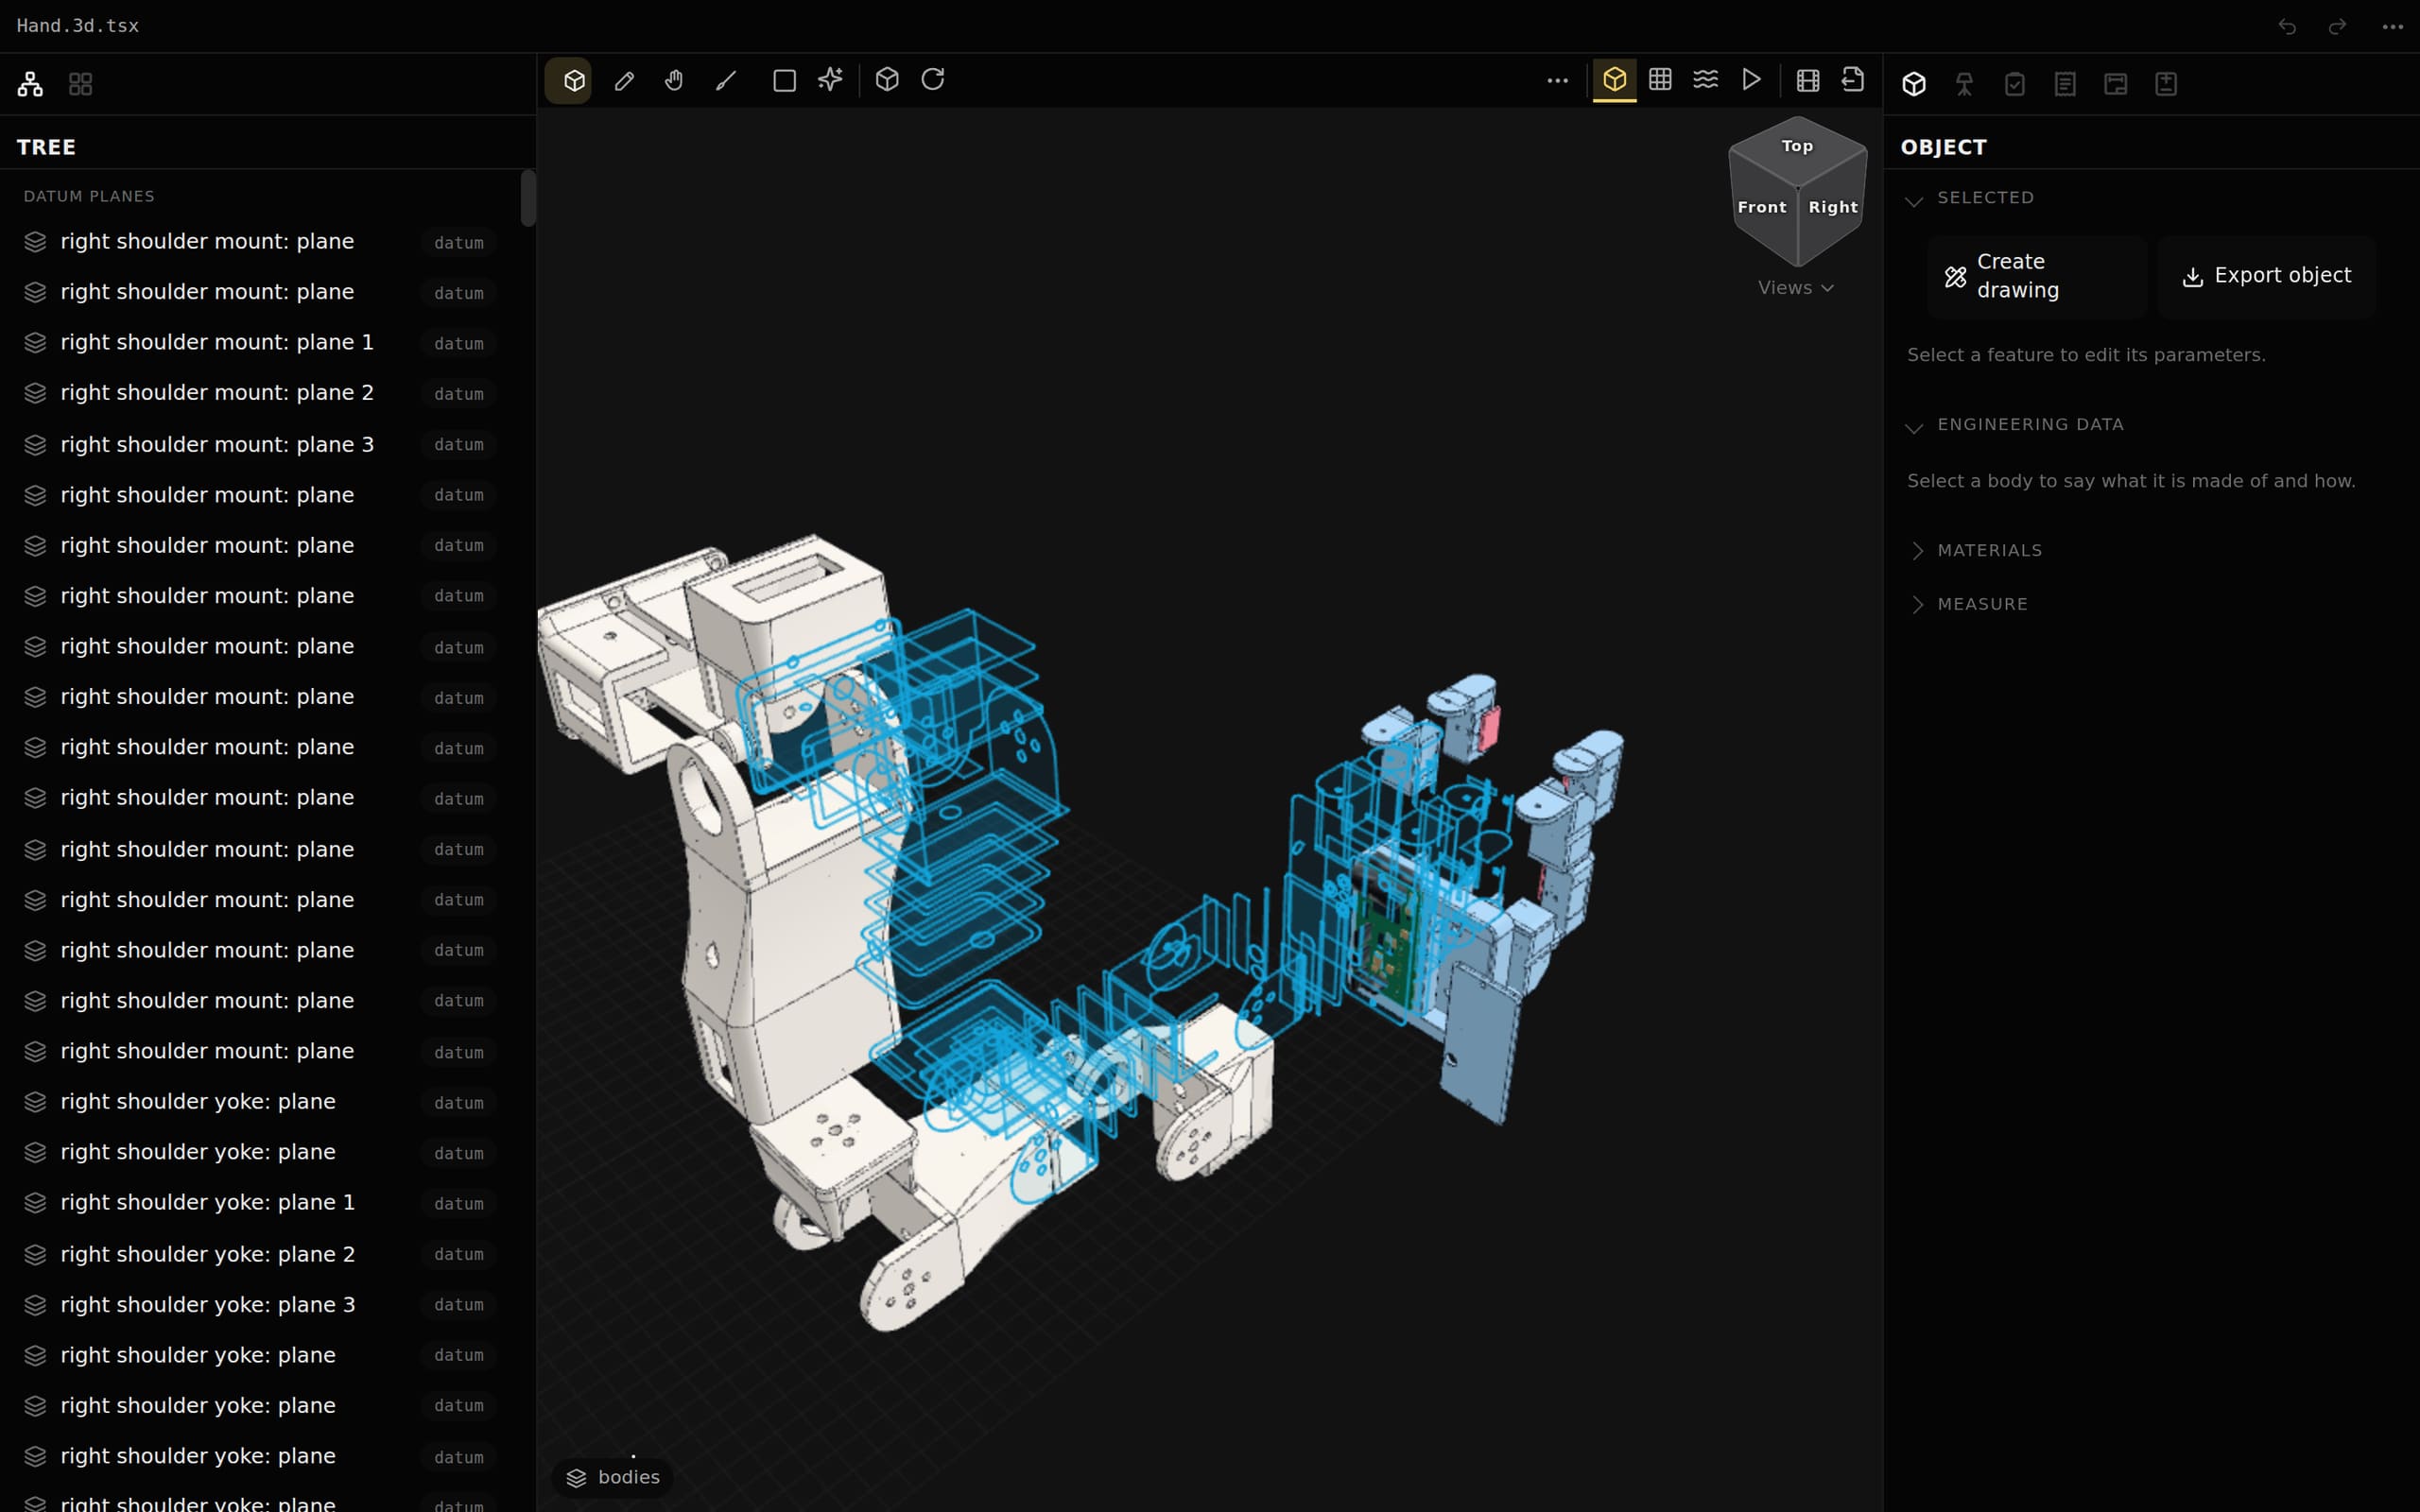
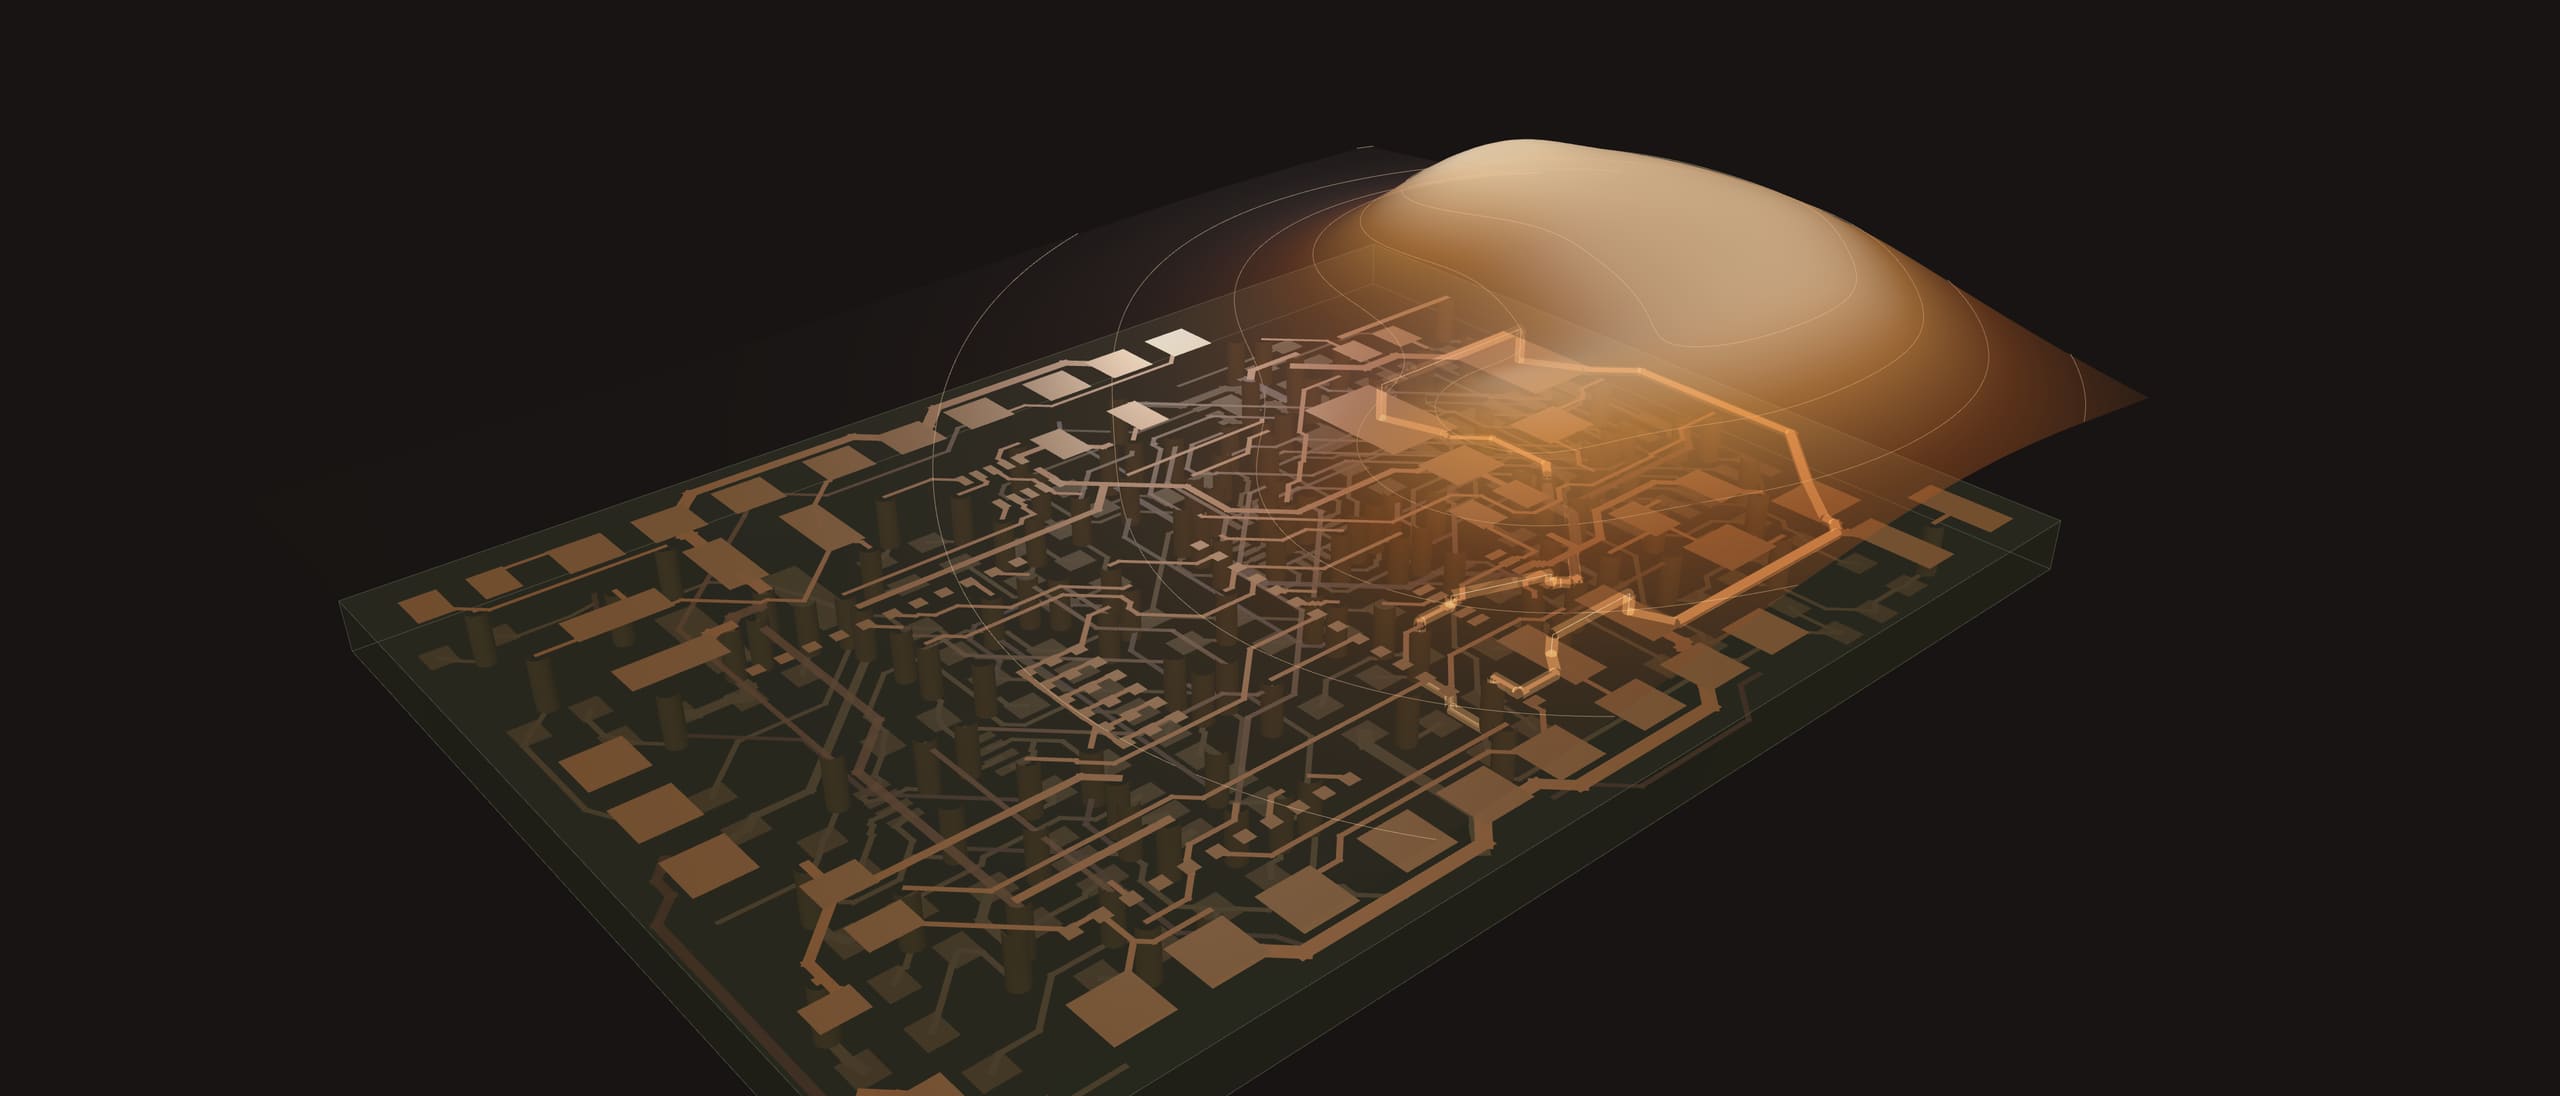
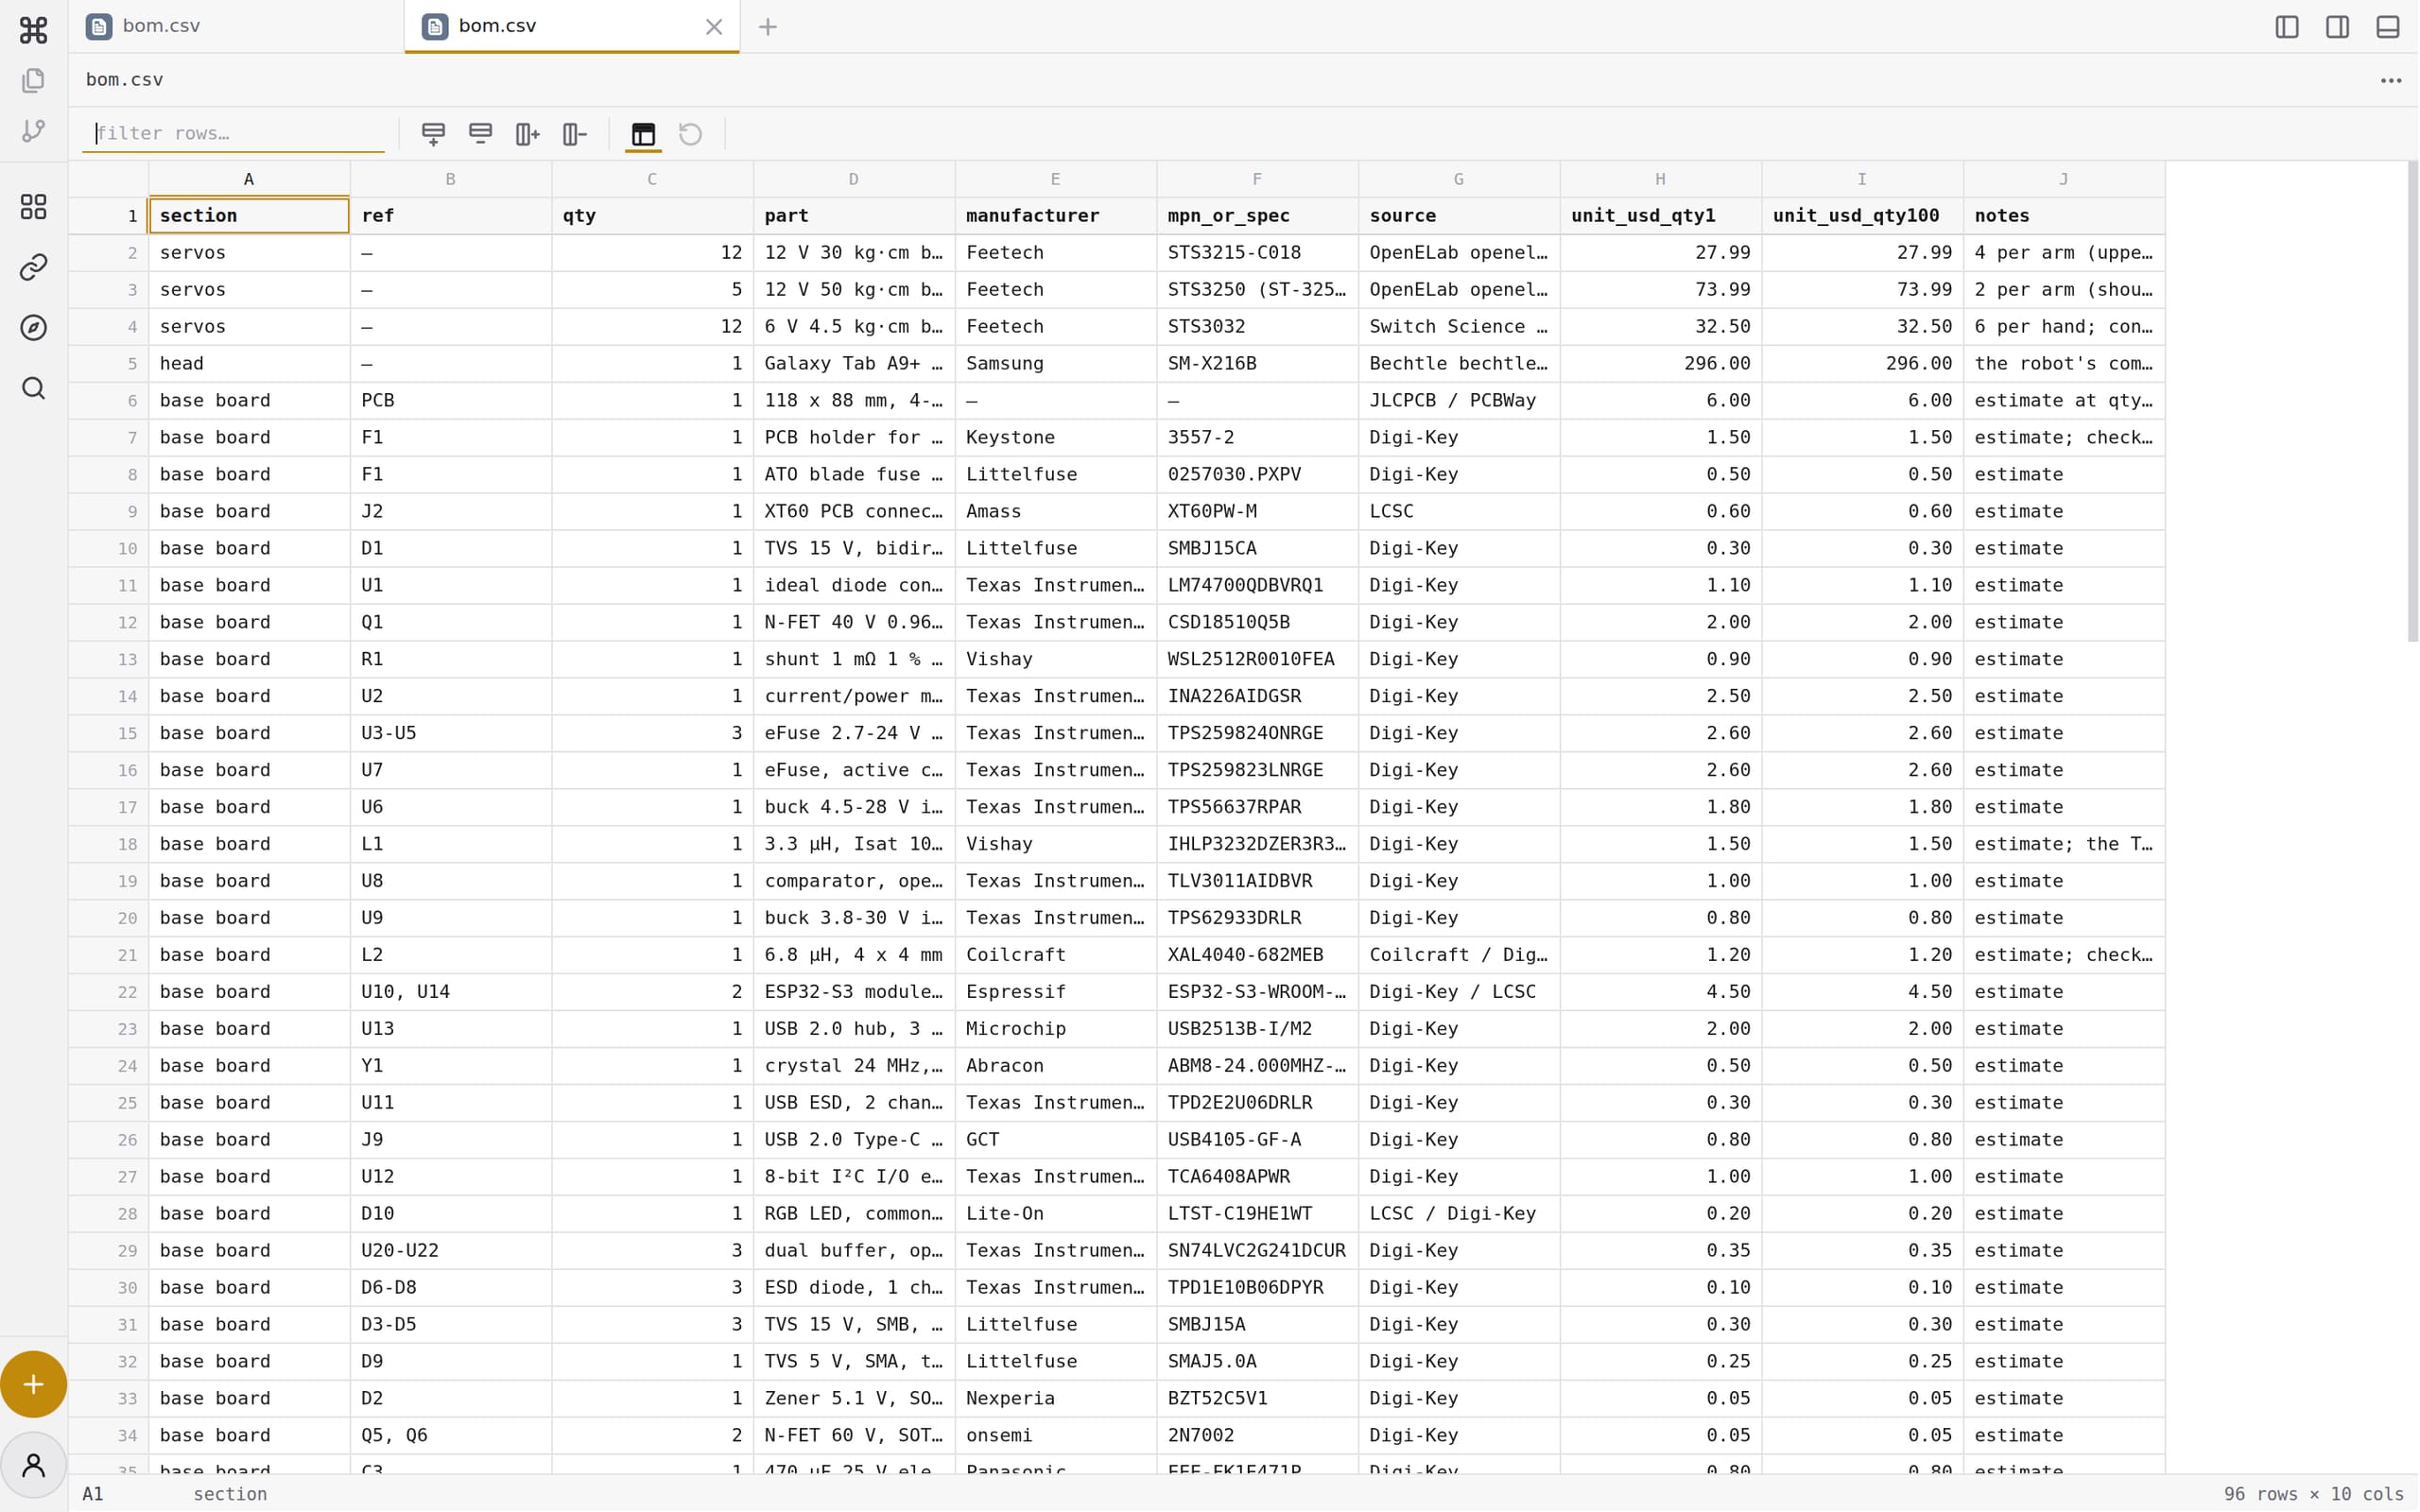
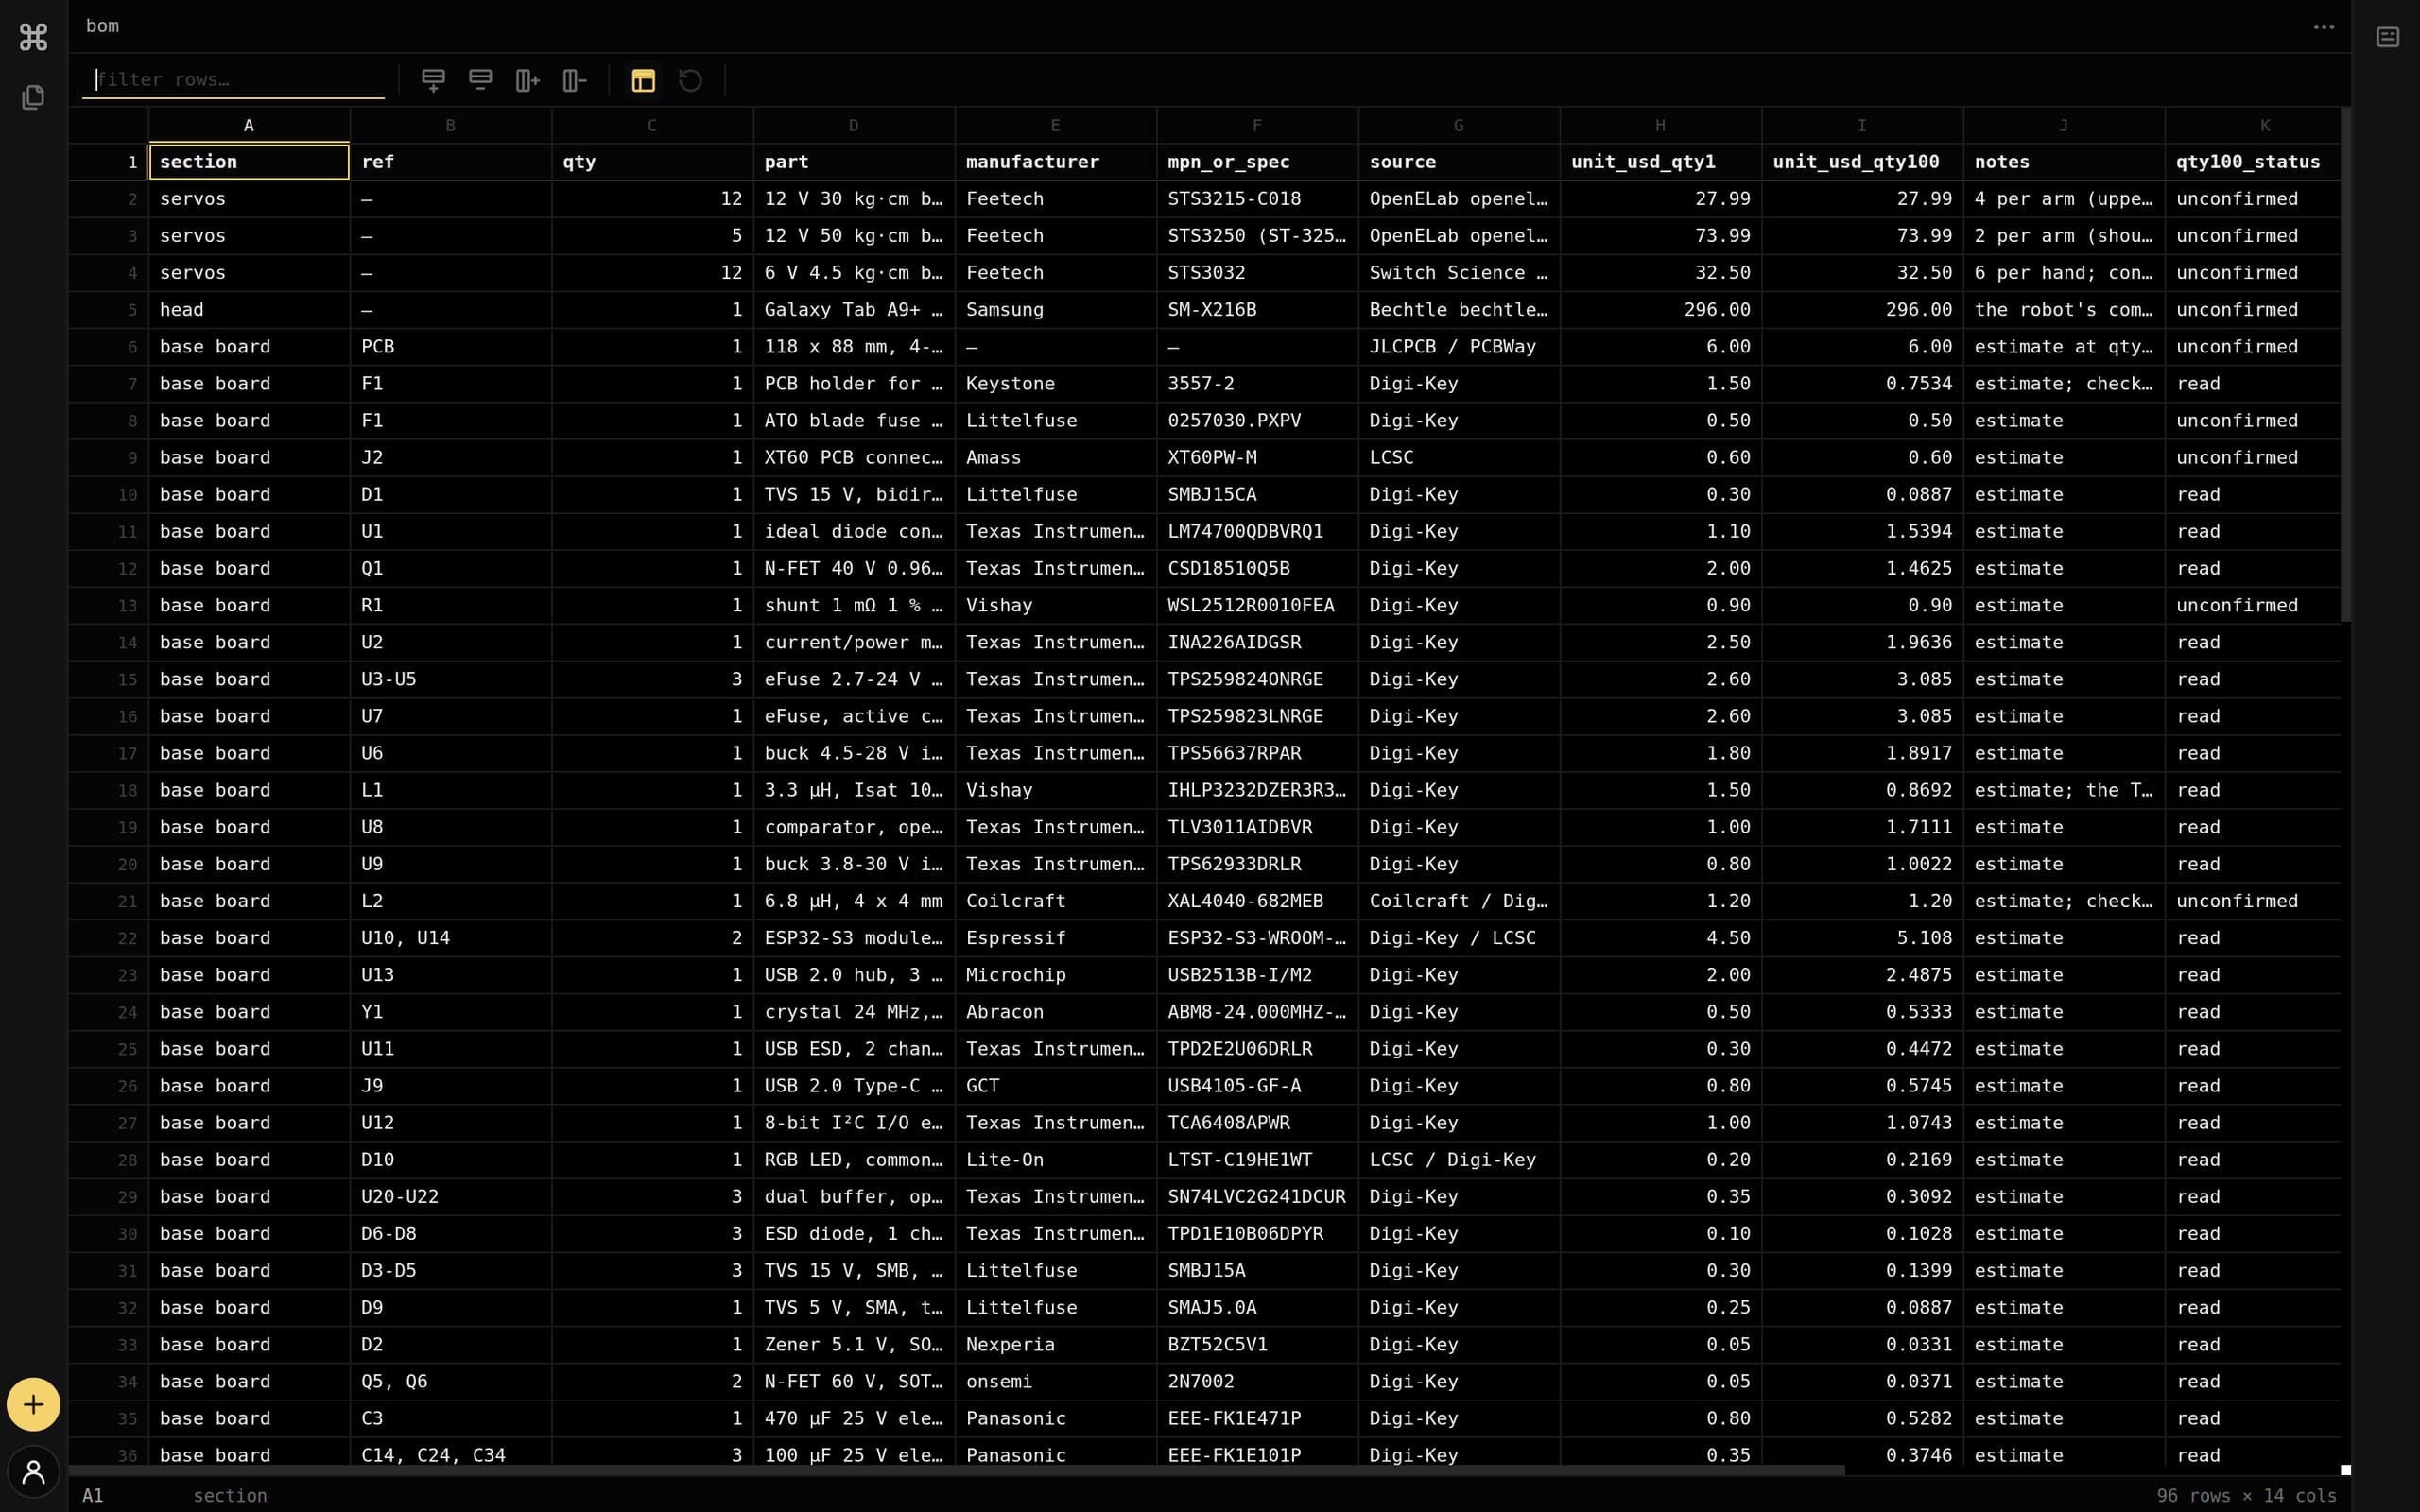
It designs the parts, the boards and the sourcing, and tests the robot in a world with real physics.
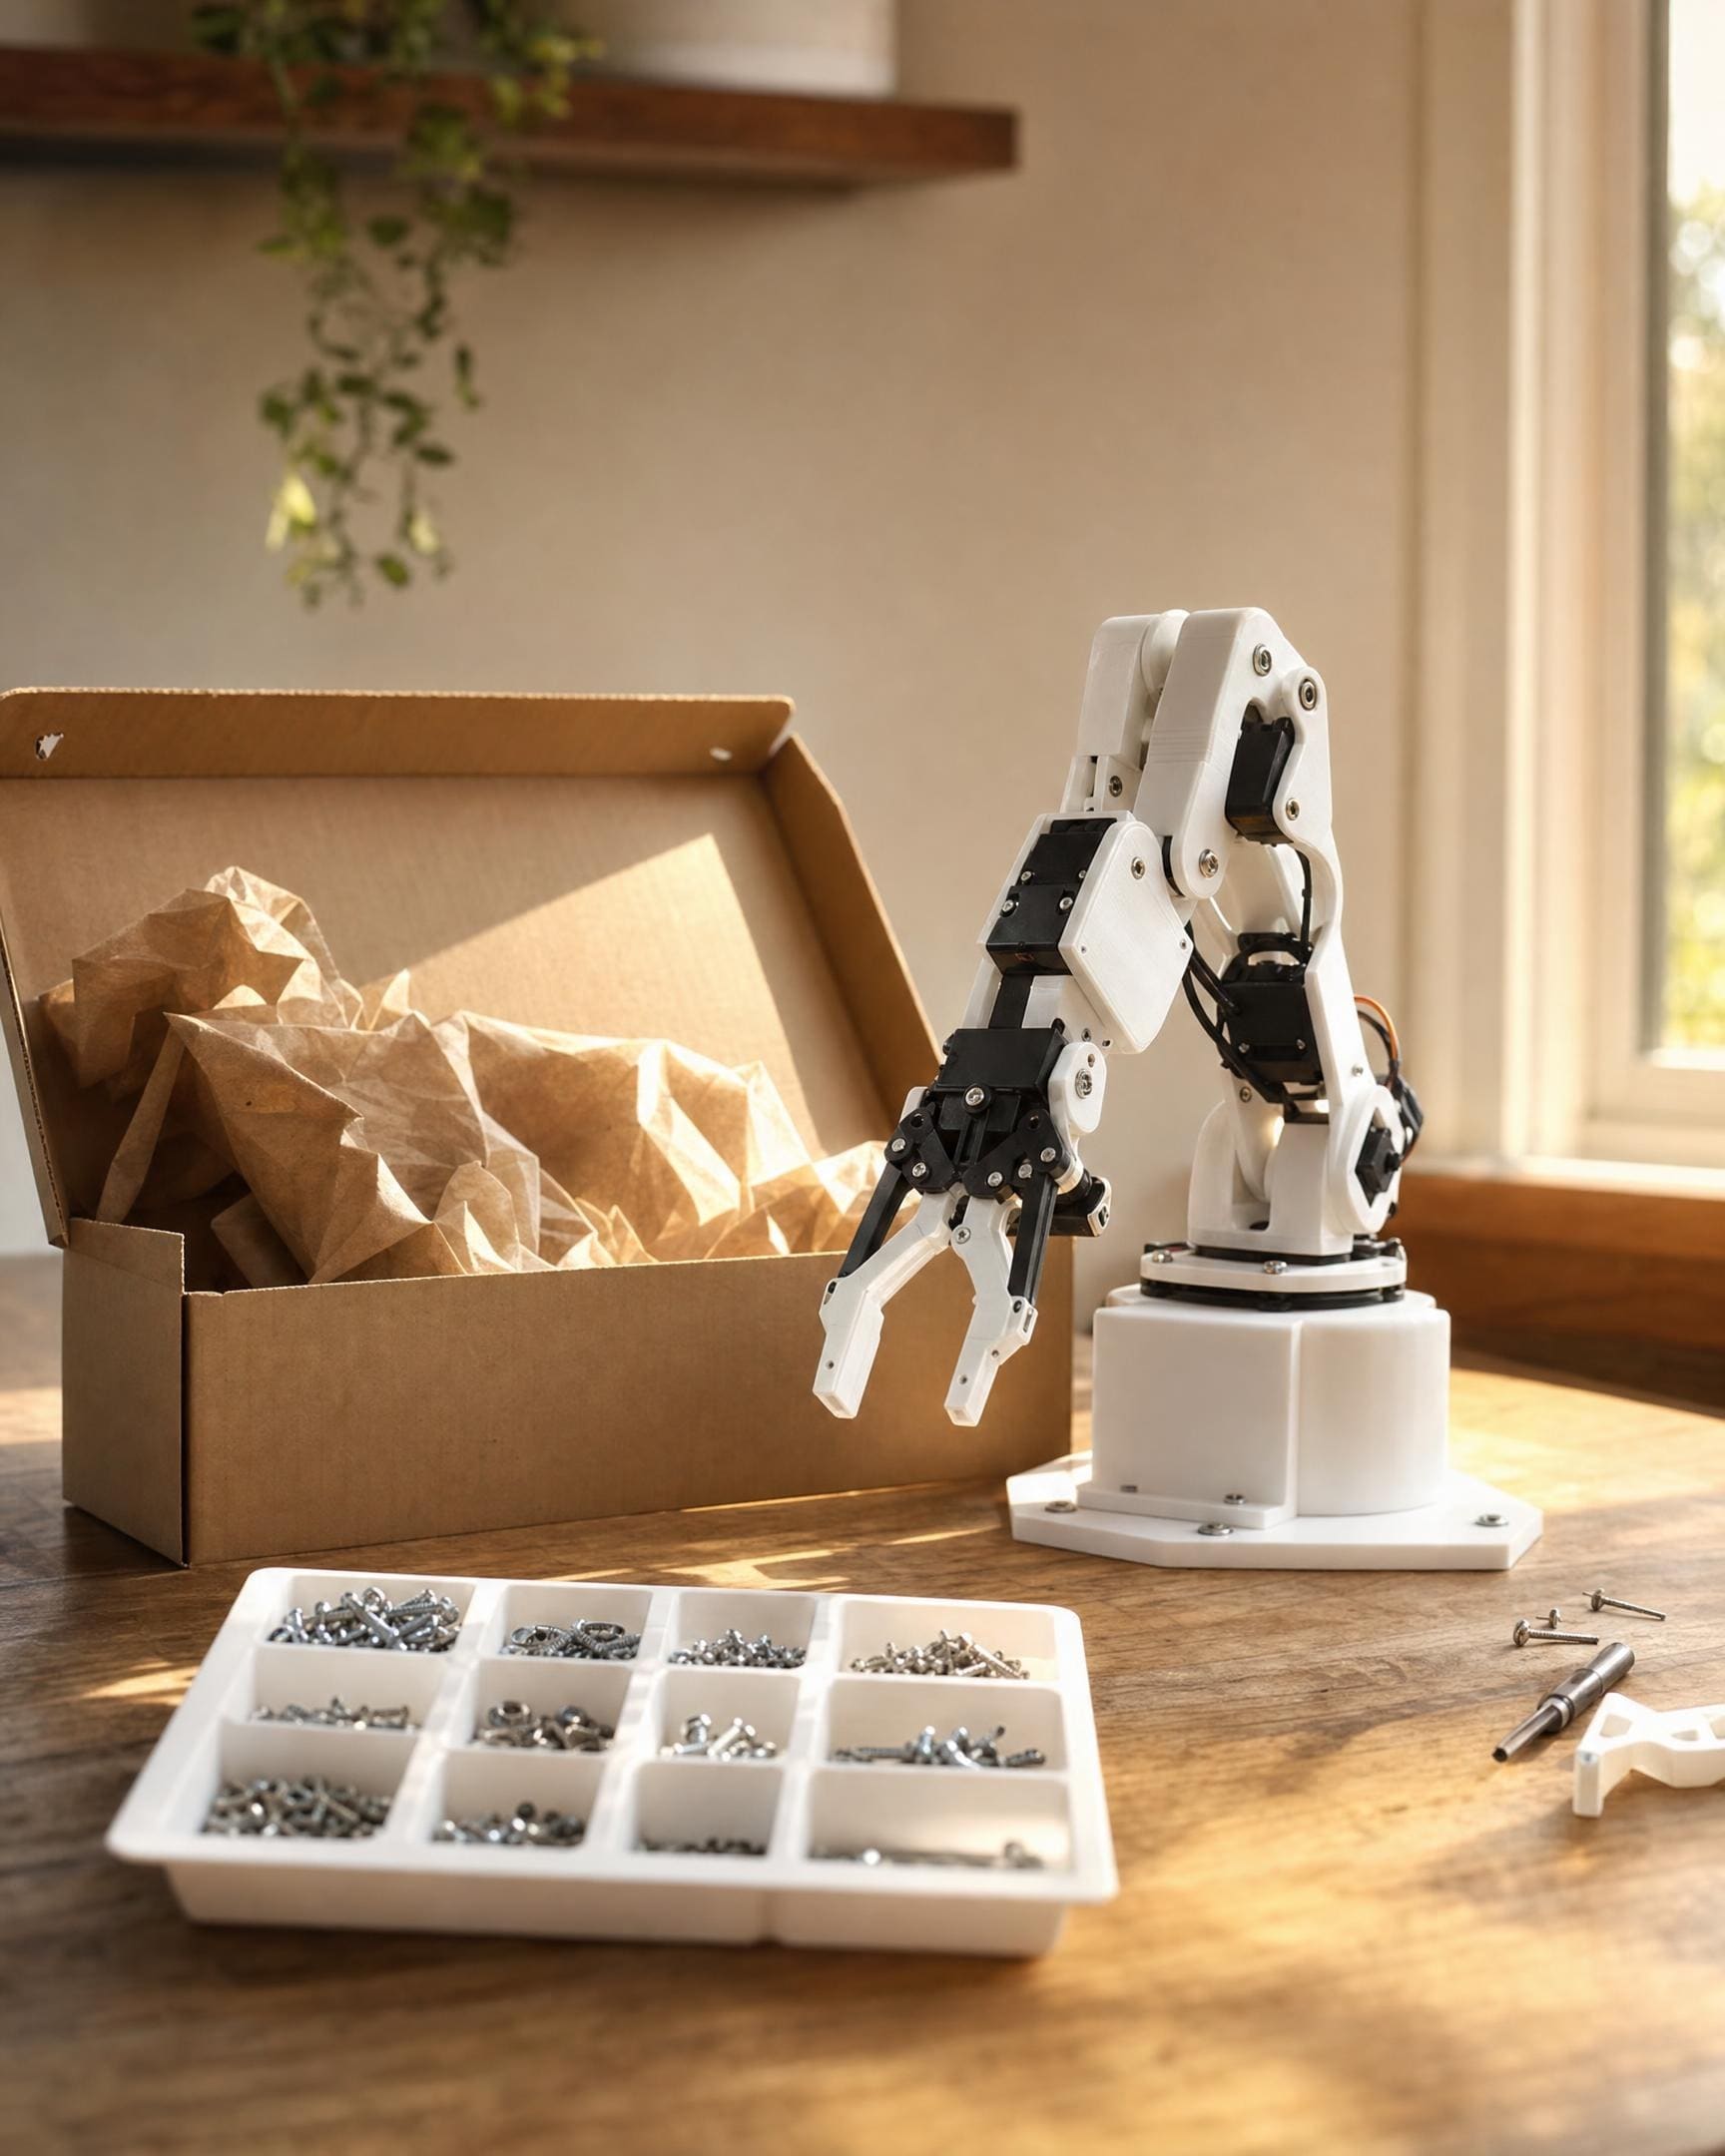
Delivered
It orders the parts, builds the robot and ships it to your door.


The same arm builds a pump.
Each part locks in only when it is let go within 6 mm of its place. When the rotors and the cap are in, the pump turns. Pull a part away and the arm goes back for it.

Put one on your desk.
The arm from these worlds, and three more machines. Built, tested and shipped. The policy that worked here drives it there.
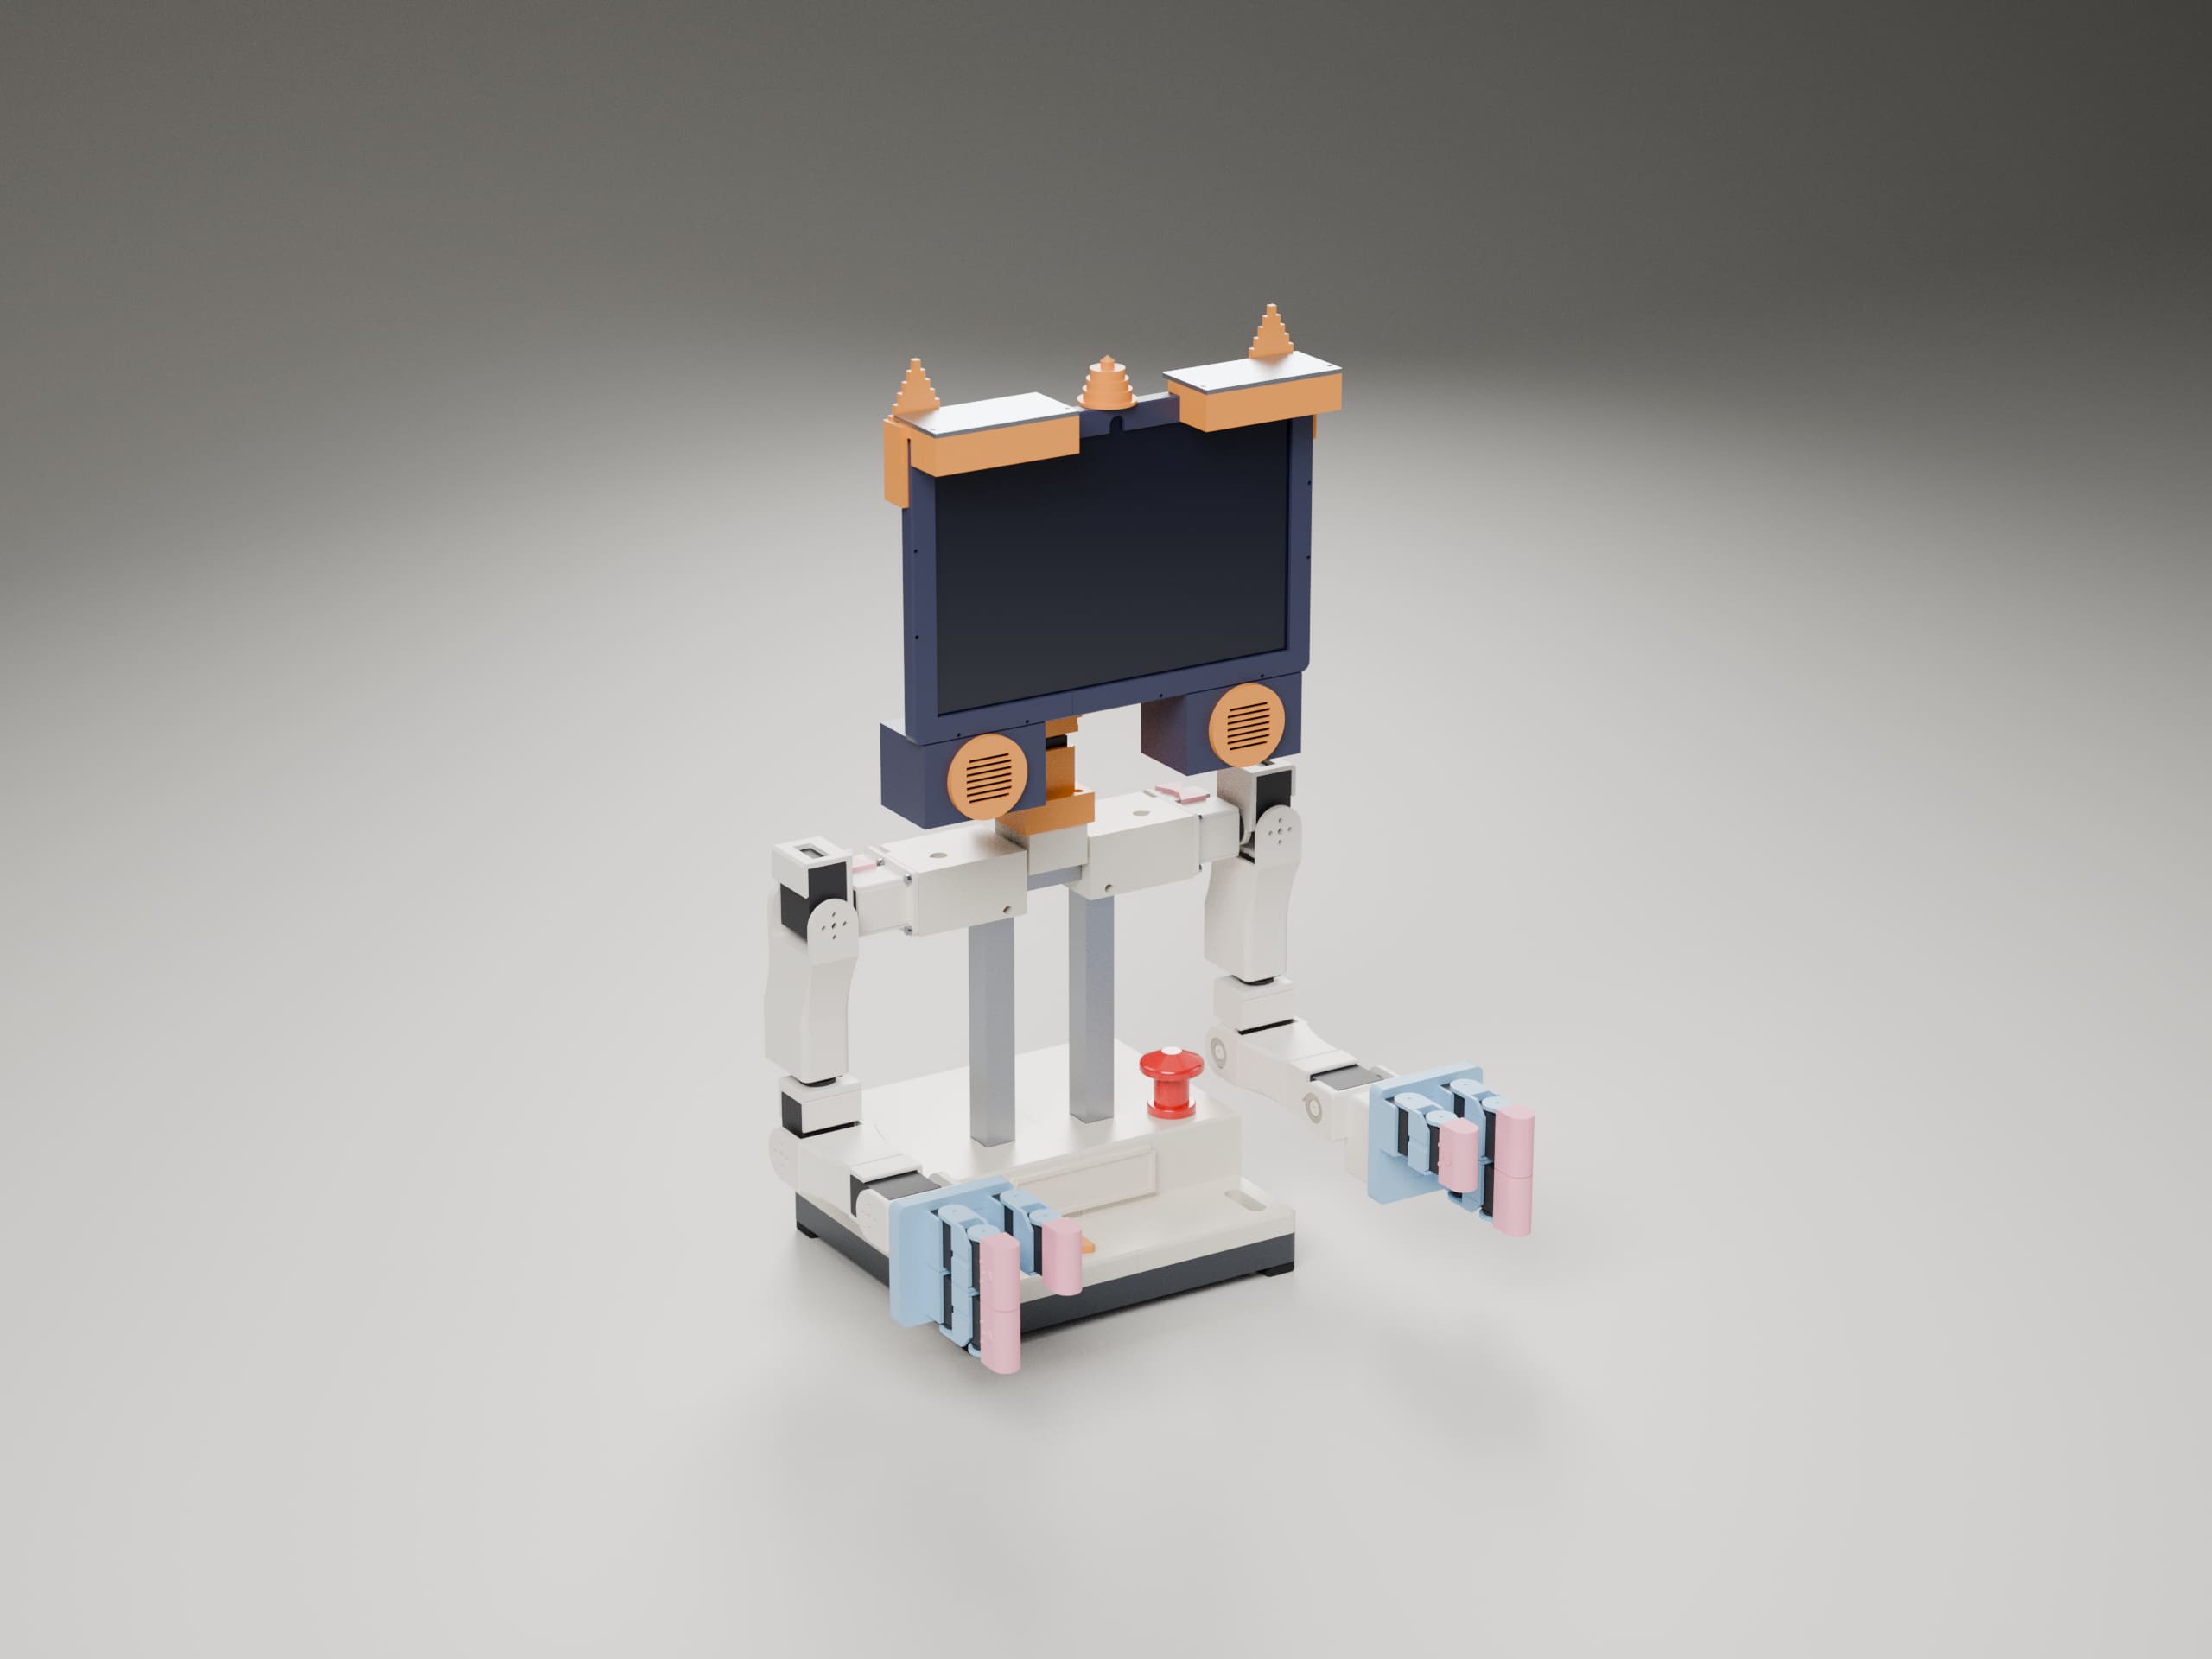
CommandAGI DeskAssistant-001
Two arms with hands, a 5-DoF neck, a tablet head and a lamp on a weighted desk base. Ships assembled in 2–3 weeks.
$3,496
Buy · $3,496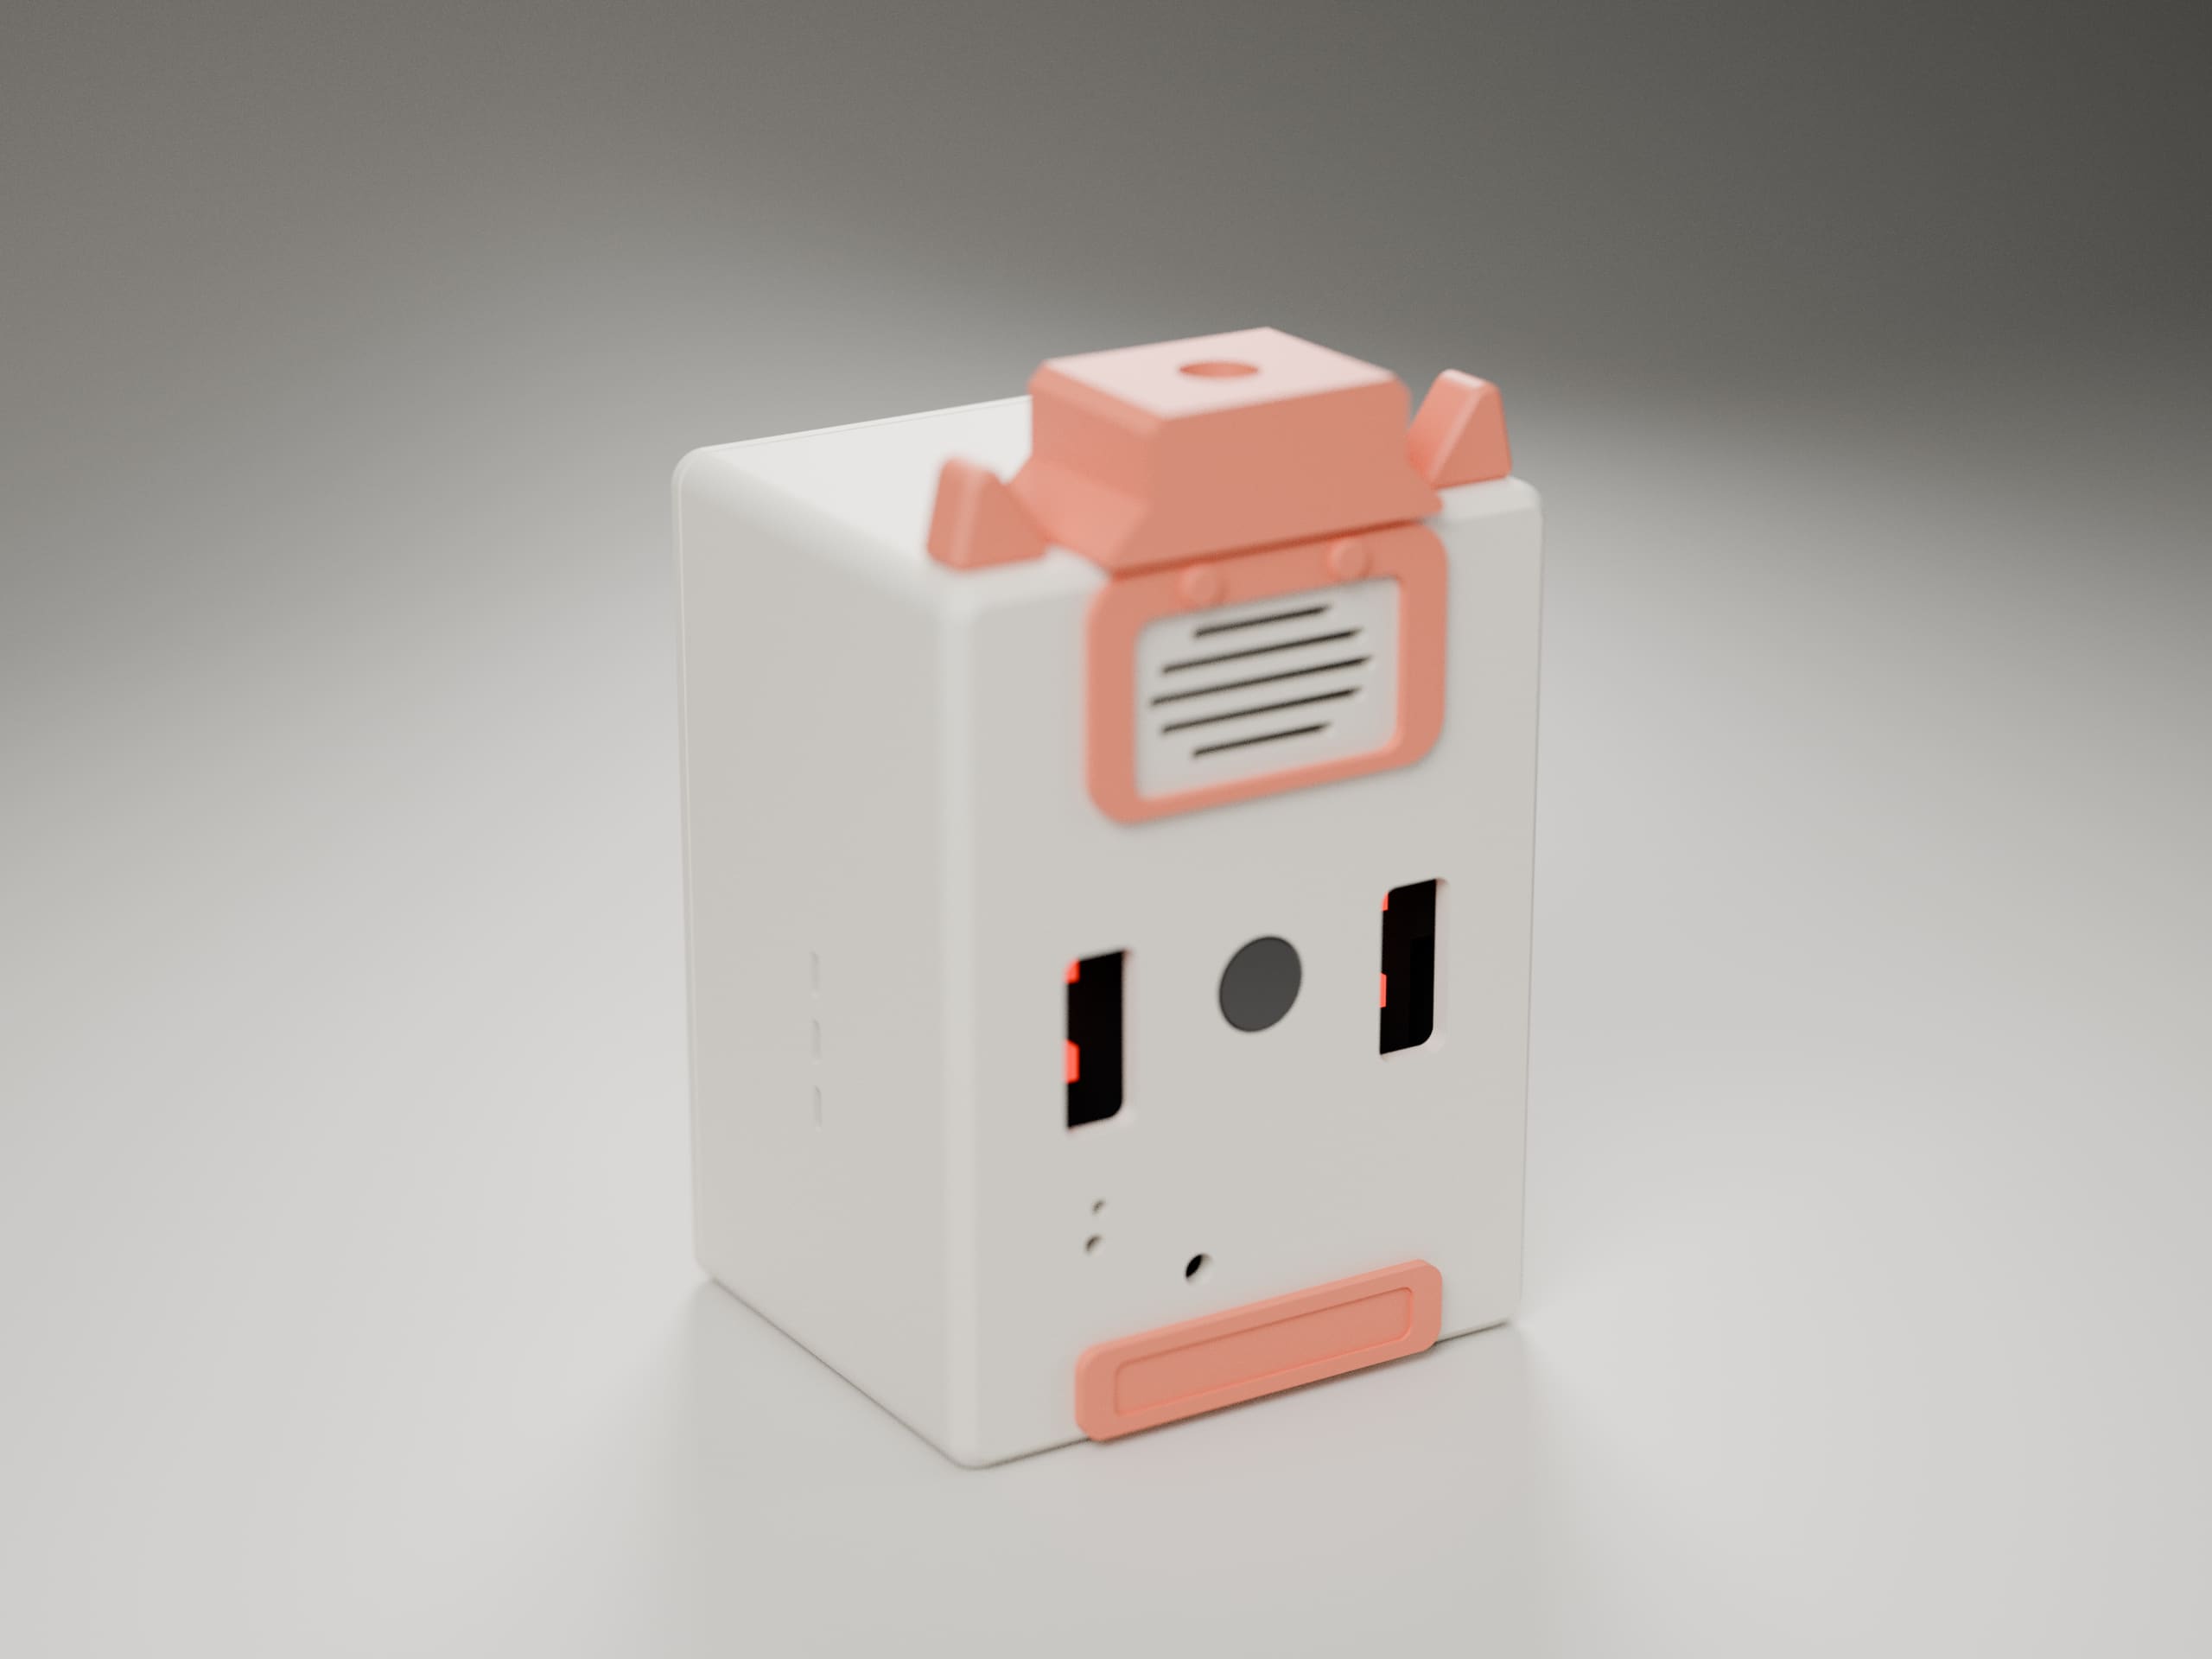
CommandAGI Cam-002
A wide-angle camera with mic, speaker and LTE, on a battery; it runs while it charges. Ships assembled in 2–3 weeks.
$298
Buy · $298
Exocortex
A soft stretch-knit cap that records your brain's activity and your day to your own computer. S/M/L. $5,000 plus tax; $250 refundable deposit; first units expected by December 2027.
$5,000
Pre-order · $5,000
Computatrum
A desktop agent that uses your own computer while you watch. It asks before it sends, deletes or buys. Linux, macOS and Windows.
Free
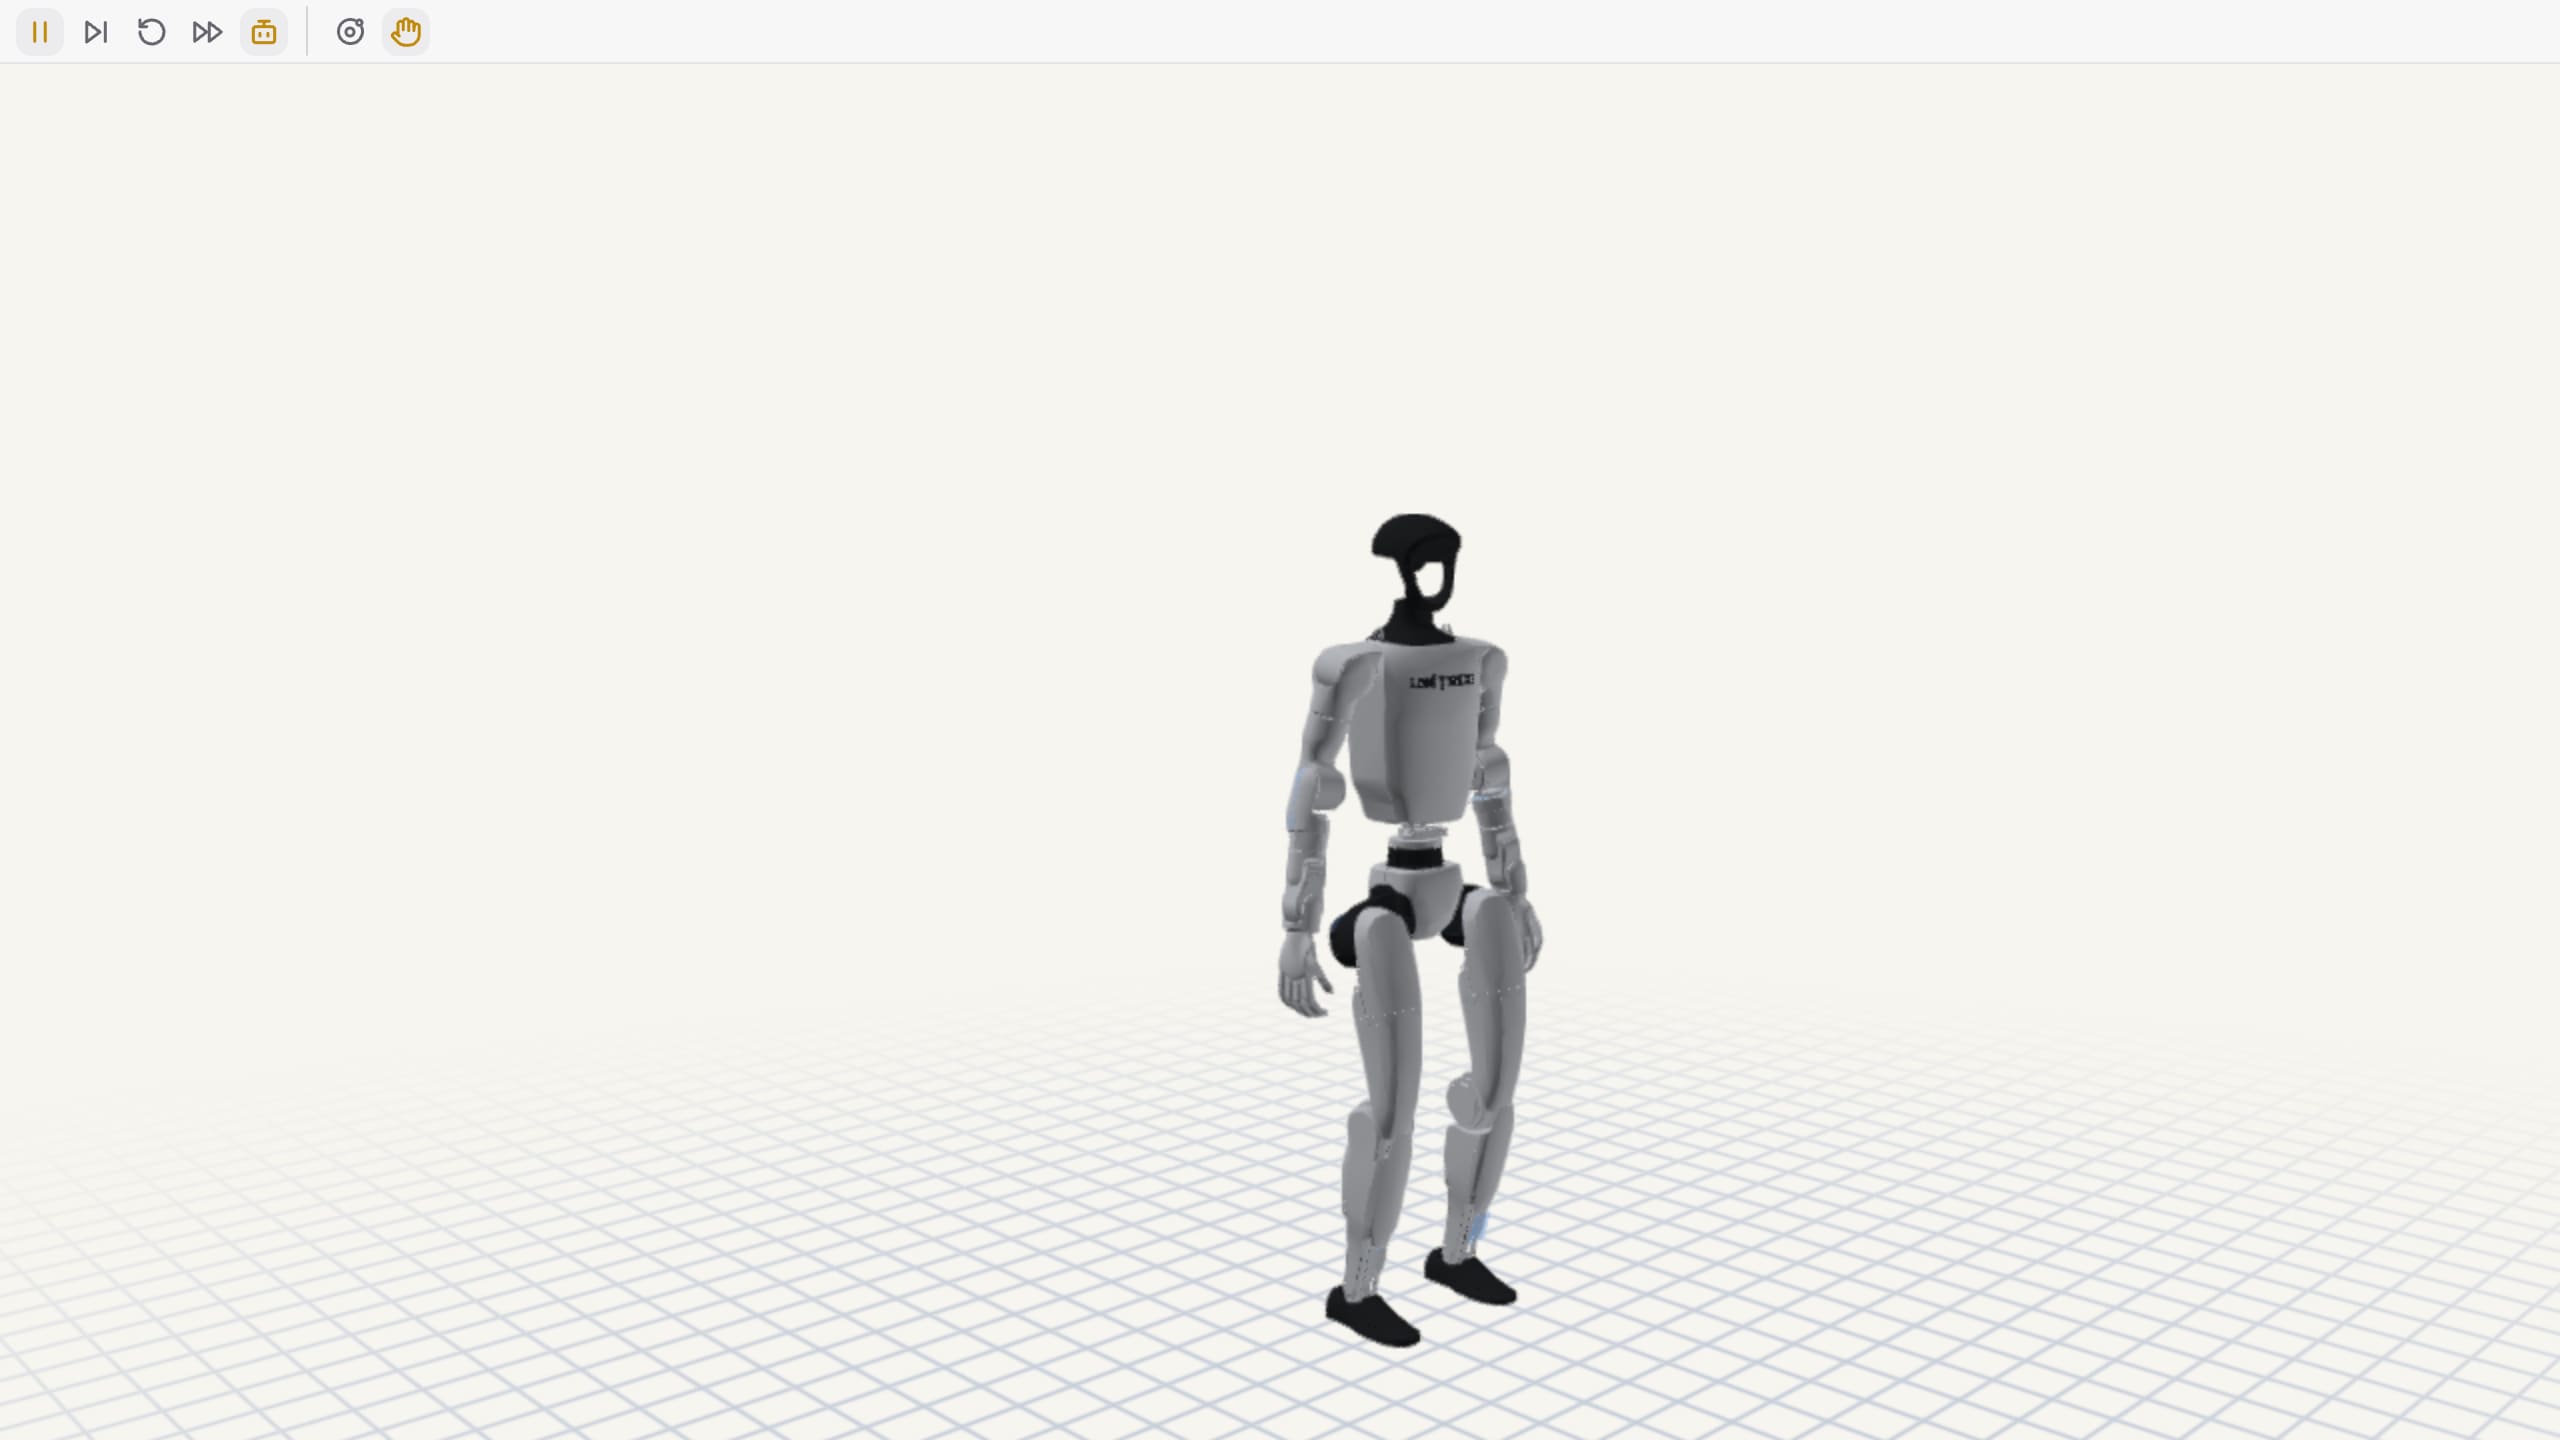
Get it · FreeA Unitree G1 hops and lands.
Unitree's own model: 1.32 m and 33 kg, with the masses and joint ranges of its MJCF. Push it while it lands. It catches itself, or it falls.

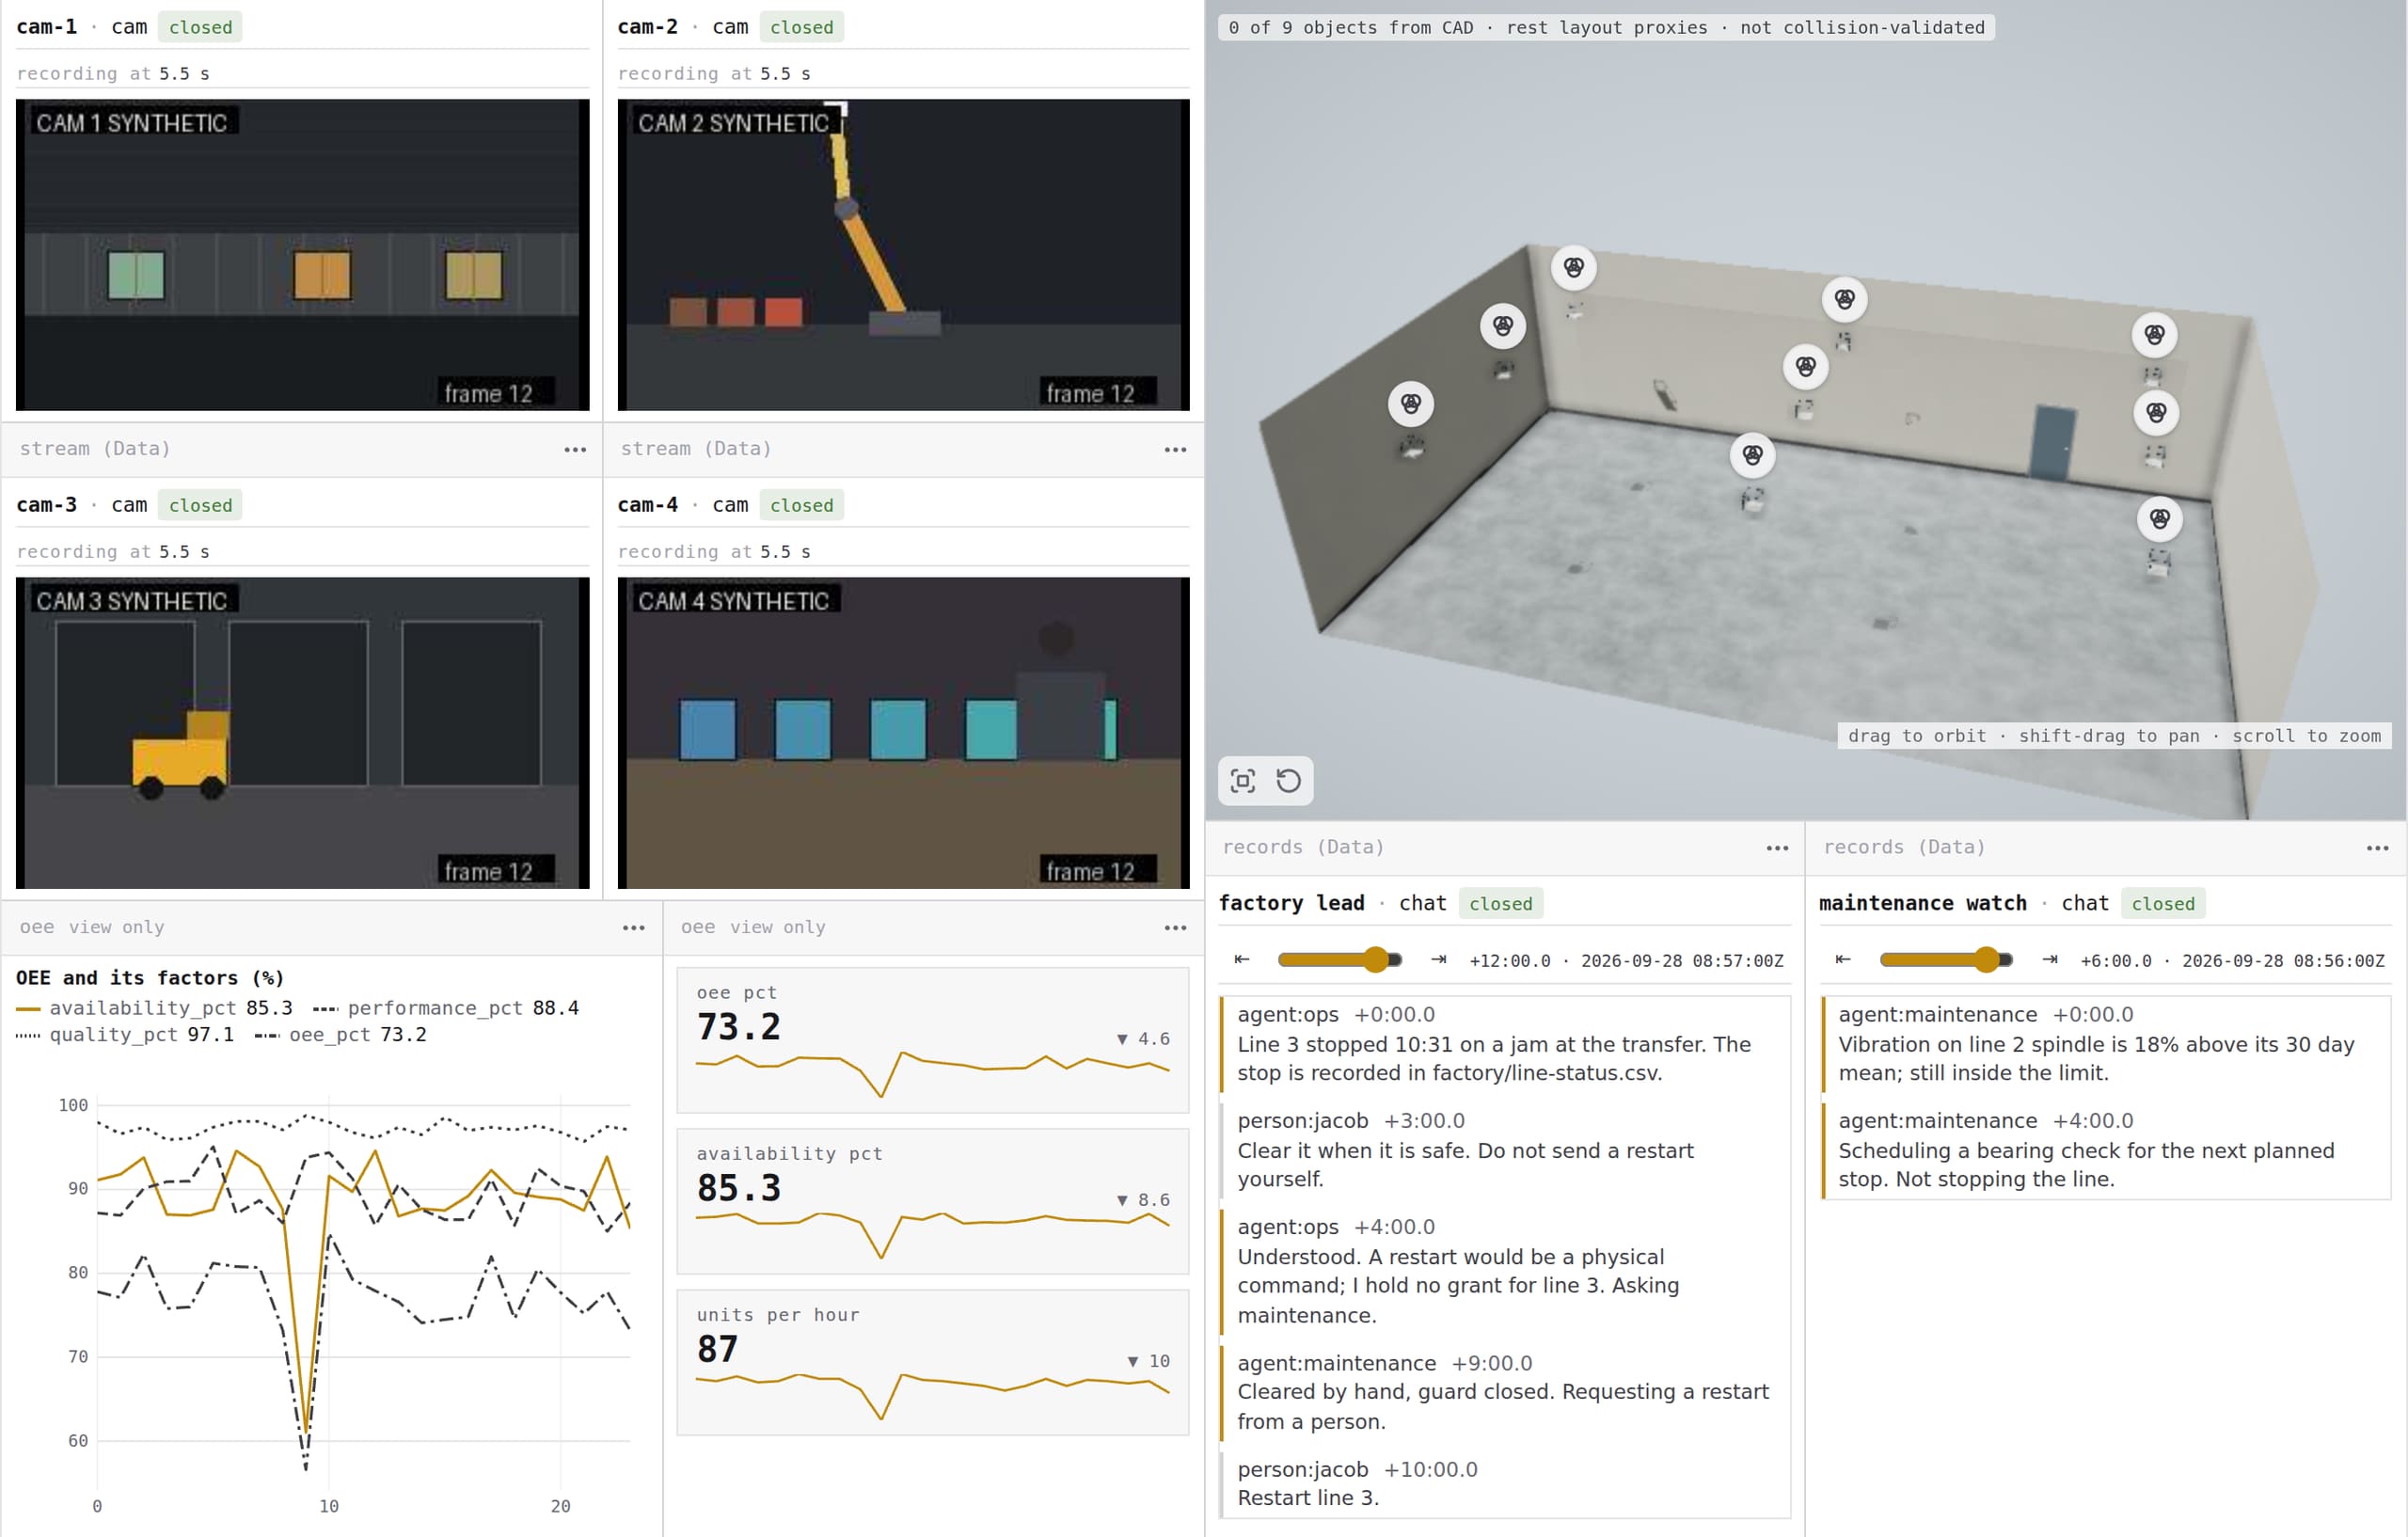
Every command is on the record.
The policy and your hand write to one stream, each line with who gave it.
00:00:03.750 command agent:policy-mover: ctrl shoulder_pan=-0.71 shoulder_lift=0.28 elbow_flex=0.64
00:00:04.020 command person:ana: grab cube
00:00:04.053 command person:ana: drag cube to (-0.05, -0.10, 0.78)
00:00:04.450 command agent:policy-mover: ctrl shoulder_pan=-0.48 shoulder_lift=0.33 elbow_flex=0.59
Every turn of the loop compounds.
The outer loop builds the machine. The inner loop trains its policy on its own runs. One record closes both.
Design
.3d.tsx · world.tsx
The part, the robot and its world, in code.
Make
CAM · printer · mill
Toolpaths from the design. The printer and the mill run them.
Assemble
Parts → a robot
Printed parts, servos and a board become the arm.
Test
Bench · twin
A run records every command before it is sent, with reality: physical | simulation.
Data
Sealed frames
Seals and device-sealed camera frames: the inspection record, tied to the design and the machine settings.
The policy loop
Act
SO-101
The policy moves the arm.
Fine-tune
Best runs first
The runs that passed weigh most.
Loops within loops. Data closes both, and physical and simulated evidence never mix.
One recorded loop of , in simulation. Its record
0%80%40 of 50 cubes it never saw, after 6 generations
generation
passed did not
generation
generation 0 generation 6
- Success0% → 80%
- Time to place10.5 s → 9.3 s
- Tool into the bench0.58 mm → 1.87 mm
- Feedback score−0.7 → +1.7
An SO-101 arm in the shipped pick-and-place world, in simulation. Every number is read from the loop's record.
Your Claude writes the code. CommandAGI gives it a world.
- Physics at 240 steps a second, with real robot models: the SO-101, and the Unitree G1 from Unitree's own MJCF.
- Drivers for the Feetech and Dynamixel servo buses: plug the arm into USB and drive it from the browser.
- Every command recorded before it is sent, and a grant it cannot widen.
- Files you can read. A world is
world.tsx; Claude edits it like any code. - The GitHub for how a thing was made: every command and every run in files you can diff, physical and simulated kept apart.
# add CommandAGI to Claude Code
claude mcp add --transport http commandagi \
  https://api.commandagi.com/mcp \
  --header "Authorization: Bearer cagi_YOUR_KEY"

# then ask
claude "Make a world where an SO-101 arm stacks two cubes"
Start in a world. Finish on your desk.
Open a world with an arm and drag it. No hardware needed. When it works, order the arm, or plug in your own: SO-100/101, Koch and WidowX connect from the browser.