Skip to content
CommandAGI · commandagi.com/demos
See it happen.
Real work, start to finish. What someone wanted, what we did, and what came of it. A simulation says it is one.
Software
- Wanted
- A long list of software tasks, finished without watching every step.
- What we did
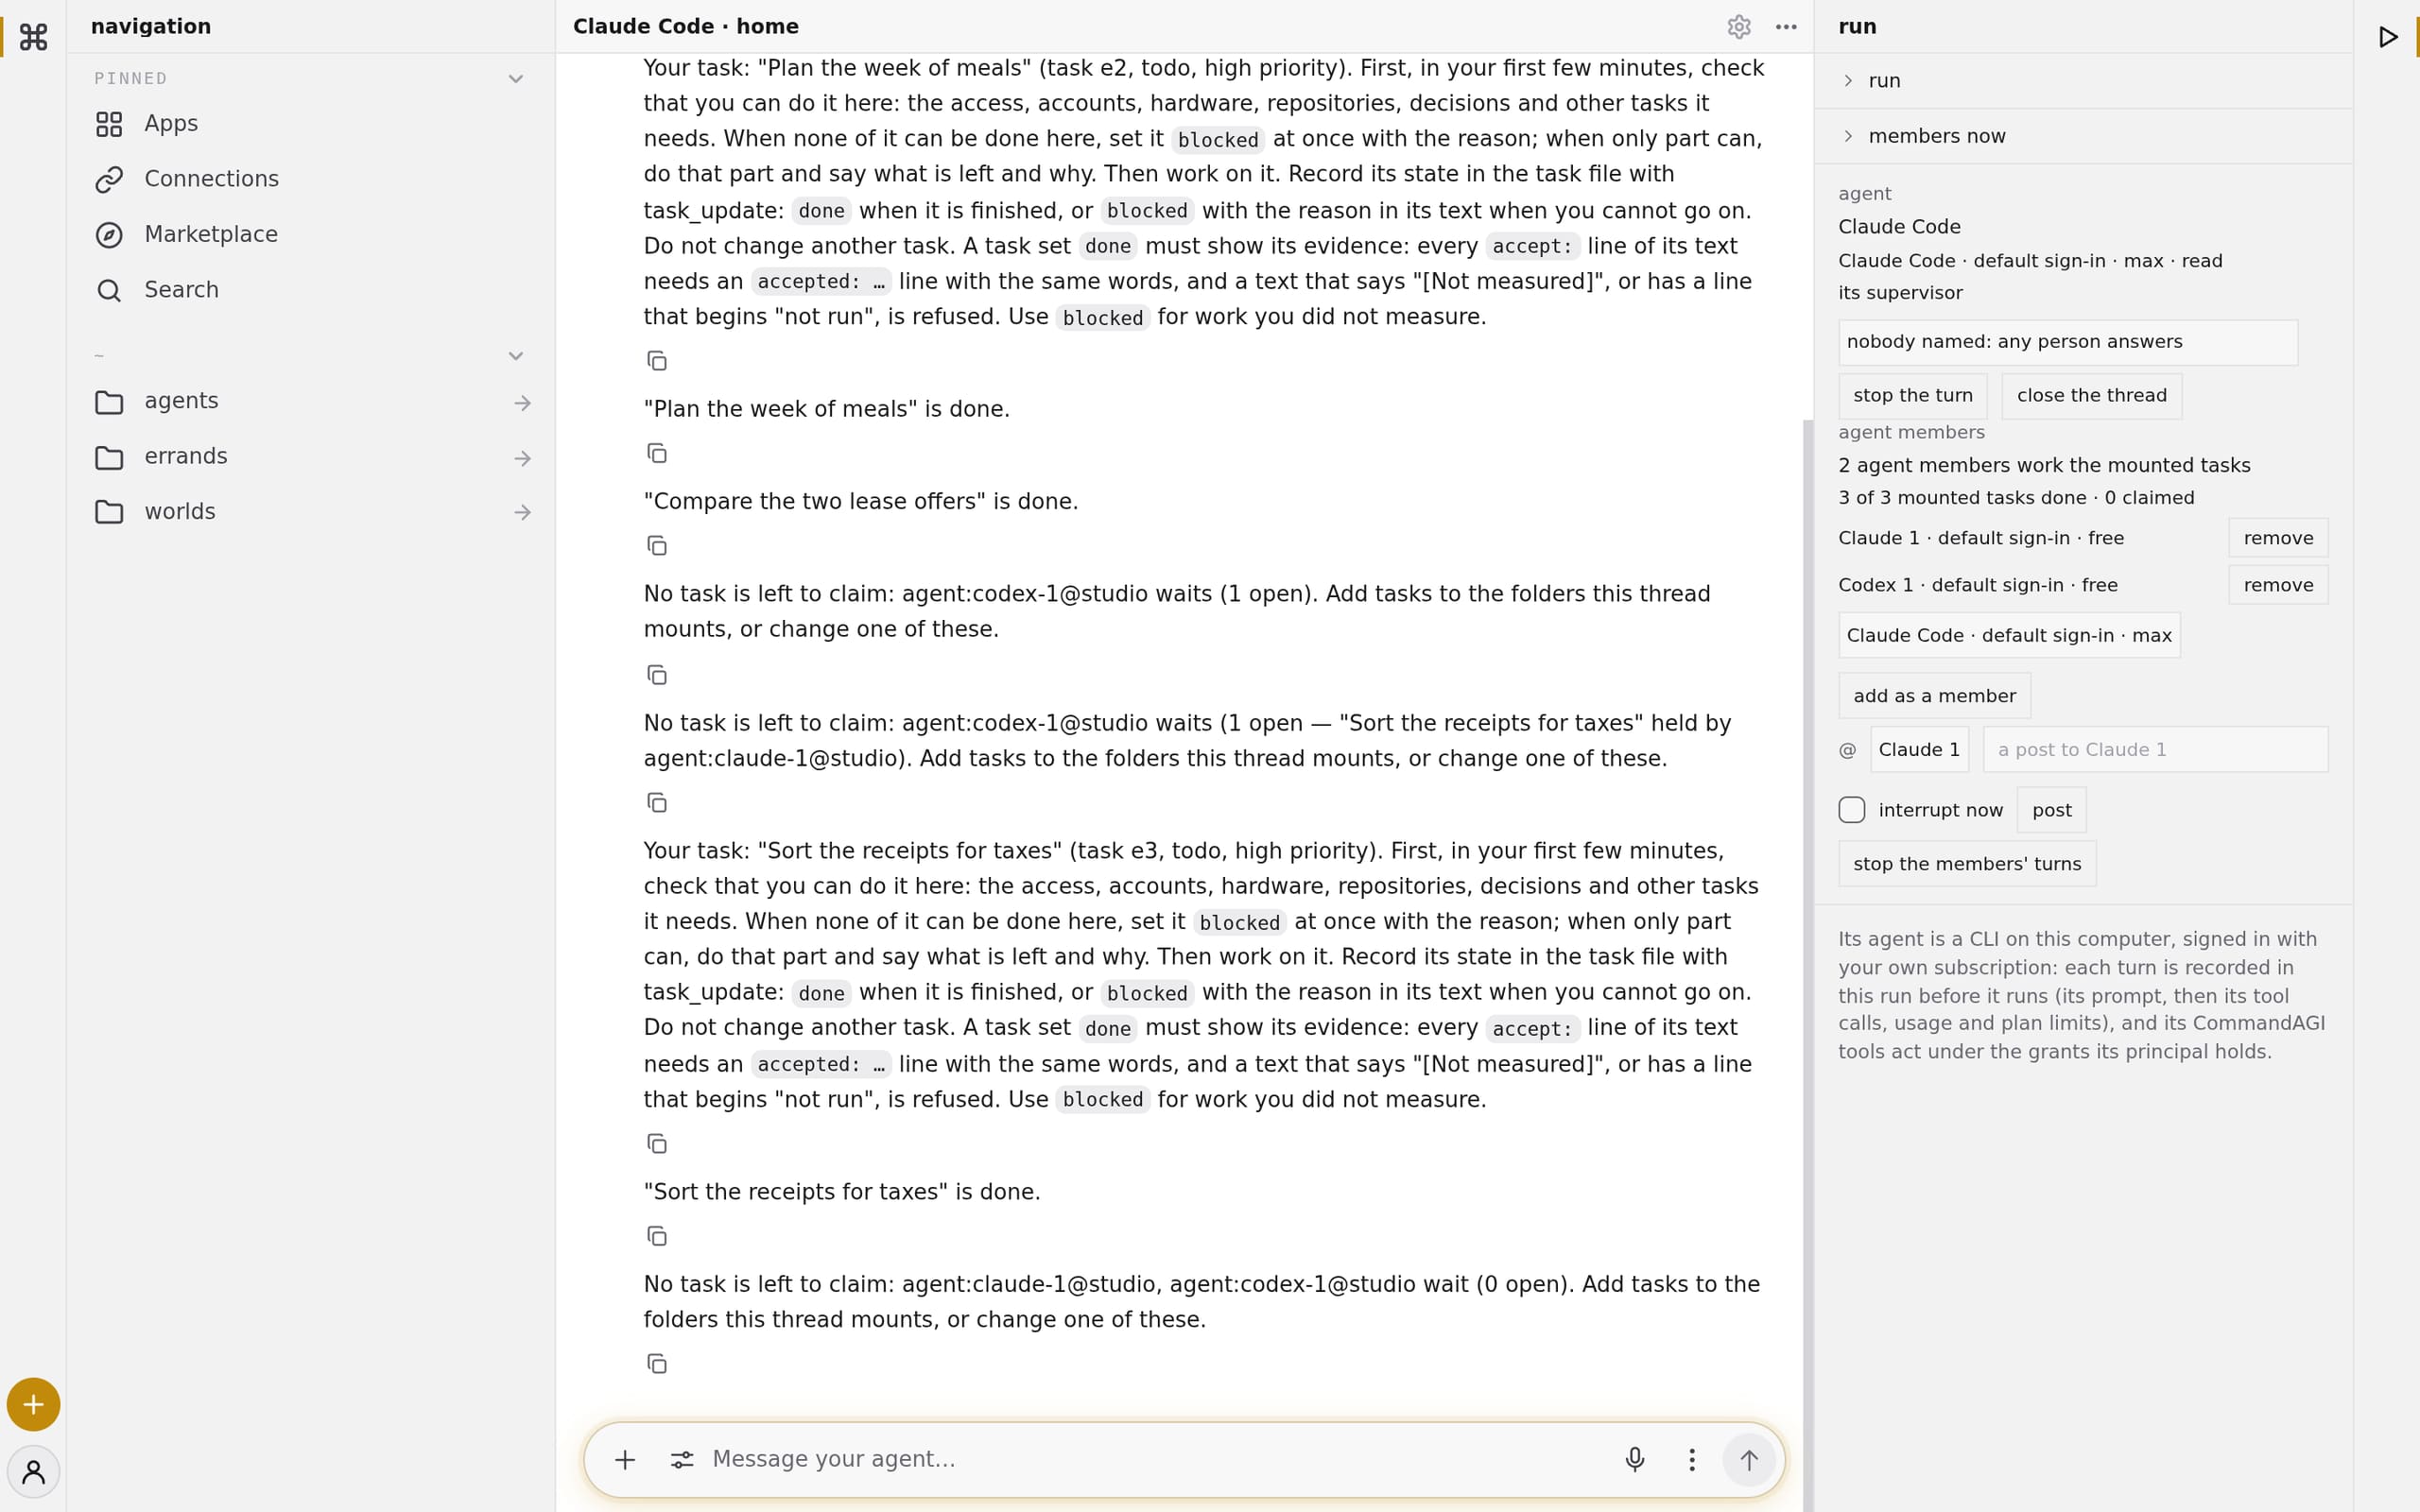
- Claude Code and Codex joined one thread, each on its own sign-in, and took the tasks one by one.
- The result
- 3,818 tasks claimed and 2,718 finished, with every step written down.
CommandAGI's own backlog, since 2026-10-23. The recording shows two agents in a thread.
Read the whole caseStart a thread
A physical part
- Wanted
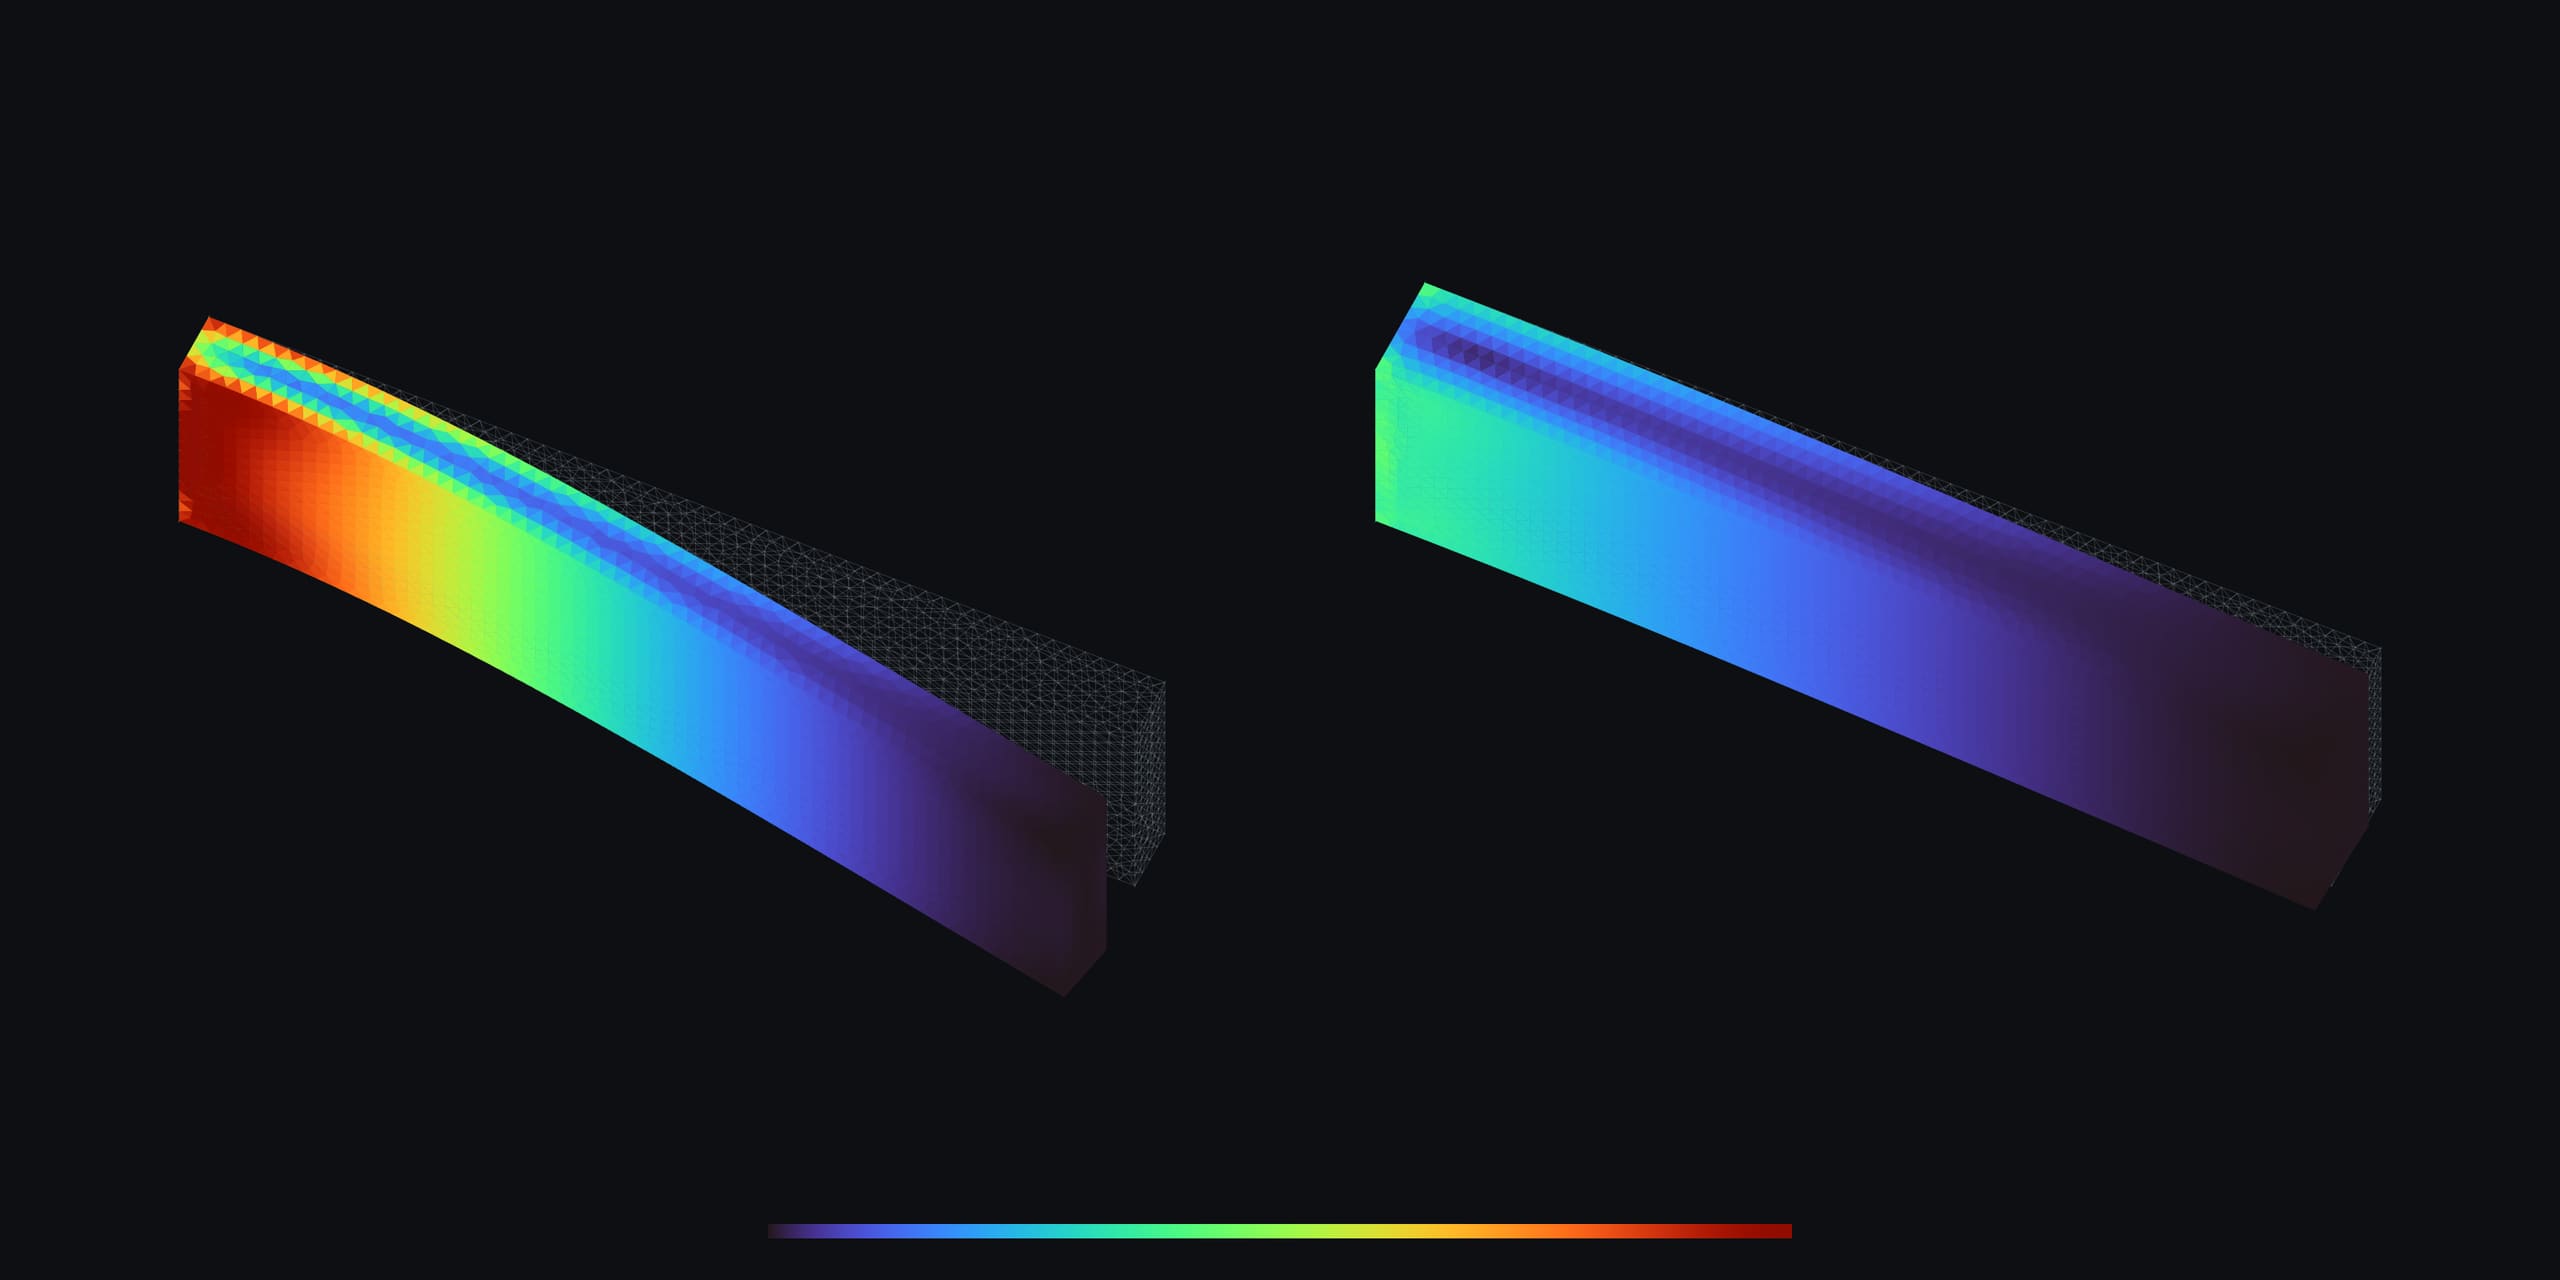
- A gripper jaw that holds its grip without bending more than 2 mm.
- What we did
- Tested the first design, found it bent 8.7 mm, and made it thicker until every check passed.
- The result
- A 6.625 mm jaw that bends 1.95 mm. Twenty-four solves in 84 seconds.
A simulation. The study and its run are in the example files.
Read the whole caseOpen the study
A business
- Wanted
- Nine companies, run from one place.
- What we did
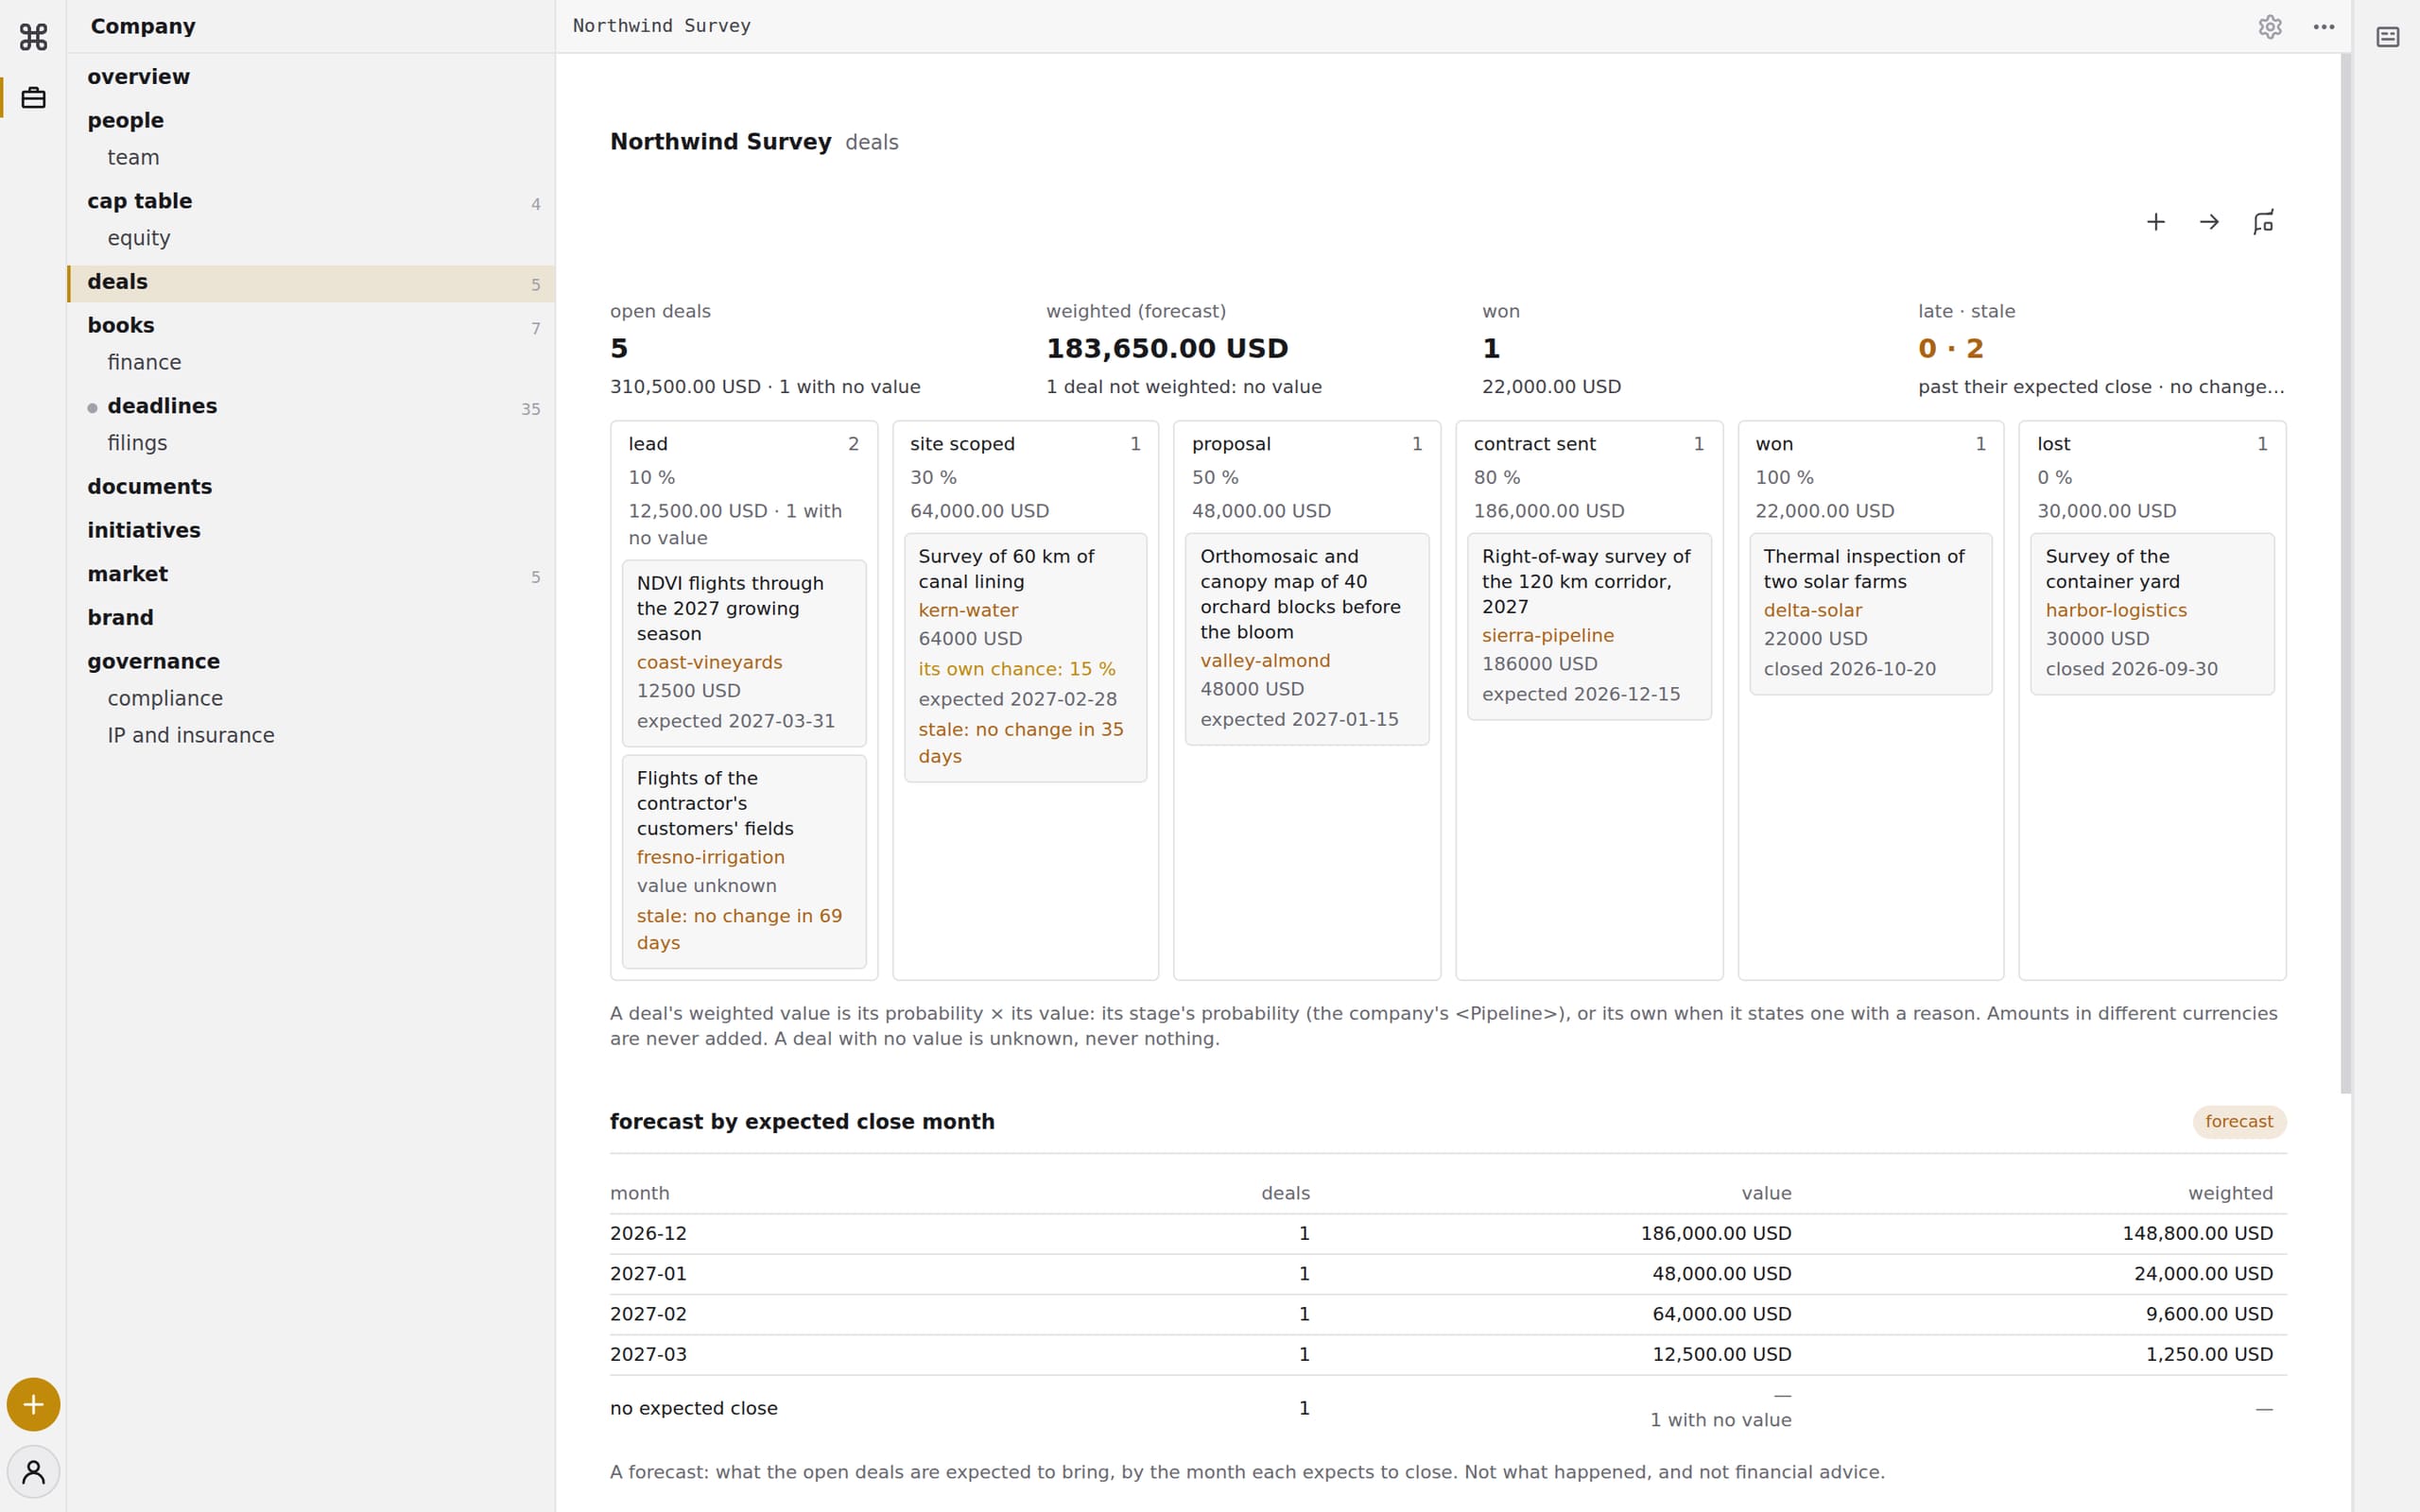
- Gave each company a folder: its plan, its people, its agents and a budget for each piece of work.
- The result
- Forty budgets, $290 a month in all, and every task a file anyone on the team can read.
CommandAGI's own companies. The recording shows an example company.
Read the whole caseStart with a website
A simulated world
- Wanted
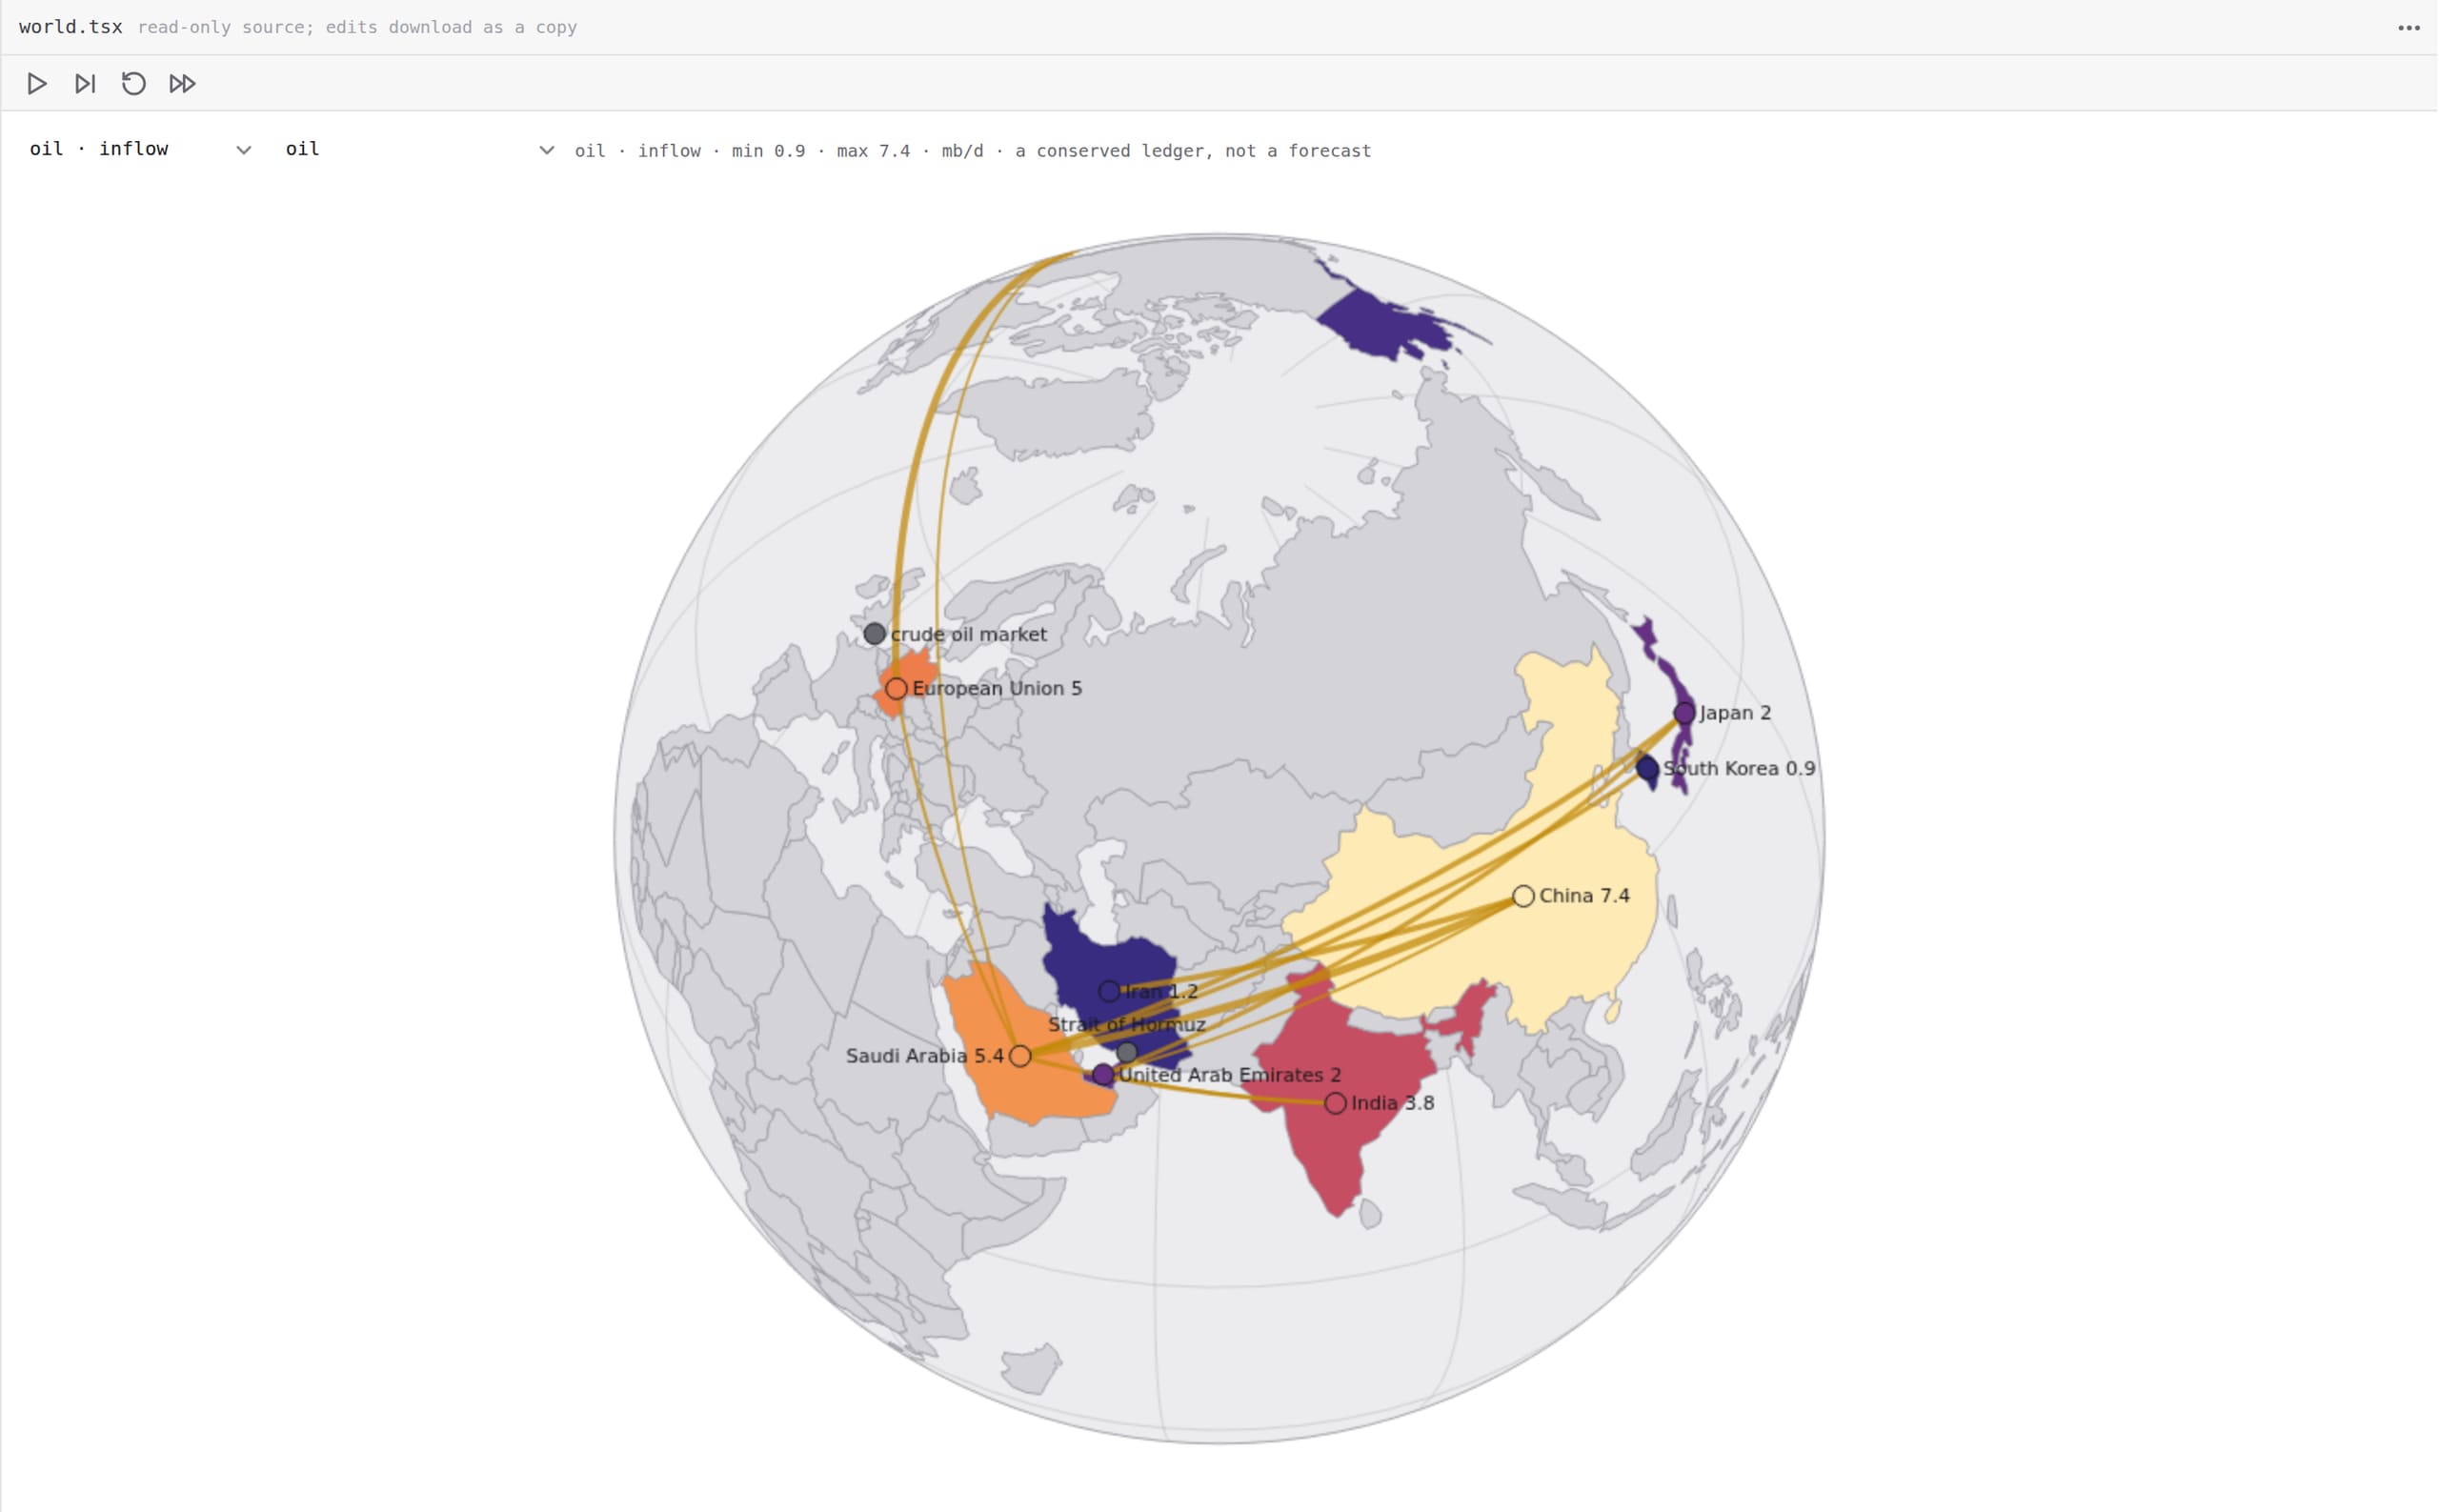
- To know what happens to the price of oil if the Strait of Hormuz closes.
- What we did
- Built the strait as a world and ran it at three levels of escalation.
- The result
- The price peaked at $90.5, $117.3 and $144.1. Each run names the lever that was pulled.
A simulation.
Read the whole caseTurn the globe
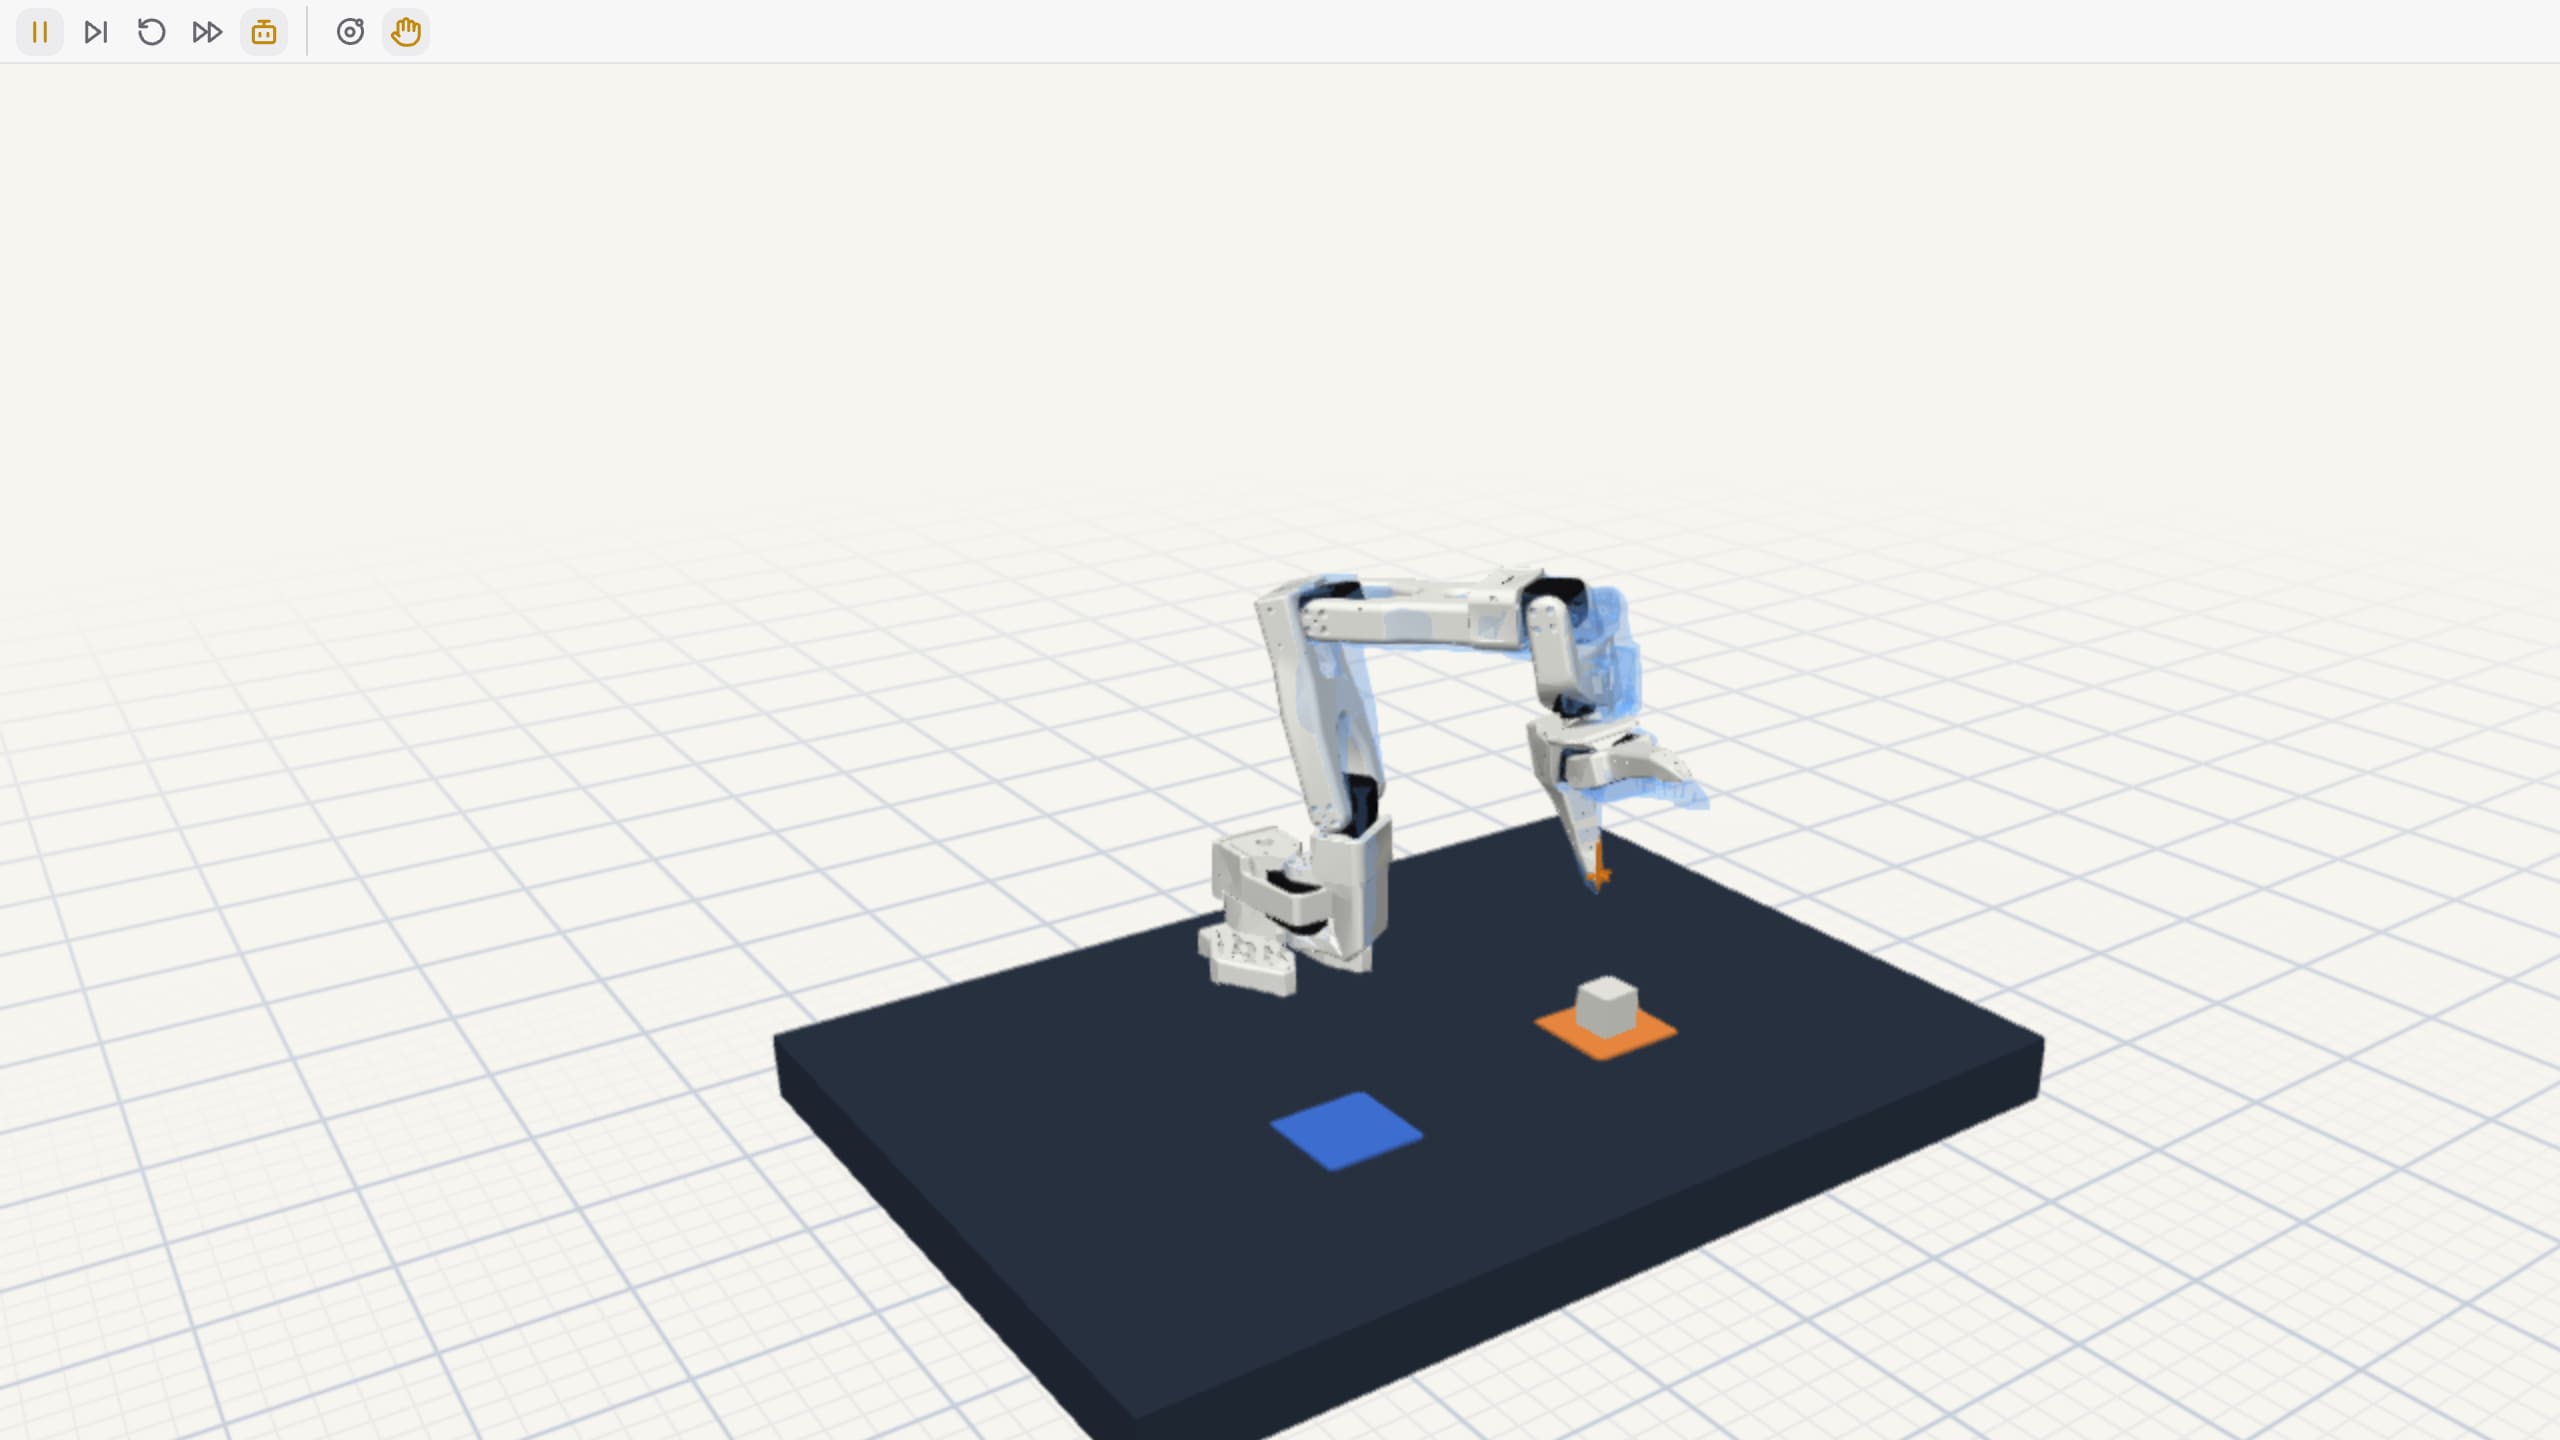
A robot
- Wanted
- A robot arm that picks up cubes it has never seen.
- What we did
- Let the arm practise in simulation, scored every try, and trained it on its own best runs.
- The result
- From 0 to 40 of 50 new cubes in six rounds.
A simulation: 742 recorded runs.
Read the whole casePull the cube
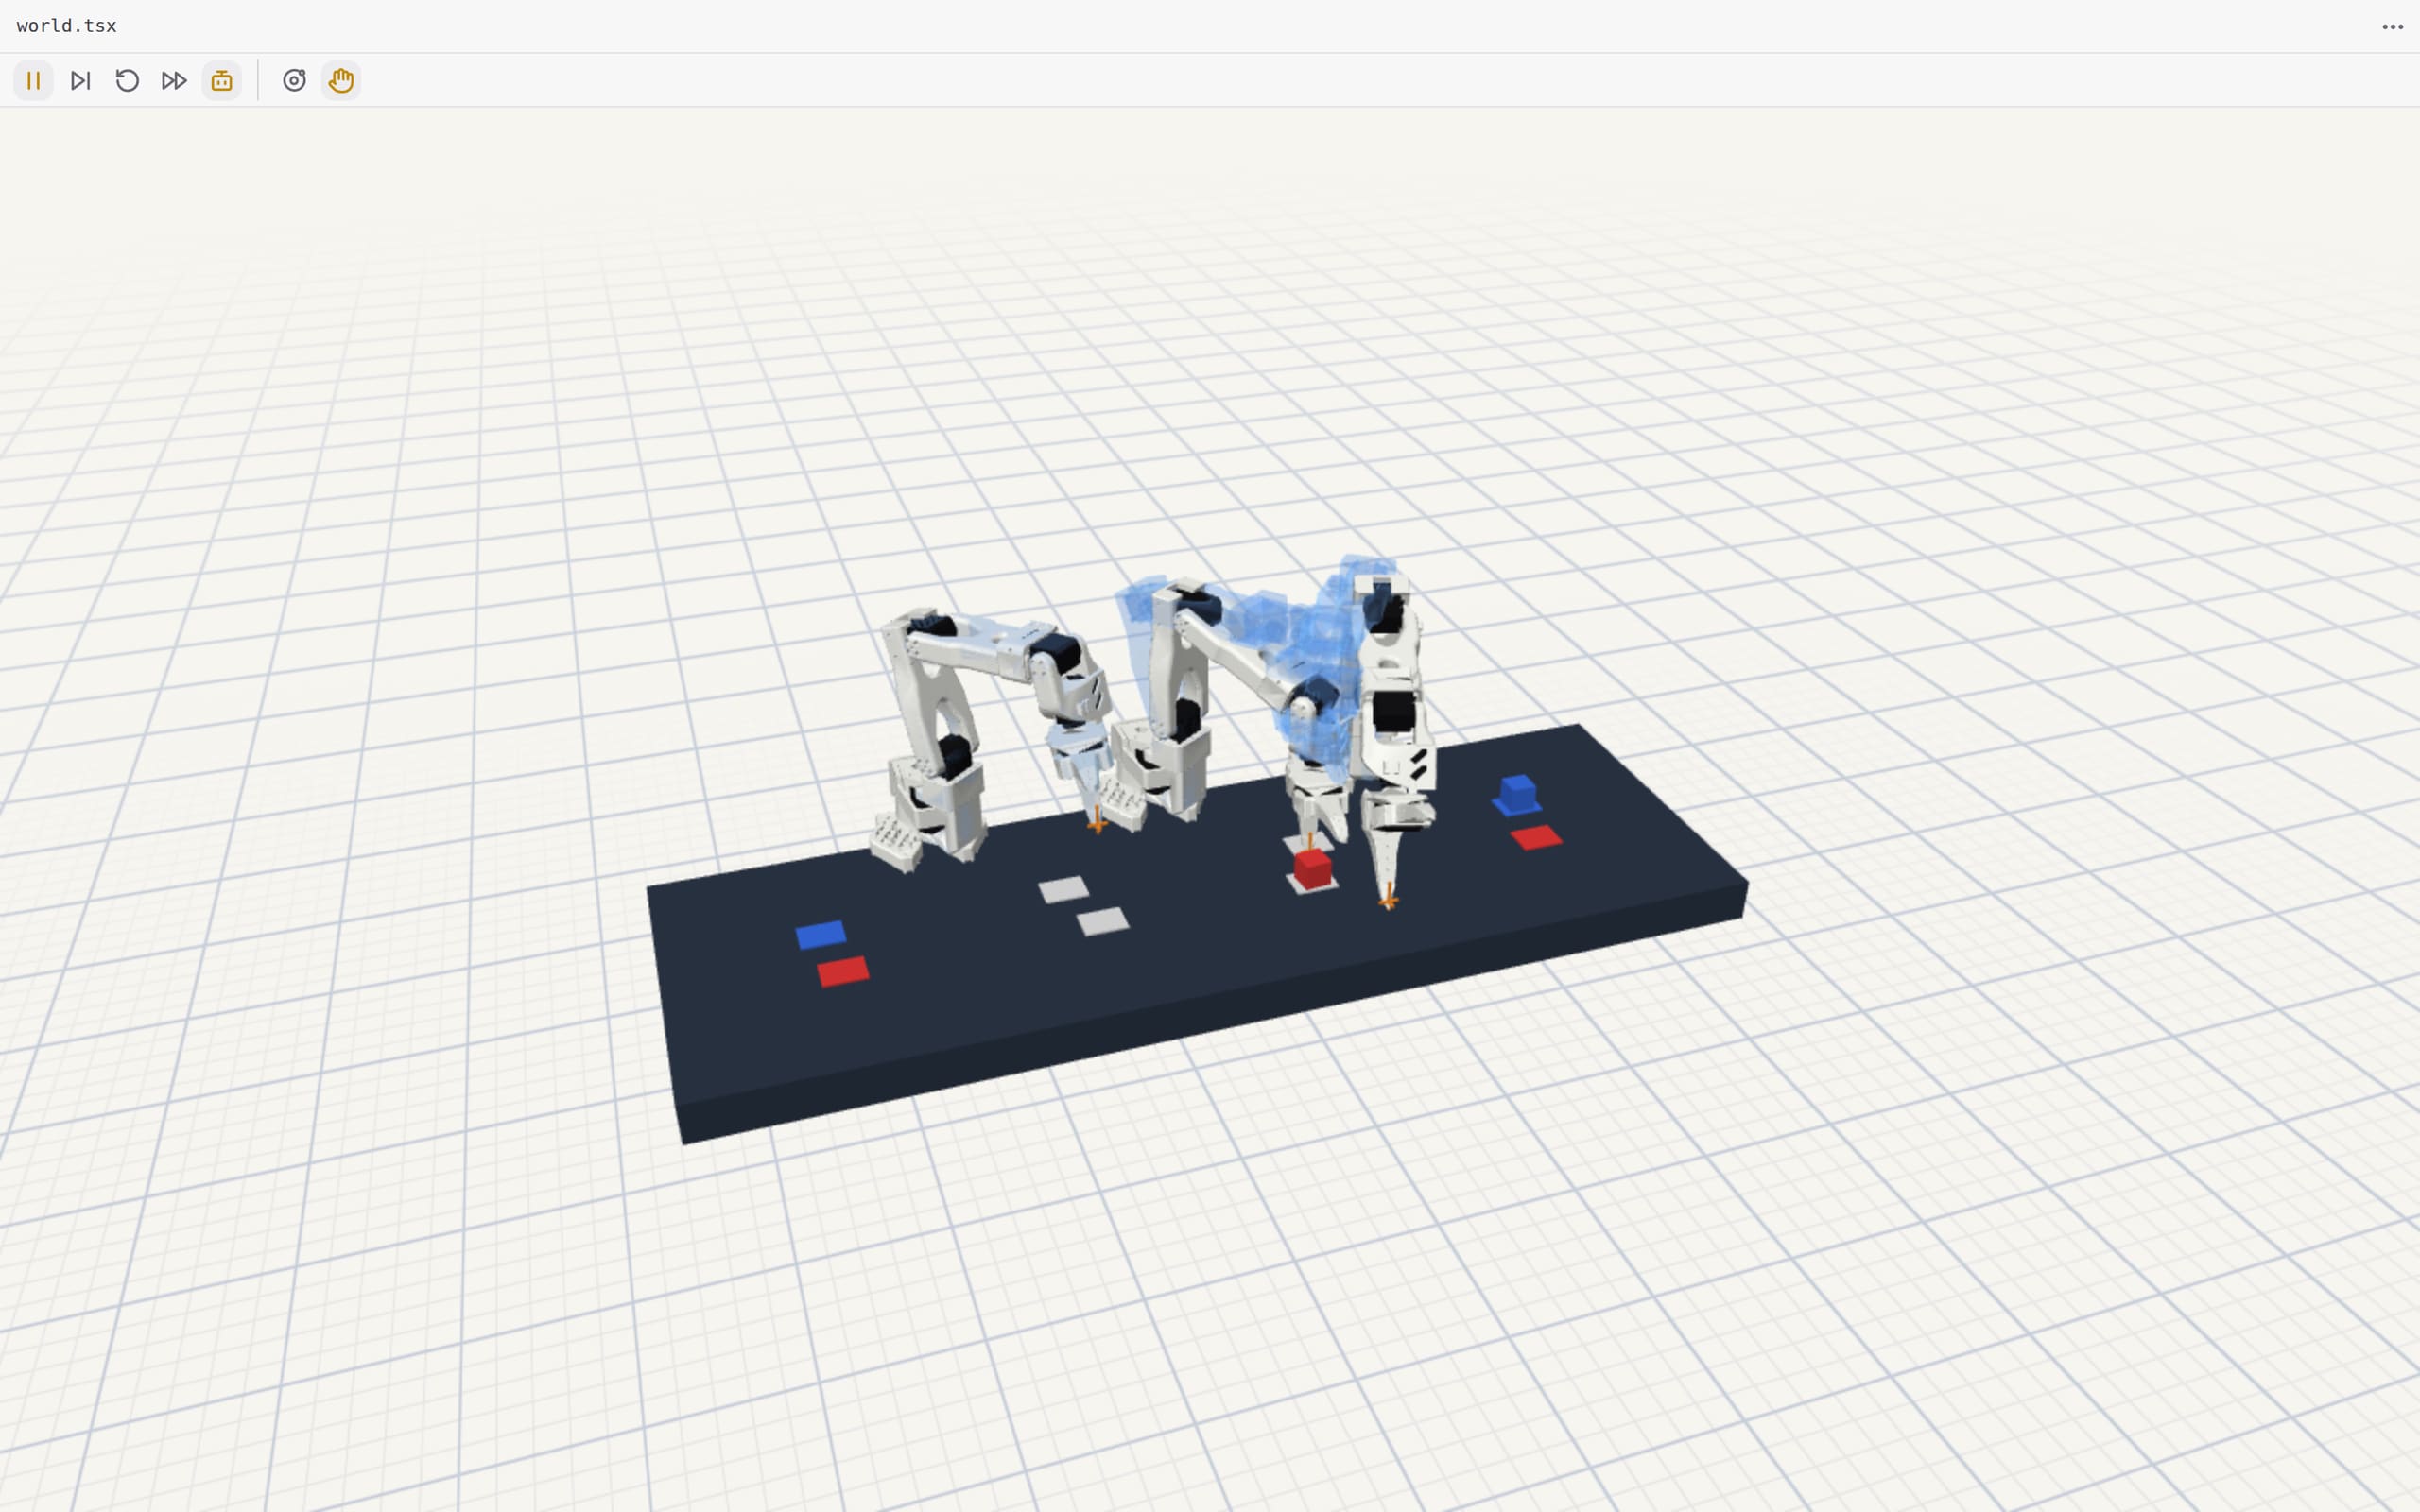
A robot cell
- Wanted
- Three arms that pass a cube down the line.
- What we did
- Placed three real arm models in one world and let them run with real physics.
- The result
- A working cell you can pull on, in your browser, before any machine moves.
A simulation.
Read the whole caseOpen the cell
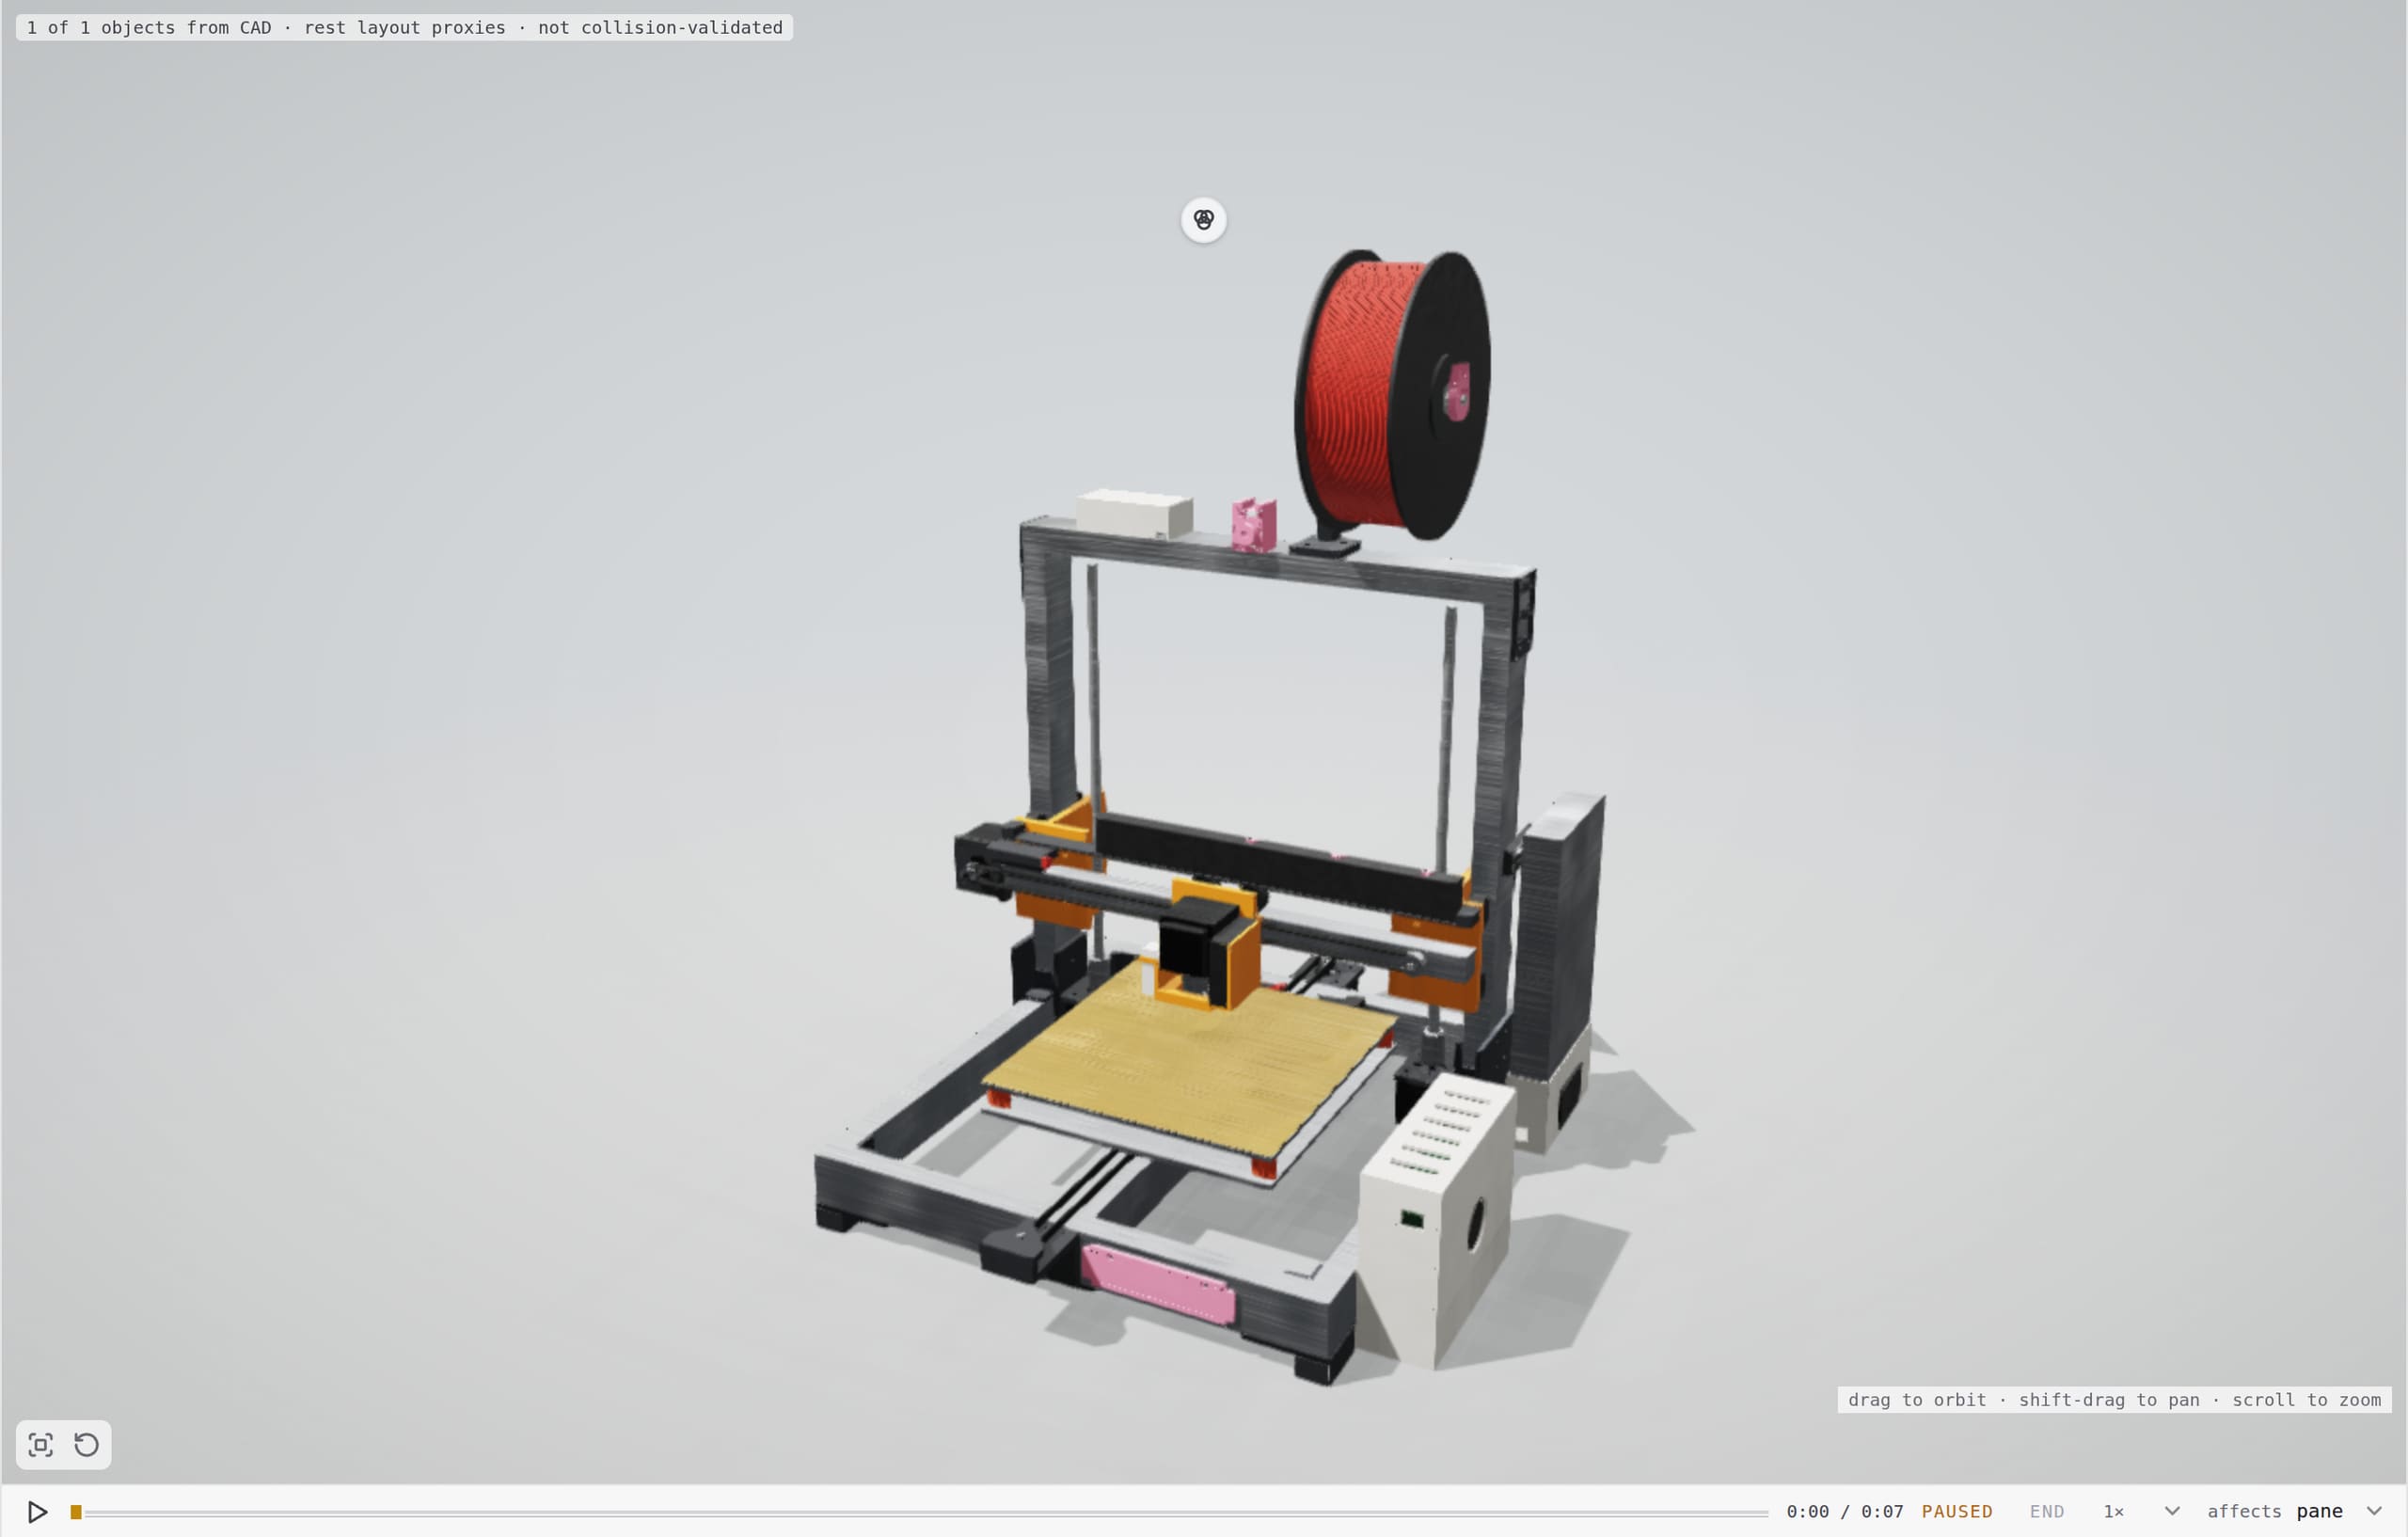
A print shop
- Wanted
- To know a print job will fit before it reaches a printer.
- What we did
- Checked the sliced part against each of the shop's twelve printers and played it through on the twin.
- The result
- Admitted on 12 of 12 printers: 154 layers, 3 hours 50 minutes.
A simulation. No printer was reached.
Read the whole caseOpen the printer
A design search
- Wanted
- The best version of a robot arm for one job.
- What we did
- Tried eighteen versions of the arm in simulation and kept the one that did best.
- The result
- One winning design, with the run that chose it on the record.
A simulation.
Read the whole caseOpen the run
Now make yours happen.
Start with a sentence. Watch the work. Step in whenever you like.